Not for saleUniversity research prototype, first described in a 2024 Nature paper.
Not for sale (research)Not programmableBird-like legsJump take-offFixed wing
Not for saleShipping: Not for sale. A research prototype that was never sold.
Remote control: Not possible. Research prototype.
Overview
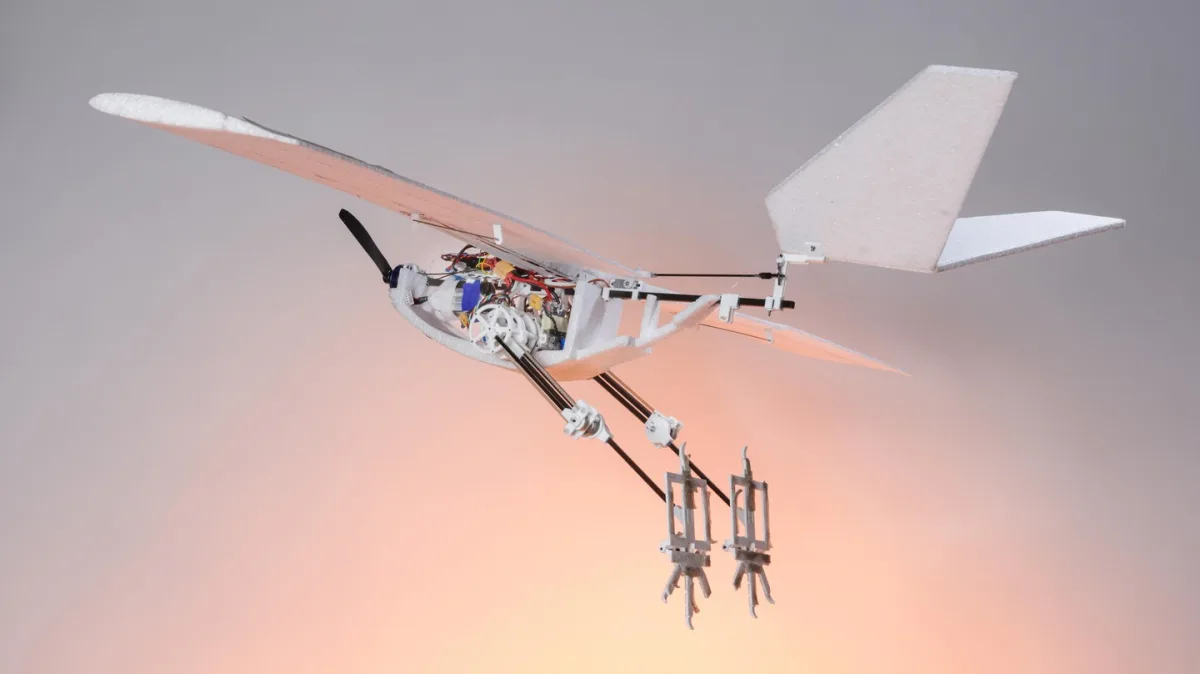
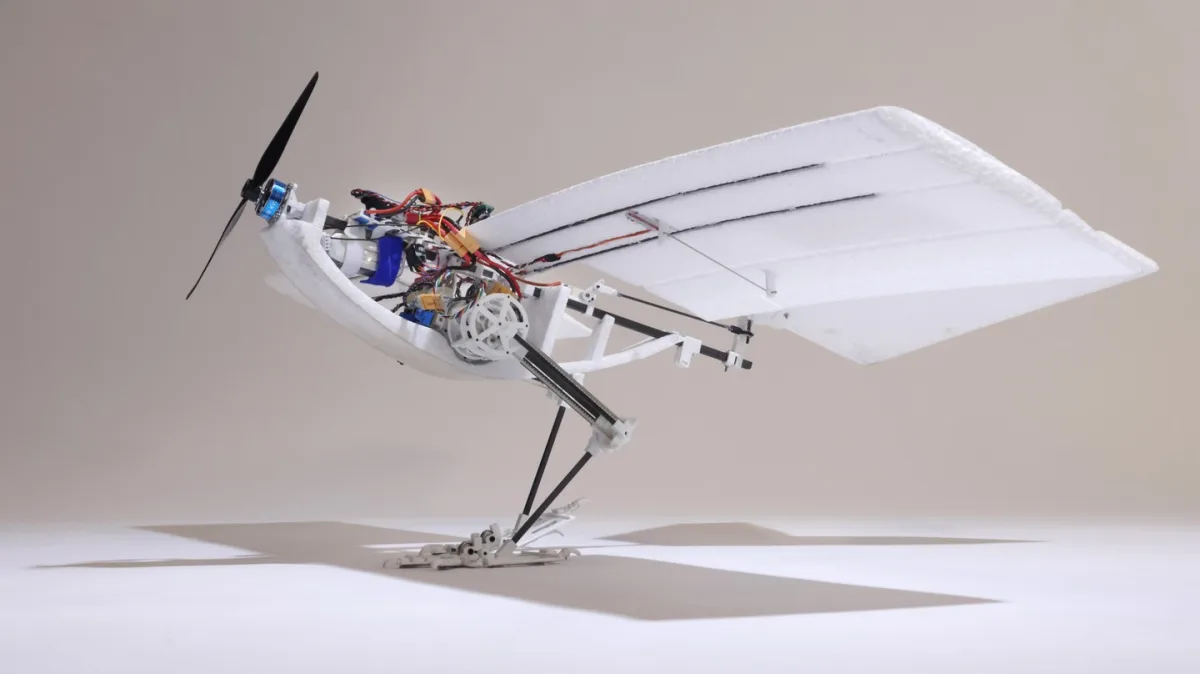
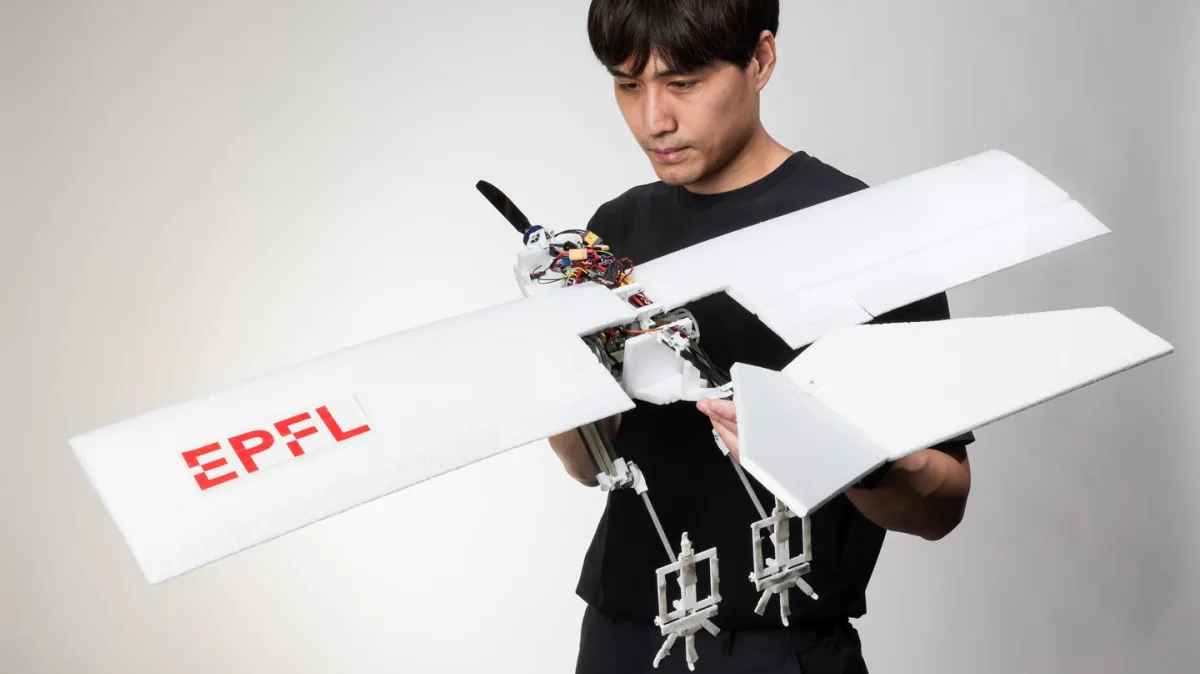
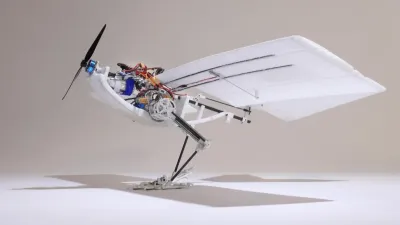
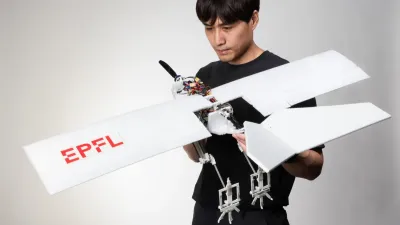
RAVEN is a 620 g fixed-wing drone from EPFL with two bird-like legs, built to the size of a carrion crow. Spring-loaded ankles and passive toes let the same legs walk at 0.23 m/s, hop across an 11.5 cm gap and jump onto a 26 cm ledge. To take off it jumps while the propeller spins up, reaching about 2.4 m/s in 0.17 s, so it needs no runway or launcher. The paper found jumping take-off used less energy than a propeller-only start. In the published tests it was flown by radio control.
Specifications
| Category | Drones · Fly + drive or walk |
|---|---|
| Released | 2024 |
| Country | Switzerland |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no SDK to connect one. |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Mixed |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Remote control | Not programmable |
| Size | 620 g with legs. 100 cm wingspan, 50 cm long, about the size of a carrion crow. |
| Drive | One front 8-inch propeller on a T-Motor AT2306 brushless motor, with ailerons and a tail elevator moved by three KST X08H servos. Two bird-like legs, each with hip and ankle joints driven by T-Motor AT2303 brushless motors through planetary gearboxes and belts, plus a spring-loaded ankle and a passive compliant toe. |
| Compute | Five STM32 B-G431B-ESC1 boards (one main controller, four leg motor controllers on a CAN bus), plus a Seeed XIAO nRF52840 that logs power use. |
| Vision | None |
| Lidar | None |
| Sensors | Current sensor for power logging. No onboard IMU is listed in the paper. Flight tests were tracked with an external motion-capture system. |
| Runtime | Not published |
| Speed | Walks at 0.23 m/s. Leaves the ground at about 2.4 m/s in a jumping take-off. |
| SDK | None public |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 LEONARDO (LEO)Autonomous Robotics and Control Lab (Soon-Jo Chung), Caltech (USA)Not for sale
 SPIDARJSK Lab (now DRAGON Lab), University of Tokyo (Japan)Not for sale
 Husky CarbonSiliconSynapse Lab (Alireza Ramezani), Northeastern University (USA)Not for sale
 M4 (Multi-Modal Mobility Morphobot)Caltech CAST and Northeastern University (USA)Not for sale
 RollocopterTeam CoSTAR, NASA Jet Propulsion Laboratory (USA)Not for sale
 HyTAQRobotics Lab, Illinois Institute of Technology (USA)Not for sale