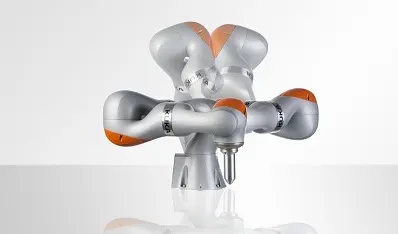
Quote onlySold through KUKA and integrators; no public list price.
AvailableVia SSH / web / bridge7-axisTorque sensorsSunrise JavaDLR heritage
Weeks+Shipping: Integrator lead time. Sold through KUKA and its integrators on quotation.
Remote control: Applications are written in Java and deployed from Sunrise Workbench; external laptop control runs through FRI, for example with the community LBR-Stack for ROS 2.
Overview
The industrial descendant of the DLR lightweight robot (KUKA LBR 3 in 2004, LBR 4 in 2008), a 7-axis arm with torque sensing in every joint, launched in 2013. Before the Franka Panda it was the default torque-controlled research arm, and a medical variant (LBR Med) is used in surgical robotics.
Specifications
| Category | Robot arms · Industrial & legacy |
|---|---|
| Released | 2013 |
| Availability | Available |
| Programmability | Full SDK |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Proprietary / undisclosed |
| Remote control | Via SSH / web / bridge |
| DOF | 7 |
| Reach | 800 mm (7 R800), 820 mm (14 R820) |
| Payload | 7 kg or 14 kg |
| Repeatability | ±0.1 mm (7 R800) / ±0.15 mm (14 R820), ISO 9283 |
| Weight | 23.9 kg (7 R800) / 29.9 kg (14 R820) |
| Controller | KUKA Sunrise Cabinet controller (Sunrise.OS) |
| Sensors | Joint torque sensors in all seven axes |
| SDK | Sunrise.OS Java API in Sunrise Workbench; Fast Robot Interface (FRI) for external real-time control; community ROS/ROS 2 stacks |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 Dobot CR / CRA seriesDobot (China)Quote only
 Kinova JACOKinova (Canada)Quote only
 Franka Emika PandaFranka Emika (Germany)Was €9,900 (2016 pre-order)
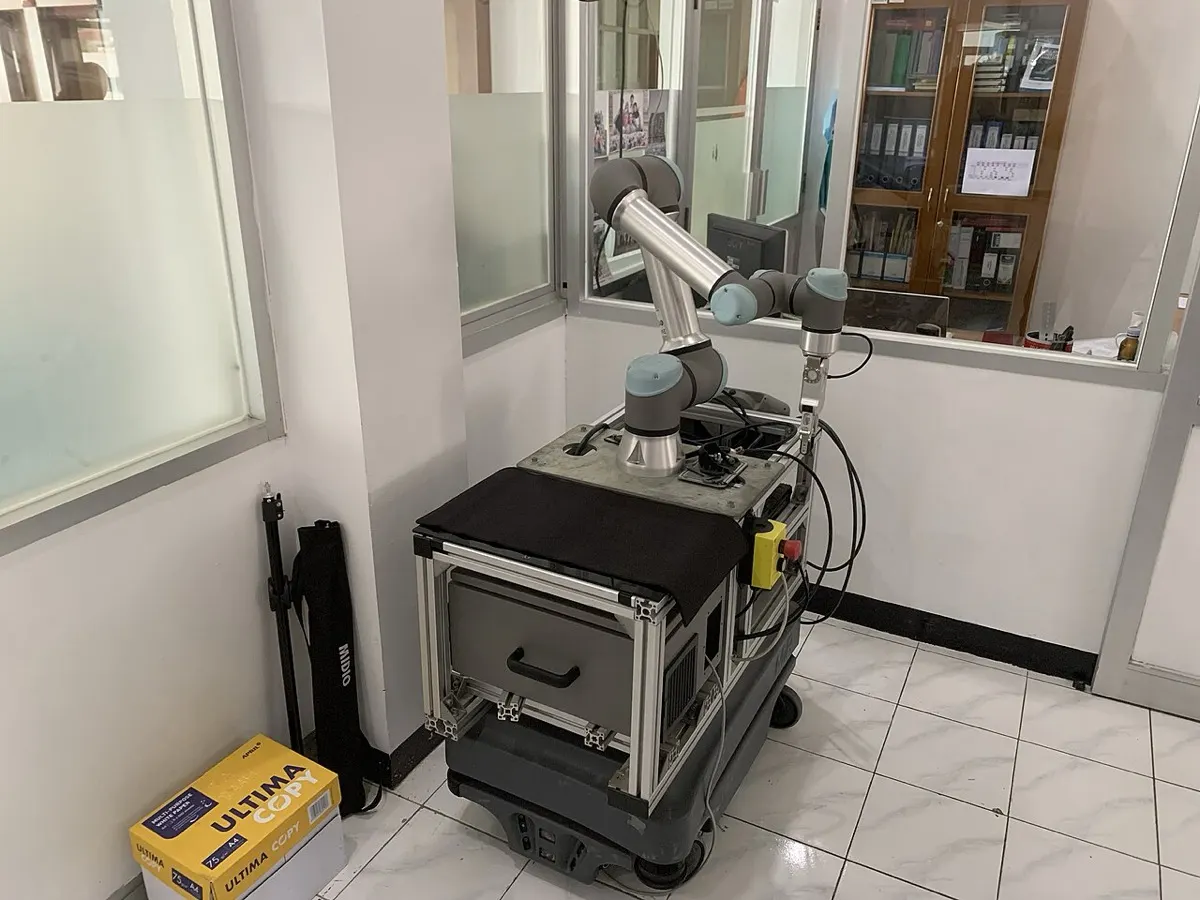 Universal Robots UR5e (UR7e)Universal Robots (Denmark; Teradyne)Quote only
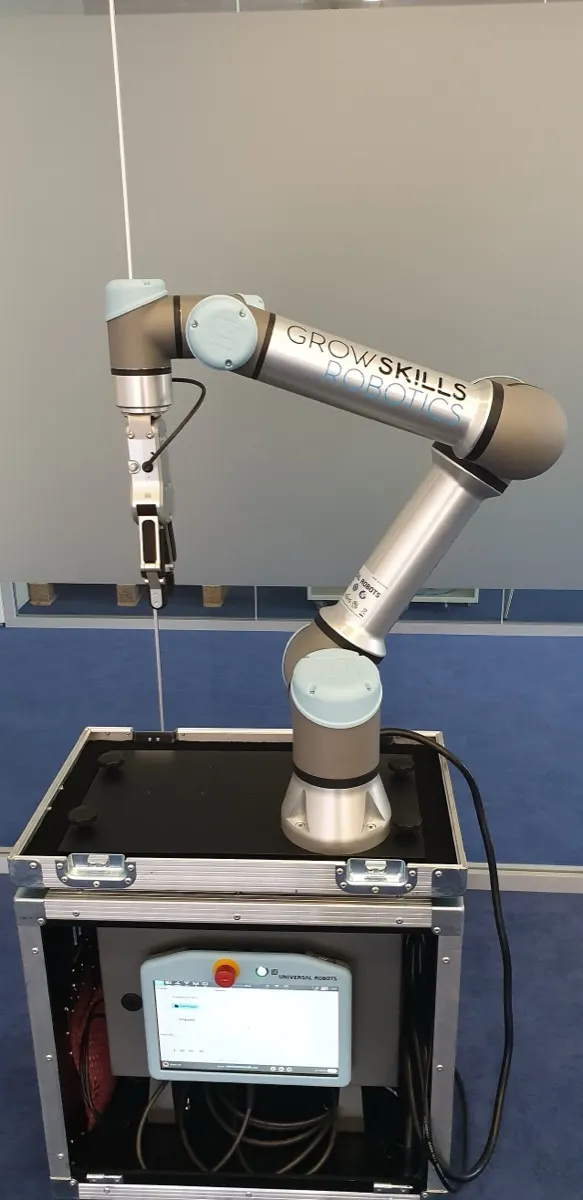 Universal Robots UR5 (original)Universal Robots (Denmark)Was about €20,000 (2012)
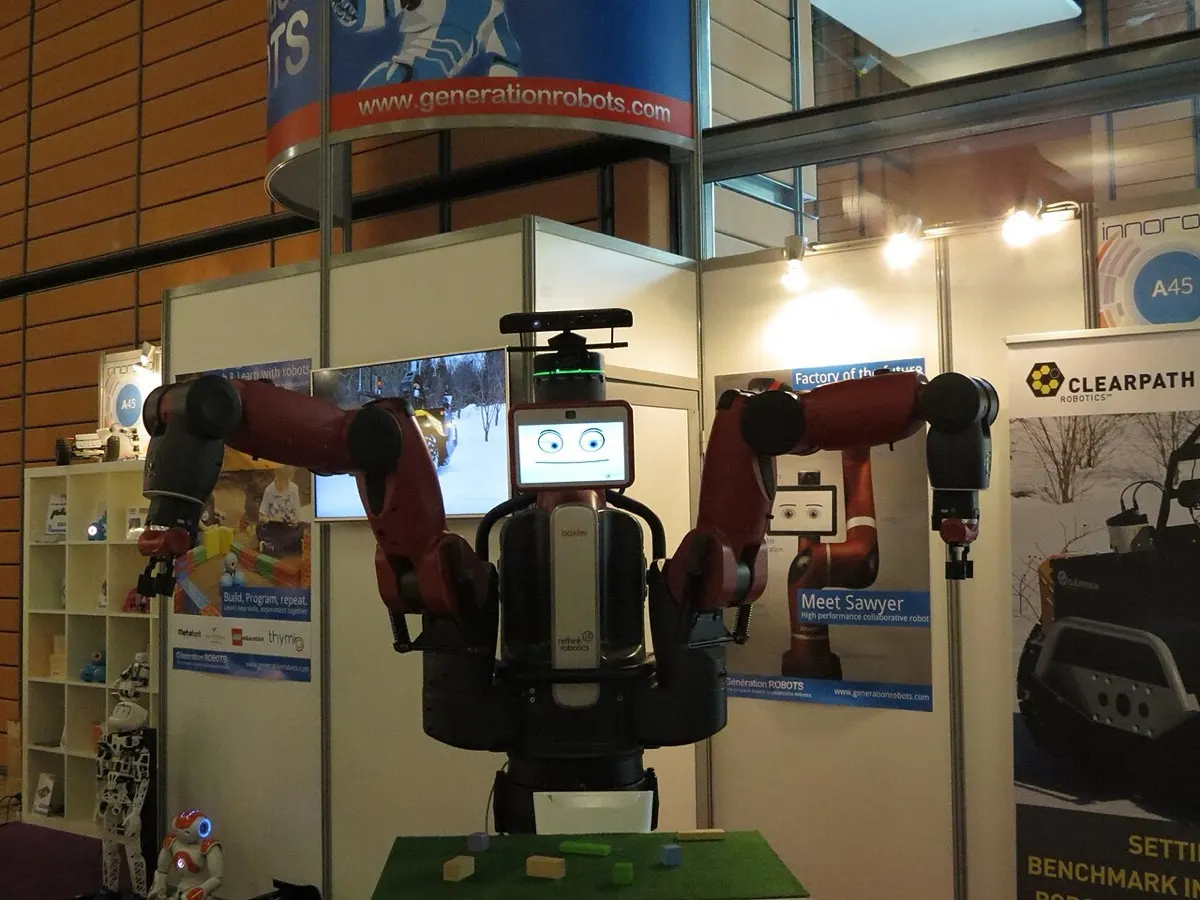 Rethink Robotics BaxterRethink Robotics (USA)Was $22,000 (2012)
Image credits
- Image 1: source (CC BY-SA 3.0, KUKA Laboratories GmbH)