Overview
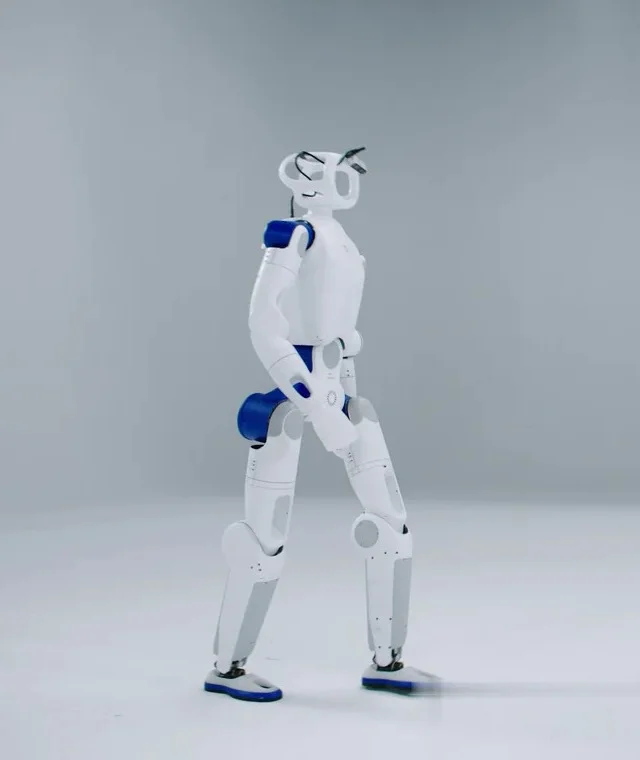
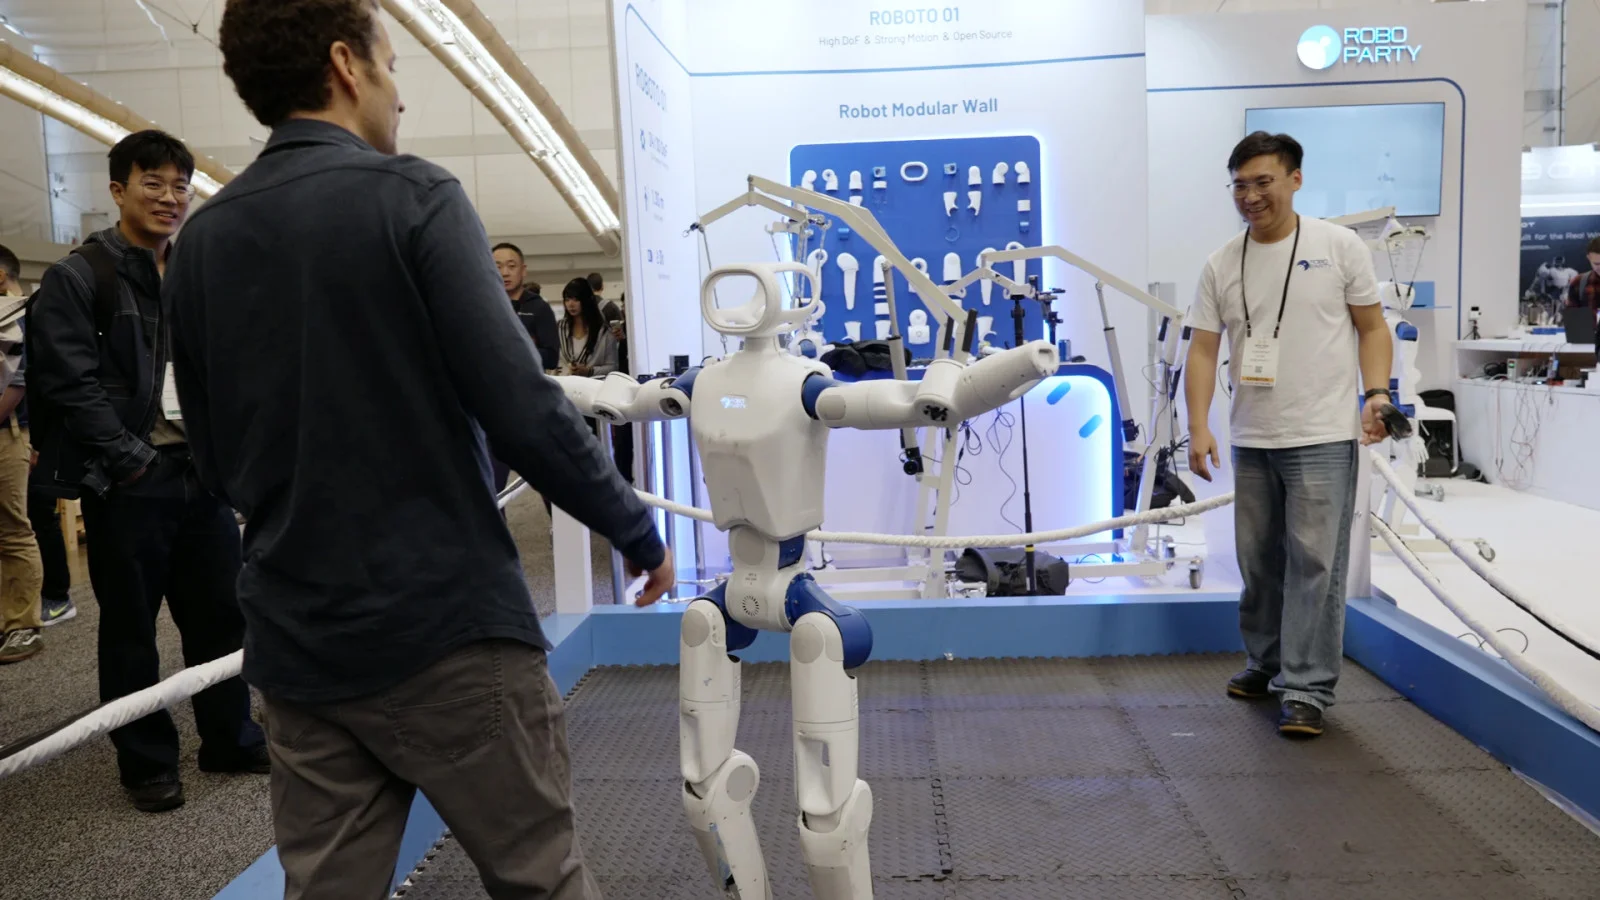
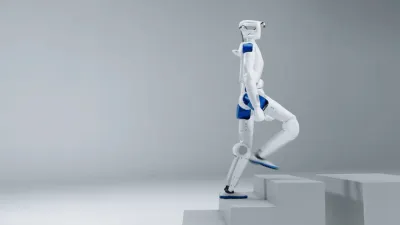
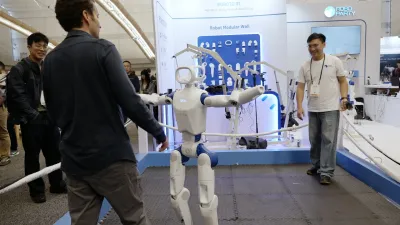
ROBOTO 01, sold as RP1 and RP1 Pro, is a 1.35 m open-source humanoid from RoboParty, a Shanghai startup founded in February 2025. It is aimed at researchers and independent developers who want a full-size robot with nothing hidden. RoboParty publishes the mechanical CAD, PCBs, bill of materials, firmware, robot models, deployment code and training code. It follows the company's DIY ROBOTO Origin, a 1.25 m, 23-DoF prototype whose parts can be bought on Taobao. RP1 was shown walking and getting up after falls at IROS 2026.
The joints are RoboParty's own ROMOMO modules, four sizes of two-stage planetary actuators with inner-rotor motors. The largest, 100 mm across, peaks at 160 N·m. A 10 Ah hot-swappable battery gives about 3 hours, and it charges in 1.5 hours over 140 W USB-C or a magnetic plug. The base RP1 has 24 DoF, an RK3588 and dummy hands, while the 30-DoF Pro adds 7-DoF arms, a 2-DoF neck, a camera, voice control and 6-DoF dexterous hands. Locomotion policies train in Isaac Lab and are checked in MuJoCo before running on the robot through a ROS 2 stack. No price, order page or ship date has been published, so it is announced only.
- Type
- Biped robot · Bigger reference platforms
- Maker
- RoboParty (Shanghai, China)
- Released
- 2026
- Price
- No price yet
- Status
- Announced only
- Best for
- Professionals & labs
- Programming
- Open source (hardware + software)
Price and shipping
RoboParty's site lists no price, order button or pre-order for RP1 (checked October 2026). A funding report says RoboParty plans to launch RP1 officially in Q4 2026 and spend new money on mass production (unconfirmed by RoboParty). The earlier DIY ROBOTO Origin's GitHub bill of materials totals ~$6,980 (¥49,713) in parts (estimate), which hints at the cost of the open design.
Shipping: Not announced. No order page or pre-order exists yet. RoboParty sells only its ROMOMO joint modules (pre-order) and RP Hand on its own store, and the DIY ROBOTO Origin through Taobao. RoboParty ↗
Specifications
| Category | Bipeds · Bigger reference platforms |
|---|---|
| Released | 2026 |
| Country | China |
| Availability | Announced only |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No LLM is named. RoboParty calls RP1 a platform for agentic humanoids, and the Pro adds a microphone, screen and voice control. The open ROS 2 deployment stack and C++/Python SDKs let an LLM on a computer send it commands. RoboParty RP1 page ↗ |
| MuJoCo simulation | Official model · RoboParty publishes official MJCF models (24-DoF, with hands, flat and rough terrain scenes) in RP1_description, used for Sim2Sim checks of trained policies. RP1_description ↗ |
| NVIDIA Isaac simulation | Sim-to-real kit · roboparty_train has RP1 locomotion tasks (RP1-Flat, AMP and BeyondMimic motion tracking) in Isaac Lab with RSL-RL, and roboparty_deploy runs the exported policies on the robot. roboparty_train ↗ |
| Gazebo simulation | Maker URDF only · The official URDF in RP1_description would need converting. No Gazebo package was found. RP1_description ↗ |
| Best for | Professionals & labs |
| Vision sensors | Camera, Depth camera, Lidar |
| Actuators | Brushless / direct-drive motors |
| Audio | Speaker, Microphone |
| Compute type | Rockchip, Other ARM chip, NVIDIA Jetson |
| Balance type | RL walking |
| Height | 1.35 m (1350 × 450 × 200 mm standing) |
| Weight | ≈39 kg (RP1) or ≈41 kg (RP1 Pro), with hands and battery |
| Compute | Rockchip RK3588 (RP1). The Pro adds an Allwinner A733 and an optional NVIDIA Jetson Orin NX 16 GB development module |
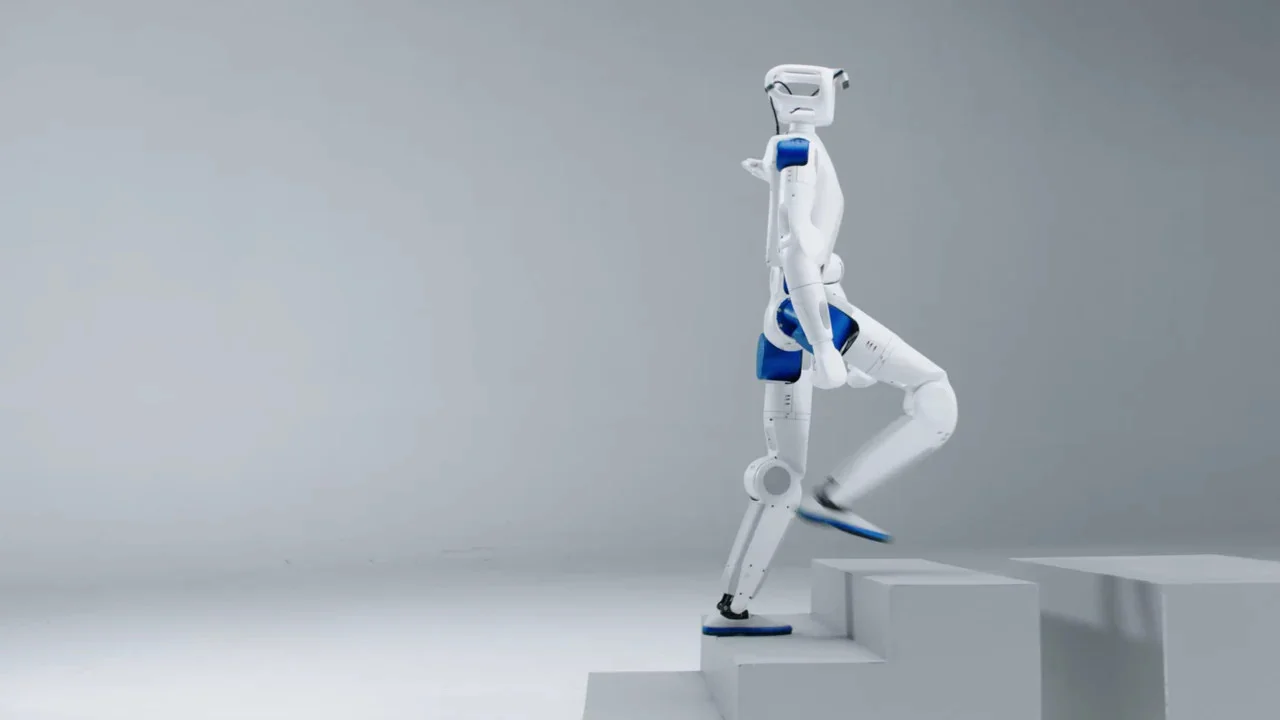
| Speed | Up to 4 m/s running (maker figure), climbs 30° slopes and 50 mm steps |
| DOF | 24 active (RP1: 6 per leg, 5 per arm, 2 waist) or 30 (Pro: 7 per arm, 2 in the neck). Description models also cover 28 and 42 DoF builds |
| Sensors | 6-axis IMU on both. The Pro adds a mono RGB camera, microphone and screen. Swappable heads add an Intel RealSense D435i depth camera plus 3D lidar (perception head) or a stereo RGB camera (data-collection head) |
| Balance | RL walking and running from policies trained in Isaac Lab, with fast get-up after falls. The real-time layer decodes actions and solves the leg linkages at 500 Hz. |
| SDK | Fully open source on GitHub: CAD, PCBs, BOM and assembly SOPs (CERN-OHL-W-2.0), Linux BSP and low-level SDK, ROS 2 deployment framework with C++/Python SDKs, Isaac Lab training code (GPL-3.0). Remote and app control, plus voice on the Pro |
Common questions
How much does ROBOTO 01 cost?
No price yet. RoboParty's site lists no price, order button or pre-order for RP1 (checked October 2026). A funding report says RoboParty plans to launch RP1 officially in Q4 2026 and spend new money on mass production (unconfirmed by RoboParty). The earlier DIY ROBOTO Origin's GitHub bill of materials totals ~$6,980 (¥49,713) in parts (estimate), which hints at the cost of the open design.
Can ROBOTO 01 be bought today?
Not yet. It has been announced but is not on sale. No order page or pre-order exists yet. RoboParty sells only its ROMOMO joint modules (pre-order) and RP Hand on its own store, and the DIY ROBOTO Origin through Taobao.
Who makes ROBOTO 01?
ROBOTO 01 is made by RoboParty (Shanghai, China). It came out in 2026.
Can ROBOTO 01 be programmed?
Open source (hardware + software). Fully open source on GitHub: CAD, PCBs, BOM and assembly SOPs (CERN-OHL-W-2.0), Linux BSP and low-level SDK, ROS 2 deployment framework with C++/Python SDKs, Isaac Lab training code (GPL-3.0). Remote and app control, plus voice on the Pro.
Does ROBOTO 01 have AI chat or LLM support?
Possible via SDK. No LLM is named. RoboParty calls RP1 a platform for agentic humanoids, and the Pro adds a microphone, screen and voice control. The open ROS 2 deployment stack and C++/Python SDKs let an LLM on a computer send it commands.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
- MuJoCo Guide · the simulator used to train walking robots
- ROS 2 Guide · the software framework many robots use
- Robot Vision and Depth Sensors · cameras, lidar and other distance sensors
Similar robots
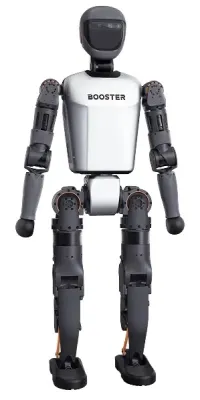 Booster T1
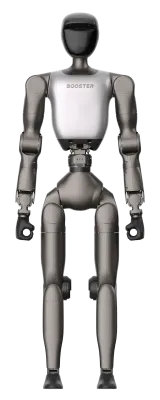 Booster T2
 G1
 PM01
 Adam
 K-Bot
Sources
RP1 documentation (Chinese) ↗ · RP1 on GitHub ↗ · ROBOTO Origin (DIY prototype) on GitHub ↗ · gagadget article ↗