Overview
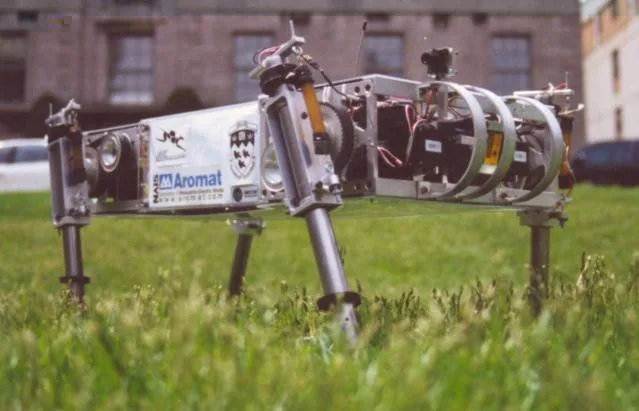
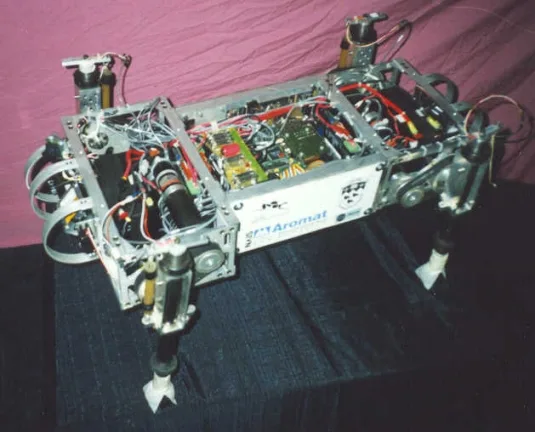
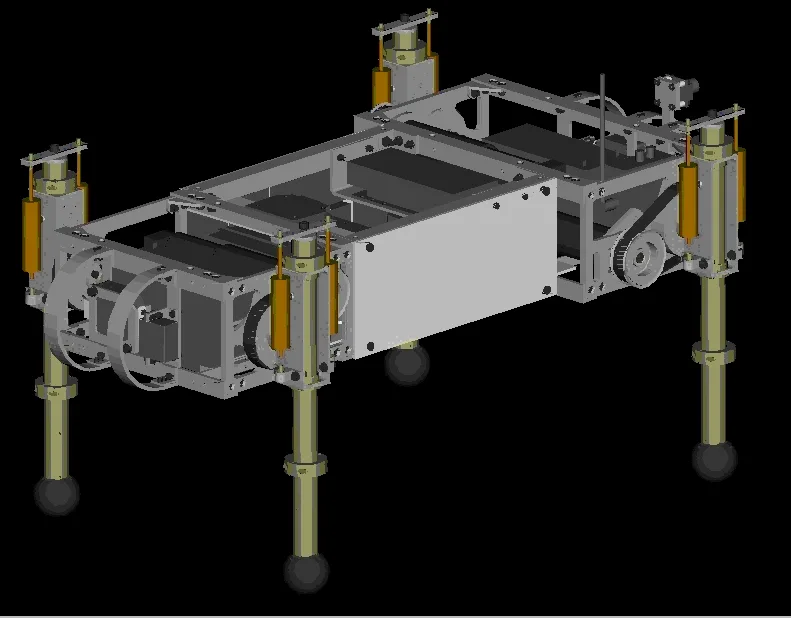
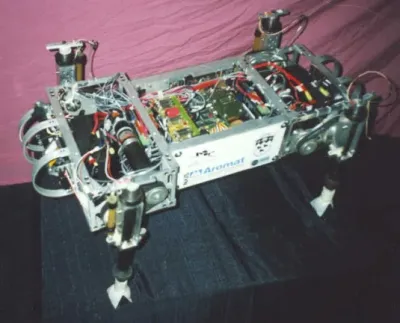
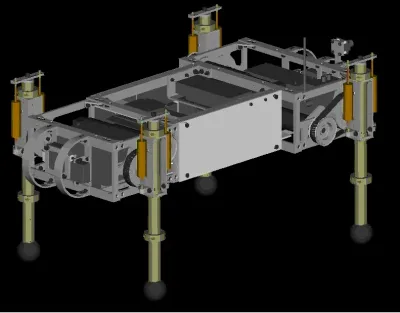
An early running quadruped from McGill University in Montreal, led by Martin Buehler. Each leg has a single motor at the hip and a springy leg below it, which kept the design unusually simple. It carried its own computer and batteries, so it ran untethered. It bounded at up to 1.3 m/s using a controller that needed no feedback about the body's state and relied on the legs' passive dynamics. In January 2003 it galloped, which the lab calls a world first for a legged robot. The same idea of springy legs driven by few motors later appeared in Minitaur.
- Type
- Quadruped robot · Research & legacy platforms
- Maker
- McGill Ambulatory Robotics Lab (Canada)
- Released
- 1998
- Price
- Not for sale
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- No programmability
Price and shipping
University research robot built from standard parts. Scout I came first (1996–1998), and Scout II followed from 1998.
Shipping: N/A. Never sold. It stayed a research robot in McGill's lab.
Specifications
| Category | Quadrupeds · Research & legacy platforms |
|---|---|
| Released | 1998 |
| Country | Canada |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no public SDK to connect one. |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · Nothing found. |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Other |
| Audio | No audio |
| Compute type | x86 PC (Intel / AMD) |
| Compute | A modified off-the-shelf PC on board |
| Weight | ~25 kg (McGill Reporter, 2003) |
| Speed | 1.3 m/s bounding on flat ground (IJRR, 2005) |
| DOF | 4 actuated (one electric hip motor per leg), plus a passive spring in each leg. One version tested passive knees for trotting |
| Sensors | Not detailed in the sources found. The 1999 lab page describes an onboard pan-tilt camera and laser sensors |
| SDK | None public |
Common questions
How much does Scout II cost?
Not for sale. University research robot built from standard parts. Scout I came first (1996–1998), and Scout II followed from 1998.
Can Scout II be bought today?
No. It was never sold to the public.
Who makes Scout II?
Scout II is made by McGill Ambulatory Robotics Lab (Canada). It came out in 1998.
Can Scout II be programmed?
No programmability.
Does Scout II have AI chat or LLM support?
None. No built-in LLM and no public SDK to connect one.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Fastest Robot Dogs · the top 20 ranked by speed
- Robot Dog Actuators · how to choose the leg motors
- 8 vs 12 DOF Robot Dogs · two or three motors per leg
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
Similar robots
 Stanford DoggoStanford Student Robotics (Extreme Mobility team)Not for sale
 Laikago / Laikago ProUnitree Robotics (China)Was quote-only
 Swiss-Mile / RIVR wheeled-legged robotSwiss-Mile, now RIVR (Switzerland)Not for sale
 BigDogBoston Dynamics (US) for DARPANot for sale
 LS3 (Legged Squad Support System)Boston Dynamics (US) for DARPA/USMCNot for sale
 LittleDogBoston Dynamics (US) for DARPANot for sale
Sources
Scout II with compliant legs ↗ · IJRR 2005 paper ↗ · McGill Reporter (2003) ↗