Overview
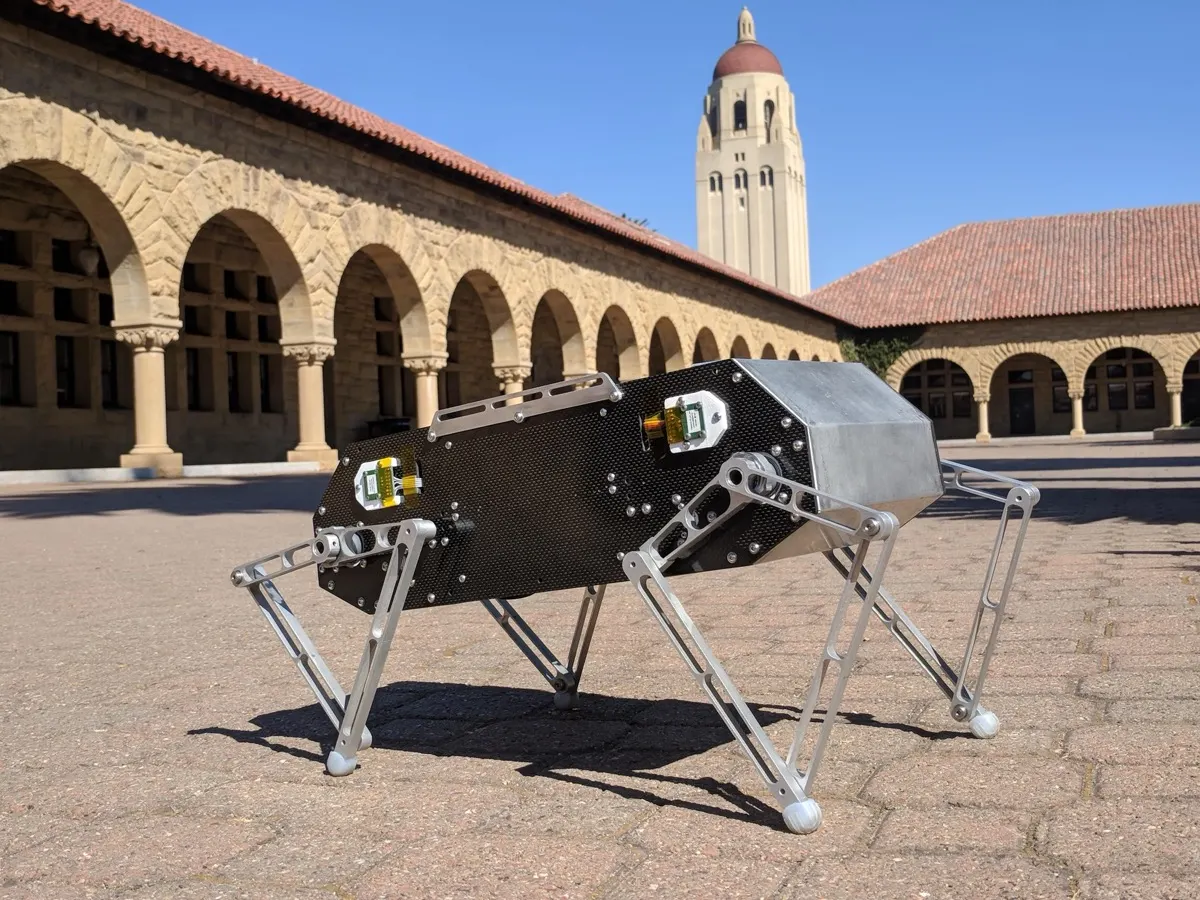
Unveiled at ICRA in May 2019, Doggo showed that a student-built, fully open-source quadruped with off-the-shelf brushless motors could match or beat far more expensive lab robots in vertical jumping agility. Its paper reports a 1.14 m peak jump, measured as center-of-mass rise from a crouch, and 2.23 m/s agility. That was more than double Minitaur's 0.48 m. It directly inspired the Stanford Pupper line and many hobby quadrupeds. The design files remain on GitHub but the team moved on to Pupper.
- Type
- Quadruped robot · Research & legacy platforms
- Maker
- Stanford Student Robotics (Extreme Mobility team)
- Released
- 2019
- Price
- Not for sale
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- Open source (hardware + software)
Price and shipping
Never sold. The open-source design needs only hand tools to build and costs under $3,000 in parts
Shipping: Build it. Never sold. It must be built from the open-source design files.
Specifications
| Category | Quadrupeds · Research & legacy platforms |
|---|---|
| Released | 2019 |
| Country | USA |
| Availability | Not for sale (research) |
| Jumping Robots | Ranked #4 by jump height |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No built-in LLM. Its SDK lets software on a computer control it. |
| MuJoCo simulation | None found · Nothing found. The repo has CAD files but no URDF or simulator model. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · Nothing found. |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Compute | Teensy microcontroller + ODrive motor controllers |
| Weight | 4.8 kg |
| Speed | 0.9 m/s (2 mph) steady trot, 1.14 m jump |
| DOF | 8 (2 brushless motors per leg, five-bar legs) |
| Sensors | IMU, motor encoders |
| SDK | Open-source firmware (C++) on GitHub |
Common questions
How much does Stanford Doggo cost?
Not for sale. Never sold. The open-source design needs only hand tools to build and costs under $3,000 in parts.
Can Stanford Doggo be bought today?
No. It was never sold to the public.
Who makes Stanford Doggo?
Stanford Doggo is made by Stanford Student Robotics (Extreme Mobility team). It came out in 2019.
Can Stanford Doggo be programmed?
Open source (hardware + software). Open-source firmware (C++) on GitHub.
Does Stanford Doggo have AI chat or LLM support?
Possible via SDK. No built-in LLM. Its SDK lets software on a computer control it.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Fastest Robot Dogs · the top 20 ranked by speed
- Robot Dog Actuators · how to choose the leg motors
- 8 vs 12 DOF Robot Dogs · two or three motors per leg
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
Similar robots
 Laikago / Laikago ProUnitree Robotics (China)Was quote-only
 Swiss-Mile / RIVR wheeled-legged robotSwiss-Mile, now RIVR (Switzerland)Not for sale
 BigDogBoston Dynamics (US) for DARPANot for sale
 LS3 (Legged Squad Support System)Boston Dynamics (US) for DARPA/USMCNot for sale
 LittleDogBoston Dynamics (US) for DARPANot for sale
 MIT Mini CheetahMIT Biomimetic Robotics Lab (US)Not for sale