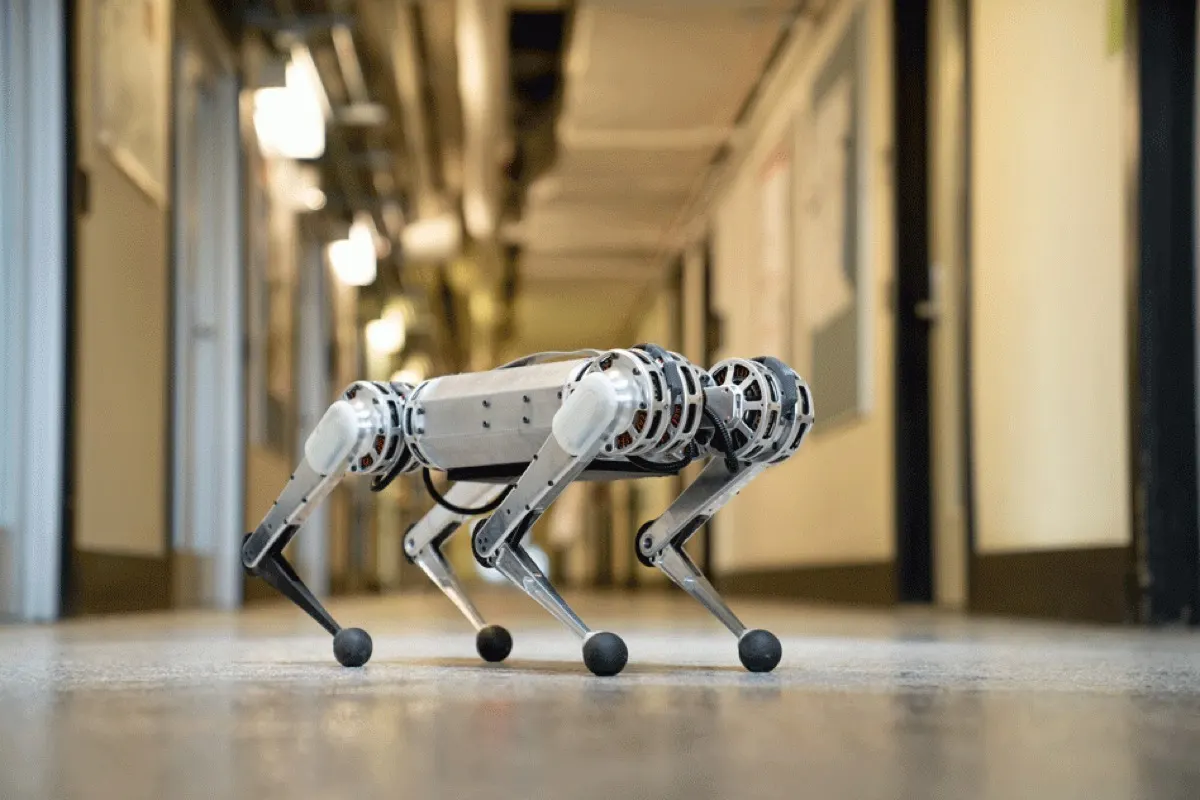
Not soldAbout ten units were built and loaned to other labs; control software is open source (MIT license).
Not for sale (research)BackflipOpen softwareLow-cost actuators
Not soldShipping: N/A. Never sold; commercial derivatives such as Unitree's dogs fill the role.
Overview
The first four-legged robot to do a backflip (2019), with modular low-cost actuators that became the template for Unitree and much of the industry. MIT open-sourced the control stack, and a 2022 learned controller pushed it to 3.9 m/s. Its bigger sibling Cheetah 3 (2018) showed blind stair-climbing.
Specifications
| Category | Quadrupeds · Research & legacy platforms |
|---|---|
| Released | 2019 |
| Availability | Not for sale (research) |
| Programmability | Open source (hardware + software) |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | x86 PC (Intel / AMD) |
| Compute | UP Board (x86) + custom motor controllers |
| Weight | ~9 kg |
| Speed | 2.45 m/s (2019); 3.9 m/s with learned controller (2022) |
| DOF | 12 |
| Sensors | IMU, motor encoders |
| SDK | Open-source Cheetah-Software (C++, MIT license) |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 Stanford DoggoStanford Student Robotics (Extreme Mobility team)Not sold
 Laikago / Laikago ProUnitree Robotics (China)Was quote-only
 Swiss-Mile / RIVR wheeled-legged robotSwiss-Mile, now RIVR (Switzerland)Not sold
 BigDogBoston Dynamics (US) for DARPANot sold
 LS3 (Legged Squad Support System)Boston Dynamics (US) for DARPA/USMCNot sold
 LittleDogBoston Dynamics (US) for DARPANot sold
Image credits
- Image 1: source (MIT News press image)