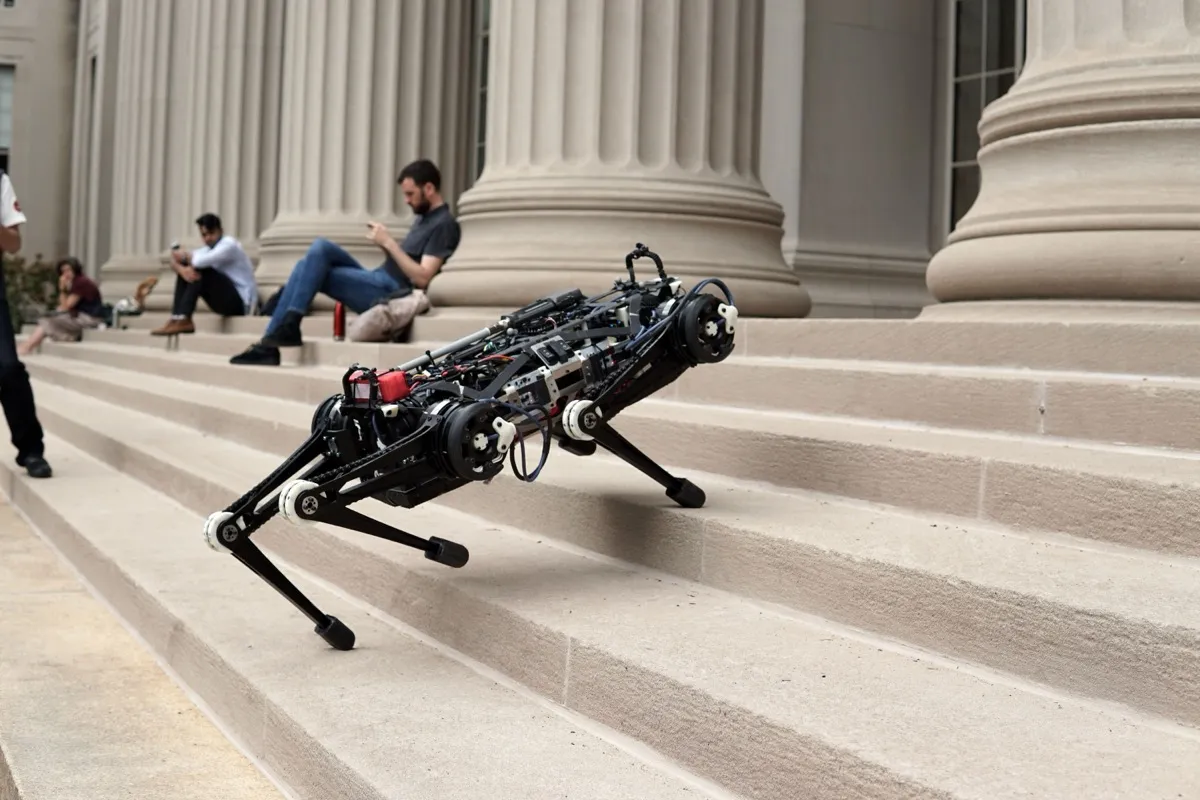
Not for saleLab research platform, funded by Naver, Toyota Research Institute, Foxconn and the Air Force Office of Scientific Research.
Not for sale (research)Guinness jump recordBlind stair climbingProprioceptive actuators
Not for saleShipping: N/A. Never sold. It stayed a research robot in MIT's lab.
Overview
Holder of the Guinness World Record for the highest jump by a quadruped robot, a 78.74 cm (31 in) standing leap onto a raised platform, made in 2017 and revealed in July 2018. It climbed stairs and stepped over debris blind, since a contact detection algorithm sensed each footfall through its motors instead of cameras. Its custom motors with single-stage planetary gears control leg forces without force sensors. The same actuator approach was scaled down for the Mini Cheetah in 2019. A convex model-predictive controller let it trot, bound, pace, pronk and gallop at up to 3 m/s. The lab aimed it at inspection work in hazardous sites such as damaged power plants, but it was never sold.
Specifications
| Category | Quadrupeds · Research & legacy platforms |
|---|---|
| Released | 2018 |
| Country | USA |
| Availability | Not for sale (research) |
| Jumping Robots | Ranked #6 by jump height |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no public SDK to connect one. |
| MuJoCo simulation | None found · No MuJoCo model found. MIT's Cheetah-Software ships Cheetah 3 meshes and a dynamics model for its own simulator only. Cheetah-Software ↗ |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · Nothing found. No public URDF of Cheetah 3 exists. |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | x86 PC (Intel / AMD) |
| Compute | Embedded PC with a 2nd-gen Intel Core i7 laptop CPU (Ubuntu with a real-time kernel), plus ARM Cortex-A8 leg controllers over EtherCAT |
| Weight | 45 kg (about 90 lb). Body 60 × 25.6 × 20 cm with 34 cm leg links |
| Speed | 3 m/s forward, 1 m/s sideways and 180°/s turning with convex MPC (2018) |
| DOF | 12 (3 per leg), all with near-identical proprioceptive actuators (230 N·m peak, 21 rad/s, 7.67:1 planetary gear plus a 1.15:1 chain to the knee) |
| Sensors | IMU and joint encoders only for walking, with no force, torque or foot contact sensors. Cameras were added later to map larger obstacles (model unconfirmed). 450 Wh LiPo battery, about 2 h runtime |
| SDK | None public. An operator sends velocity commands over LCM. MIT's open-source Cheetah-Software (C++) includes a Cheetah 3 model and configs |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 Stanford DoggoStanford Student Robotics (Extreme Mobility team)Not for sale
 Laikago / Laikago ProUnitree Robotics (China)Was quote-only
 Swiss-Mile / RIVR wheeled-legged robotSwiss-Mile, now RIVR (Switzerland)Not for sale
 BigDogBoston Dynamics (US) for DARPANot for sale
 LS3 (Legged Squad Support System)Boston Dynamics (US) for DARPA/USMCNot for sale
 LittleDogBoston Dynamics (US) for DARPANot for sale
Image credits
- Image 1: source (MIT News press image, courtesy of the researchers)