Comparison table
| Unit | Price | Torque | Speed | Weight | Status |
|---|---|---|---|---|---|
| Unitree GO-M8010-6 | $369 | 23.7 N·m maximum at the output | about 286 rpm at 24 V | about 530 g | Available |
| Unitree A1 Motor | $500 | 33.5 N·m maximum instantaneous | about 200 rpm | 605 g | Available |
| CubeMars AK80-9 V3.0 KV100 | $479.90 – $579.90 | 9 N·m rated | 390 rpm rated | 490 g | Available |
| CubeMars AK70-10 KV100 | $398.90 – $498.90 | 8.3 N·m rated | 148/310 rpm rated | 621 g | Available |
| MyActuator RMD-X8-P9-25 (formerly RMD-X8 Pro 1:9) | $450 – $557 | 10 N·m rated | 110 rpm rated at 48 V | 710 g | Available |
| mjbots qdd100 beta 3 | $879 | 16 N·m peak | about 383 rpm at 24 V | 507 g | Available |
| DAMIAO DM-J4310-2EC V1.1 | $115 – $125 | 3 N·m rated | 120 rpm rated | about 300 g | Available |
| DAMIAO DM-J8009P-2EC | $395 – $400 | 20 N·m rated | 100 rpm rated | 930 g | Available |
| RobStride 01 / 02 / 03 / 04 | $130 – $255 | 6–40 N·m rated by model | 195–410 rpm no load | 380–1,420 g | Available |
| SteadyWin GIM4305-10 | $68 | 1.0 N·m rated | 300 rpm rated | 150 g with driver | Available |
| SteadyWin GIM8108-8 | $93.89 | 7.5 N·m rated, 22 N·m stall | 110 rpm rated | 378 g without driver | Available |
| MIT Mini Cheetah actuator | Not sold | 17 N·m peak | about 380 rpm at 24 V | about 480 g | Research only |
| Berkeley Humanoid Lite cycloidal actuators (6512 and 5010) | $136 – $188 in parts | no rating published | – | – | Available |
Unitree GO-M8010-6
Unitree online shop (shop.unitree.com, USD prices), October 2026 check, $369 with free shipping, listed as backordered. Resellers (Robotopian, ZennixTek, Sonny Robotics) also list it (unconfirmed).
The GO-M8010-6 is the joint module Unitree built for the Go1 robot dog and later sold on its own. It packs a brushless motor, a 6.33:1 planetary reducer, an absolute encoder and an FOC driver into a puck under 100 mm across. In the Go1 the knee adds a 1.5:1 belt stage, which Unitree quotes as 35.55 N·m at the knee. Its low price made it one of the most common off-the-shelf quasi-direct-drive actuators for student and hobby legged robots.
- Torque
- 23.7 N·m maximum at the output (Unitree's Go1 page gives 23.7 N·m for the body and thigh joints)
- Speed
- 30 rad/s (about 286 rpm) maximum at 24 V
- Weight
- about 530 g (unconfirmed, Unitree's Go1 page gives 520 g per joint motor)
- Size
- 96.5 × 92.5 × 42.3 mm
- Voltage
- 12–30 V DC (24 V recommended), 45 V overvoltage protection, 60 V absolute maximum
- Current
- 40 A maximum phase current
- Gearing
- 1:6.33 planetary
- Motor
- brushless permanent-magnet synchronous motor with built-in FOC driver
- Feedback
- single-turn absolute encoder, 15-bit; reports torque, angle, angular velocity and temperature
- Interface
- RS-485 at 4 Mbit/s, up to 15 motors per bus, 6,000 Hz control frequency, XT30PB(2+2) connector
- Other
- Hybrid force-position command (feedforward torque plus stiffness and damping gains), quasi-direct-drive ratio so it is backdrivable. Torque constant 0.639 N·m/A. Speed, size, voltage, current, encoder and bus figures come from Unitree's documentation center, which blocked automated checks in October 2026 (unconfirmed).
Low-cost quadruped and robot-arm joints that need real torque control at a hobby-friendly price, with official SDK and wiring documentation.
CAN-based systems, since it only speaks RS-485, and loads above about 24 N·m without an extra belt or linkage reduction.
Robots in the guide that use it
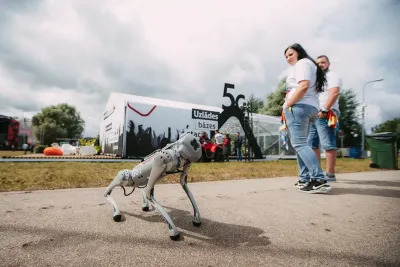
Unitree's own shop sells it as the Go1 joint motor. Unitree's Go2 page quotes about 45 N·m for its largest joint motor and lists the GO-M8010-6 only as a separate component, so Go2 appears to use a different motor (unconfirmed). Widely used in hobby quadrupeds and student robot competitions.
Sources Motor SDK guide (Unitree Documentation Center) ↗ · Go1 product page with joint torque figures (Unitree) ↗ · Unitree shop ↗ · Unitree actuator SDK (GitHub) ↗
Buying Unitree online shop lists free shipping, delivery time unconfirmed. Resellers such as Robotopian ship from Shenzhen.
Unitree A1 Motor
Unitree online shop (shop.unitree.com), October 2026 check, $500, listed as backordered.
The joint motor of the 2020 Unitree A1 quadruped, the robot that brought dynamic quadrupeds to many university labs. It delivers 33.5 N·m peak from a 605 g module with a crossed roller output bearing. Unitree still lists it, but the A1 robot itself has been replaced by Go1 and Go2.
- Torque
- 33.5 N·m maximum instantaneous
- Speed
- 21 rad/s (about 200 rpm) maximum joint speed
- Weight
- 605 g
- Voltage
- 20–40 V
- Gearing
- 1:9.1 planetary (unconfirmed)
- Motor
- brushless outrunner with integrated driver
- Feedback
- 15-bit encoder; reports torque, angle, angular velocity, angular acceleration and temperature
- Interface
- RS-485, 1 kHz communication control period
- Other
- Large crossed roller bearing on the output. Torque constant 0.9287 N·m/A. Commands are torque, angle, angular velocity, stiffness and damping.
Heavier legged-robot joints that need more torque than the GO-M8010-6 and work with Unitree's RS-485 SDK.
Anyone who needs it soon, since Unitree lists it as backordered, or CAN-bus systems.
Robots in the guide that use it
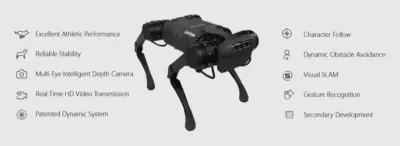
Many 2020–2022 university legged-robot builds reused it.
Sources A1 motor page (Unitree) ↗ · Unitree shop ↗
Buying Unitree online shop, backordered, ship time unconfirmed.
CubeMars AK80-9 V3.0 KV100
CubeMars store, October 2026 check. Original AK80-9 KV100 $479.90 without driver board and $579.90 with it. V3.0 $579.90 on sale from $599.90, shown sold out. RobotShop listed V3.0 at $655.29 (unconfirmed).
CubeMars, the robotics brand of drone-motor maker T-MOTOR, was one of the first companies to sell Mini Cheetah style integrated actuators off the shelf. The AK80-9 became a default research actuator, and V3.0 raised peak torque to 22 N·m. CubeMars also sells the smaller AK60-6 ($298.90) and the higher-torque AK10-9 ($798.90).
- Torque
- 9 N·m rated, 22 N·m peak
- Speed
- 390 rpm rated, 570 rpm no load at 48 V
- Weight
- 490 g
- Size
- Ø98 × 38.5 mm
- Voltage
- 48 V rated
- Current
- 12 A rated, 28 A peak
- Gearing
- 9:1 planetary, 15 arcmin (0.25°) backlash
- Motor
- brushless outrunner (KV100) with integrated driver
- Feedback
- single 16-bit magnetic encoder on V3.0 (CubeMars's older AK80-9 table lists 14-bit)
- Interface
- CAN and UART, XT30 2+2 power/CAN connector
- Other
- Supports servo mode and MIT mode (the Mini Cheetah style position, velocity, torque and gain command). Low ratio keeps it backdrivable, back-drive torque 0.51 N·m. Torque constant 0.095 N·m/A. Overcurrent, over/undervoltage and overtemperature protection.
Research quadrupeds, exoskeleton joints and arm shoulders that want an MIT-mode compatible QDD actuator from an established brand.
Tight budgets, since RobStride and Steadywin sell similar torque for well under half the price, or systems that need EtherCAT.
A common pick for exoskeletons, Mini Cheetah style quadruped builds and university legged robots.
Sources AK80-9 V3.0 specs (CubeMars) ↗ · Original AK80-9 KV100 spec table (CubeMars) ↗ · CubeMars store ↗
Buying CubeMars store, shipping calculated at checkout with free shipping over $200 (origin and time unconfirmed). Also sold by RobotShop, Foxtech and OpenELAB (unconfirmed).
CubeMars AK70-10 KV100
CubeMars store, October 2026 check, $398.90 without driver board and $498.90 with it, both shown sold out.
A taller, narrower sibling of the AK80-9 with a 10:1 planetary stage and 24.8 N·m peak. It runs from 24 V or 48 V, so it suits smaller battery packs. Like the rest of the AK line it accepts MIT-mode commands.
- Torque
- 8.3 N·m rated, 24.8 N·m peak
- Speed
- 148/310 rpm rated, 240/480 rpm no load at 24/48 V
- Weight
- 621 g
- Size
- Ø89 × 50.25 mm
- Voltage
- 24 or 48 V
- Current
- 7.2 A rated, 23.2 A peak
- Gearing
- 10:1 planetary, 0.2° backlash
- Motor
- brushless outrunner (KV100) with integrated driver
- Feedback
- 14-bit magnetic encoder (single)
- Interface
- CAN and UART (XT30PW-M power, A1257WR-S-4P CAN, A1257WR-S-3P UART)
- Other
- Supports servo and MIT control modes.
Mid-size legged-robot hips and knees that need a little more peak torque than the AK80-9 in a narrower body.
Weight-critical designs, since it is heavier than the AK80-9 for similar rated torque.
CubeMars features it in student-built robot dogs.
Sources AK70-10 specs (CubeMars) ↗ · CubeMars store ↗
Buying CubeMars store, shipping calculated at checkout with free shipping over $200 (origin and time unconfirmed).
MyActuator RMD-X8-P9-25 (formerly RMD-X8 Pro 1:9)
October 2026 check. Robotics Center of Silicon Valley about $450 and RobotShop $557.24 including US tariffs were reported but could not be re-opened (unconfirmed). Robotopian's catalog showed only the X8-120 and X6-40 at the time of the check.
MyActuator's X series is a widely sold line of integrated actuators. The X8 Pro 1:9 was renamed RMD-X8-P9-25 in the V2 naming scheme, where P9 is the planetary ratio and 25 the peak torque. The family spans the small X4 and X6 up to X8 and X10 variants with higher ratios and EtherCAT options, such as the 120 N·m X8-120.
- Torque
- 10 N·m rated, 25 N·m peak
- Speed
- 110 rpm rated at 48 V
- Weight
- 710 g
- Size
- Ø98 mm, 51 mm long overall per the installation drawing
- Voltage
- 48 V
- Current
- 3.2 A rated, 8 A peak
- Gearing
- 9:1 planetary, 10 arcmin backlash
- Motor
- brushless, 21 pole pairs, integrated driver
- Feedback
- 18-bit encoder (single encoder on standard model)
- Interface
- CAN at 1 Mbps or RS-485 at 115,200, 500 k, 1 M or 2.5 Mbps, chosen at order (C or R suffix)
- Other
- 0.61 N·m anti-force (back-drive) torque. 985 N axial and 1250 N radial payload. 80% efficiency. Brake and IP54 only as custom options.
Robot-arm and humanoid joints that want a well-documented geared actuator with an 18-bit encoder and a choice of CAN or RS-485.
Fast legged locomotion on a budget, since it is slower and pricier than RobStride or Unitree units of similar peak torque.
Popular in robot arms and small humanoid and quadruped research builds. Seeed Studio documents other X-series models (X4, X8-120, X12, X15) with its reComputer boards.
Sources X8-25 product page and parameter table (MyActuator) ↗ · Seeed Studio wiki for the X series (other models) ↗
Buying MyActuator has a US office (MyActuator USA, Fremont, California) and RobotShop carries the line, with shipping cost and time unconfirmed. AliExpress sellers ship from China.
mjbots qdd100 beta 3
mjbots store, October 2026 check. Shown as sold out, 'not currently stocked, minimum order qty 50'. Volume pricing $849 (10–49), $834 (50–99) and $819 (100+).
The qdd100 is the integrated servo from mjbots, Josh Pieper's one-person US company that also makes the moteus brushless controllers. It pairs a planetary reducer with a moteus driver on CAN-FD, and all firmware is open source. Its 16 N·m peak and good tooling made it the standard actuator for the Upkie wheeled biped.
- Torque
- 16 N·m peak (under 1 s), 10 N·m for 60 s, 6 N·m for 400 s, 3.3 N·m continuous
- Speed
- 2,300 °/s (about 383 rpm) at 24 V, 3,600 °/s (600 rpm) at 36 V
- Weight
- 507 g
- Size
- Ø100 × 44 mm
- Voltage
- 10–44 V
- Power
- 500 W peak power
- Gearing
- planetary, ±0.25° backlash
- Motor
- brushless, open-source moteus controller built in, 15–30 kHz control rate
- Interface
- 5 Mbps CAN-FD, 2× XT30 power and 2× JST PH-3 data
- Other
- Fully open-source driver firmware. Sold as a beta product with a one-year warranty.
Builders who value open-source firmware, CAN-FD and good documentation from a US vendor, such as Upkie builders.
Small orders right now, since mjbots lists a 50-unit minimum, or anyone who wants the cheapest torque per dollar.
Robots in the guide that use it
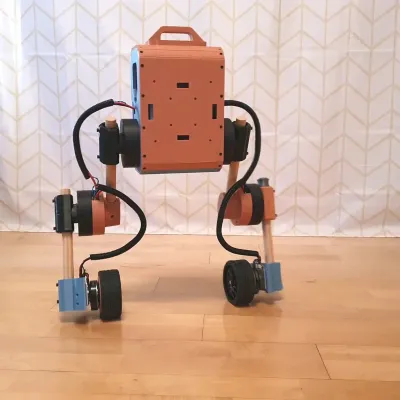
mjbots' own quad A1 research quadruped (unconfirmed).
Sources mjbots store ↗ · moteus firmware (GitHub) ↗
Buying mjbots ships from the US, shipping calculated at checkout. Not stocked at the time of the check and only quoted at a 50-unit minimum.
DAMIAO DM-J4310-2EC V1.1
October 2026 check. Foxtech $116–$120 (24 V and 48 V driver versions). Robotopian $115, Robotics Center of Silicon Valley and AIFITLAB $125 (unconfirmed).
DAMIAO's small geared joint motor became popular through the open-source OpenArm project, which uses it for its lighter joints near the wrist (exact joint assignment unconfirmed). The second encoder on the output means the joint knows its absolute angle at power-up without homing. Enactic, OpenArm's maker, hosts English DAMIAO documentation.
- Torque
- 3 N·m rated, 7 N·m peak
- Speed
- 120 rpm rated, 200 rpm no load at 24 V
- Weight
- about 300 g
- Size
- Ø56 × 46 mm
- Voltage
- 24 V rated (24 V and 48 V driver versions sold)
- Current
- 2.5 A rated, 7.5 A peak
- Gearing
- 10:1
- Motor
- brushless, 14 pole pairs, integrated driver
- Feedback
- two 14-bit single-turn magnetic encoders (motor side and output side)
- Interface
- CAN at 1 Mbps, UART at 921,600 bps for tuning
- Other
- MIT, speed and position control modes. Output encoder gives absolute joint position at power-up.
Wrist and forearm joints of robot-learning arms, where dual encoders and low price matter more than raw torque.
Legged-robot joints that need high peak torque or fast impacts.
Robots in the guide that use it
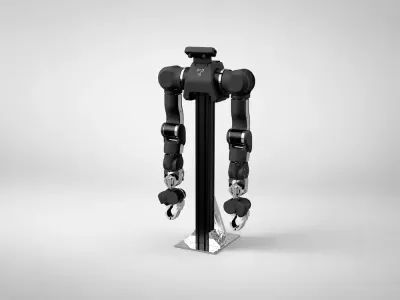
Sources Spec page (DAMIAO docs hosted by Enactic) ↗ · OpenArm 2.0 motor specifications ↗ · Foxtech store ↗
Buying Robotopian ships from Shenzhen (some stock in Santa Clara, California), 9–15 business days. Foxtech and AliExpress also sell it.
DAMIAO DM-J8009P-2EC
October 2026 check. Robotopian $395 (backordered), Foxtech $398, Robotics Center of Silicon Valley $400 (unconfirmed).
The largest motor in the OpenArm, where a 40 N·m unit belongs at the shoulder (OpenArm's docs list the motors without naming joints, so the assignment is unconfirmed). It is a low-ratio, backdrivable 9:1 unit with a crossed roller output bearing that takes arm bending loads, which is what the P suffix marks against the plain DM-J8009. The dual encoders give absolute output position at power-up.
- Torque
- 20 N·m rated, 40 N·m peak
- Speed
- 100 rpm rated; no load 160 rpm at 24 V, 320 rpm at 48 V
- Weight
- 930 g
- Size
- Ø98 × 61.7 mm
- Voltage
- 24 V nominal, 24–48 V
- Current
- 20 A rated, 50 A peak
- Gearing
- 9:1
- Motor
- brushless, 21 pole pairs, integrated driver
- Feedback
- two 14-bit single-turn magnetic encoders
- Interface
- CAN at 1 Mbps, UART at 921,600 bps for tuning
- Other
- Crossed roller bearing on the output (the P suffix). MIT, speed and position modes.
Shoulder and elbow joints of human-scale arms and small legged robots that need 40 N·m peak at a low price.
Lightweight builds, since it weighs nearly 1 kg.
Robots in the guide that use it
Sources Spec page (DAMIAO docs hosted by Enactic) ↗ · OpenArm 2.0 motor specifications ↗ · Foxtech store ↗ · Robotopian listing (spec table) ↗
Buying Robotopian ships from Shenzhen (some US stock in Santa Clara), 9–15 business days. Foxtech and AliExpress also sell it.
RobStride 01 / 02 / 03 / 04
RobStride official retail prices, October 2026 check. RS01 $130, RS02 $145, RS03 $225, RS04 $255. Robotics Center of Silicon Valley listed RS04 at $285 (unconfirmed).
RobStride Dynamics was founded in November 2023 by engineers who had led Xiaomi's robot-joint team (unconfirmed), and its prices undercut most rivals. The RS04 gives 120 N·m peak for $255. K-Scale's K-Bot and Hugging Face's LeRobot Humanoid both chose RobStride, which built a large hobby following. The line also includes the RS00 (14 N·m peak, 310 g), the tiny RS05 (5.5 N·m, 191 g) and the RS06 (36 N·m, 621 g).
- Torque
- RS01 and RS02 6 N·m rated, 17 N·m peak. RS03 20 N·m rated, 60 N·m peak. RS04 40 N·m rated, 120 N·m peak.
- Speed
- No load RS01 315 rpm (36 V), RS02 410 rpm (48 V), RS03 195 rpm (48 V), RS04 200 rpm (48 V)
- Weight
- RS01 380 g, RS02 405 g, RS03 880 g, RS04 1,420 g
- Size
- RS01 78.5 × 78.5 × 40 mm, RS02 78.5 × 78.5 × 45.5 mm, RS03 106 × 106 × 56 mm, RS04 120 × 120 × 56 mm
- Voltage
- RS01 24–48 V (36 V rated), RS02 24–60 V, RS03 and RS04 15–60 V (48 V rated)
- Current
- Peak phase current RS01/RS02 23 A, RS03 43 A, RS04 90 A
- Gearing
- RS01/RS02 7.75:1, RS03/RS04 9:1, machined steel planetary gears
- Motor
- brushless with integrated FOC driver
- Feedback
- 14-bit magnetic encoders, one on RS01, two (motor and output) on RS02, RS03 and RS04
- Interface
- CAN at 1 Mbps. XT30PB connector on RS01 and RS02, XT30 plus GH1.25 on RS03 and RS04
- Other
- IP52 standard, IP67 on request (an RS02-IP67 version at 490 g is listed). Quasi-direct-drive ratios keep them backdrivable.
Humanoid and quadruped builders who want the most torque per dollar with dual encoders and an active open-source software community.
RS-485 or EtherCAT systems, and buyers who need English documentation as polished as Western vendors'.
Robots in the guide that use it
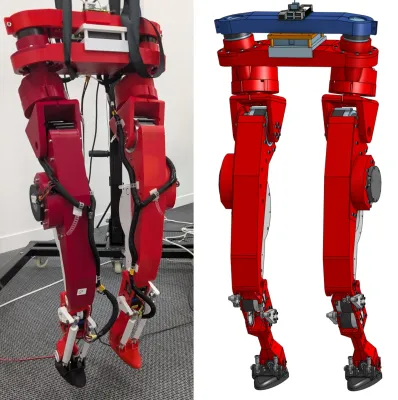
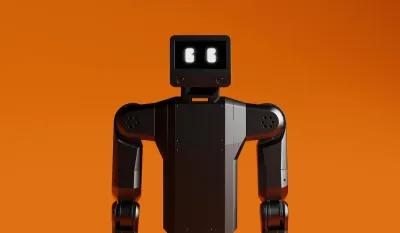
Hugging Face's LeRobot Humanoid BOM lists two RobStride 00, two 02, four 03 and four 05 (written 'O0/O2/O3/O5' in its BOM). RobStride's site lists K-Scale's K-Bot among community projects, and a RobStride post gave K-Bot's split as 4 RS04, 8 RS03 and 6 RS02 (unconfirmed). Many Chinese humanoid and quadruped startups use them. Xiaomi's CyberGear micro-actuator in CyberDog 2 is said to come from the same founding team (unconfirmed).
Sources RobStride 01 (official) ↗ · RobStride 02 (official) ↗ · RobStride 03 (official) ↗ · RobStride 04 (official) ↗
Buying RobStride's site links Amazon listings and an AliExpress store for ordering, so US delivery depends on the seller. Times unconfirmed.
SteadyWin GIM4305-10
SteadyWin official store, October 2026 check, $68 motor only (shown sold out), $127.80 with the GDS34 driver (the 'Pupper V3 version'), $128 with the GDZ34 driver, $80.50 with just an AS5047P encoder. Robotopian lists it at $68 and $127 (GDS34), motor-only variant backordered.
A tiny 53 mm brushless gearmotor that made a fully brushless, learning-capable quadruped affordable. Stanford's Pupper v3 uses twelve of them on a CAN bus with a dedicated driver firmware option. Its 10:1 ratio keeps it backdrivable enough for torque-based reinforcement-learning policies.
- Torque
- 1.0 N·m rated, 3.47 N·m peak
- Speed
- 300 rpm rated, 366 rpm max after reduction (24 V)
- Weight
- 150 g with driver
- Size
- Ø53 × 32 mm with driver
- Voltage
- 12–48 V (24 V rated)
- Current
- 2 A rated, 5.6 A peak
- Gearing
- 10:1 planetary, 15 arcmin backlash
- Motor
- brushless, 14 pole pairs
- Feedback
- 14-bit motor-side encoder, no output encoder
- Interface
- CAN (GDS34 driver); the GDZ34 driver adds RS-485 (unconfirmed)
- Other
- IP54. A 'Pupper V3 version' with the GDS34 driver is sold as an option.
Small, light brushless legged robots like Pupper v3, where twelve joints must cost under about $1,500 together.
Robots heavier than a few kilograms, since 3.5 N·m peak is modest.
Robots in the guide that use it
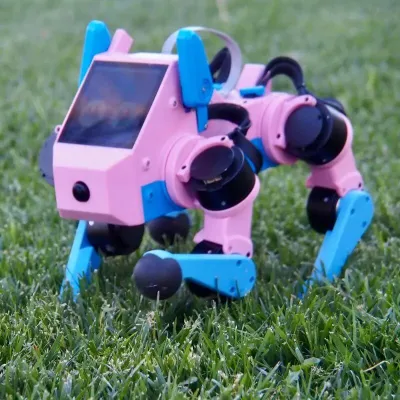
Also common in small DIY robot dogs.
Sources SteadyWin store ↗ · Robotopian listing (spec table) ↗
Buying SteadyWin store ships worldwide in 12–26 business days. Robotopian ships from Shenzhen in 9–15 business days. AliExpress sellers also carry it.
SteadyWin GIM8108-8
SteadyWin official store, October 2026 check, shown sold out. $93.89 motor only, $129.20 with the GDS68 CAN driver, $140.95 with GDS68 plus a secondary encoder, $159.53 with the GDZ68 driver, $176.24 for the brake version with GDS68 and secondary encoder. OpenELAB Europe lists €97.95 to €182.95.
The GIM8108-8 is a flat 92 mm gearmotor with roughly AK80-9 class torque for a fraction of the price. It is sold bare or with several SteadyWin driver boards, including CAN-only and CAN plus RS-485 versions. It became a favorite of hobby legged-robot builders on AliExpress.
- Torque
- 7.5 N·m rated, 22 N·m stall at 48 V (GDS68 driver); 6.6 N·m rated, 18.3 N·m stall at 24 V (GDZ468)
- Speed
- 110 rpm rated, 320 rpm max at 48 V (GDS68 driver); 196 rpm rated, 308 rpm max at 24 V (GDZ468)
- Weight
- 378 g without driver, 396 g with driver
- Size
- Ø92 × 44 mm without driver, Ø92 × 55 mm with driver
- Voltage
- 12–56 V (48 V nominal) with the GDS68 driver, 12–40 V (24 V nominal) with the GDZ468
- Current
- 7 A rated, 22 A stall at 48 V (GDS68); 7.5 A rated, 24.2 A stall (GDZ468)
- Gearing
- 8:1 planetary, steel gears, 15 arcmin backlash
- Motor
- brushless, 21 pole pairs
- Feedback
- 16-bit (GDS68) or 14-bit (GDZ468) encoder, optional second output encoder (2ES68 or 2EZ68) that keeps the single-turn position through a power loss
- Interface
- CAN (GDS68); CAN and RS-485 (GDZ68 or GDZ468); SteadyWin also lists a GDZ68H driver and Modbus support
- Other
- IP54. 225 N axial and 900 N radial load. Optional brake.
Cheap, flat, QDD-style joints for hobby quadrupeds and humanoids where a CubeMars AK80-9 is too expensive.
Buyers who want a single well-documented SKU, since driver, encoder and brake combinations vary by seller.
Widely used in DIY robot dogs, exoskeletons and hobby humanoids.
Sources SteadyWin store ↗ · OpenELAB spec table ↗
Buying SteadyWin store ships worldwide in 12–26 business days. AliExpress and eBay sellers also carry it.
MIT Mini Cheetah actuator
Research design, never sold by MIT. Many commercial units copy its layout and MIT-mode command format.
Ben Katz designed this compact quasi-direct-drive module for his 2018 MIT master's thesis, and twelve identical units powered the Mini Cheetah, the first quadruped to do a backflip (2019). It put the motor, a 6:1 planetary gearbox and its motor driver in one pancake housing with a CAN interface. Its PD-plus-feedforward command packet, now called 'MIT mode', became an industry standard.
- Torque
- 17 N·m peak (the figure attributed to the ICRA 2019 paper, unconfirmed); MIT's Cheetah-Software limits the motor to 3 N·m, which is 18 N·m after the 6:1 stage
- Speed
- about 40 rad/s (about 380 rpm) at 24 V (unconfirmed)
- Weight
- about 480 g (unconfirmed, secondary sources give 440–480 g)
- Size
- about Ø96 × 40 mm (unconfirmed)
- Voltage
- 24 V
- Gearing
- 6:1 single-stage planetary at the abduction and hip joints; the knee adds a belt stage for 9.33:1 overall
- Motor
- modified hobby brushless outrunner (an eBay and later iFlight motor at under a third of a T-Motor U8's price, per Katz's blog) with a custom FOC controller in the module. Motor torque constant 0.05 N·m/A
- Feedback
- magnetic encoder on the motor (AS5147, later MA700, per Katz's blog)
- Interface
- CAN
- Other
- Low ratio makes it highly backdrivable and impact tolerant.
Study as a reference design. Its papers, thesis and open firmware explain QDD actuator trade-offs better than any datasheet.
Buying, since MIT never sold it. Commercial descendants are easier to get.
Robots in the guide that use it
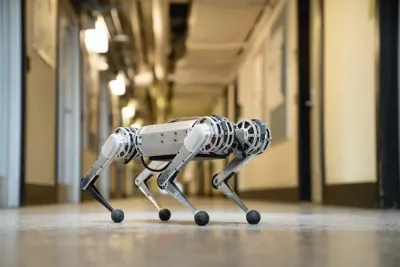
Its design became the template for Unitree's joint motors, CubeMars AK series 'MIT mode', and many open-source clones.
Sources Katz MS thesis, 'A low cost modular actuator for dynamic robots' (MIT DSpace) ↗ · Mini Cheetah ICRA 2019 paper (IEEE) ↗ · Mini Cheetah gear ratios and motor constants in Cheetah-Software (MIT GitHub) ↗ · Katz's build blog post introducing Mini Cheetah ↗
Buying Not sold.
Berkeley Humanoid Lite cycloidal actuators (6512 and 5010)
Bill-of-materials cost from the Berkeley Humanoid Lite paper (US prices). 6512 actuator $188 ($129 motor), 5010 actuator $136 ($84 motor). Built by the user; no assembled unit for sale.
The actuators of the open-source Berkeley Humanoid Lite pair hobby drone motors with a 3D-printed 15:1 cycloidal gearbox, a $19 ST motor-driver board and a $3 magnetic sensor. Cycloidal gears spread load across many teeth, which tolerates the limited accuracy of desktop printers better than planetary gears. Print files are free on MakerWorld.
- Torque
- no rated figure published; the paper's stiffness test ramped a 6512 to 20 N·m of commanded torque, and locomotion used about 30% of actuator capacity
- Gearing
- 15:1 3D-printed cycloidal drive (the ratio is set in the robot's actuator configuration), about 90% mechanical efficiency in typical operation
- Motor
- MAD Components M6C12 150KV drone motor (6512) or a 5010 drone motor, driven by an ST B-G431B-ESC1 board
- Feedback
- AS5600 magnetic position sensor
- Interface
- CAN 2.0 at 1 Mbps, 250 Hz control rate in the robot
- Other
- Transmission stiffness about 319 N·m/rad (6512). A 60-hour endurance test lifting a 0.5 kg pendulum showed stable efficiency and only slight backlash growth. The paper's BOM lists ten 6512 and twelve 5010 actuators per robot.
Learning how actuators work and building cheap humanoid or arm joints with a 3D printer.
High duty cycles or impacts that would wear printed plastic gears, or anyone who wants a ready-made unit.
Robots in the guide that use it
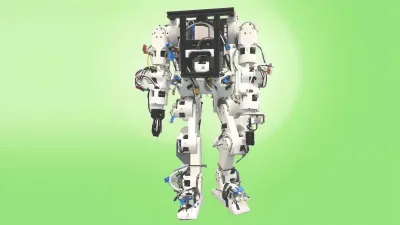
The 6512 is also used in UC Berkeley's MECENG 102B class to teach cycloidal drives.
Sources Berkeley Humanoid Lite project site ↗ · Paper (arXiv 2504.17249) ↗ · Build docs with CAD and print-file links (GitBook) ↗ · 6512 actuator print files (MakerWorld) ↗ · 5010 actuator print files (MakerWorld) ↗
Buying Parts sourced from common online stores; motors from MAD Components (shipping unconfirmed).