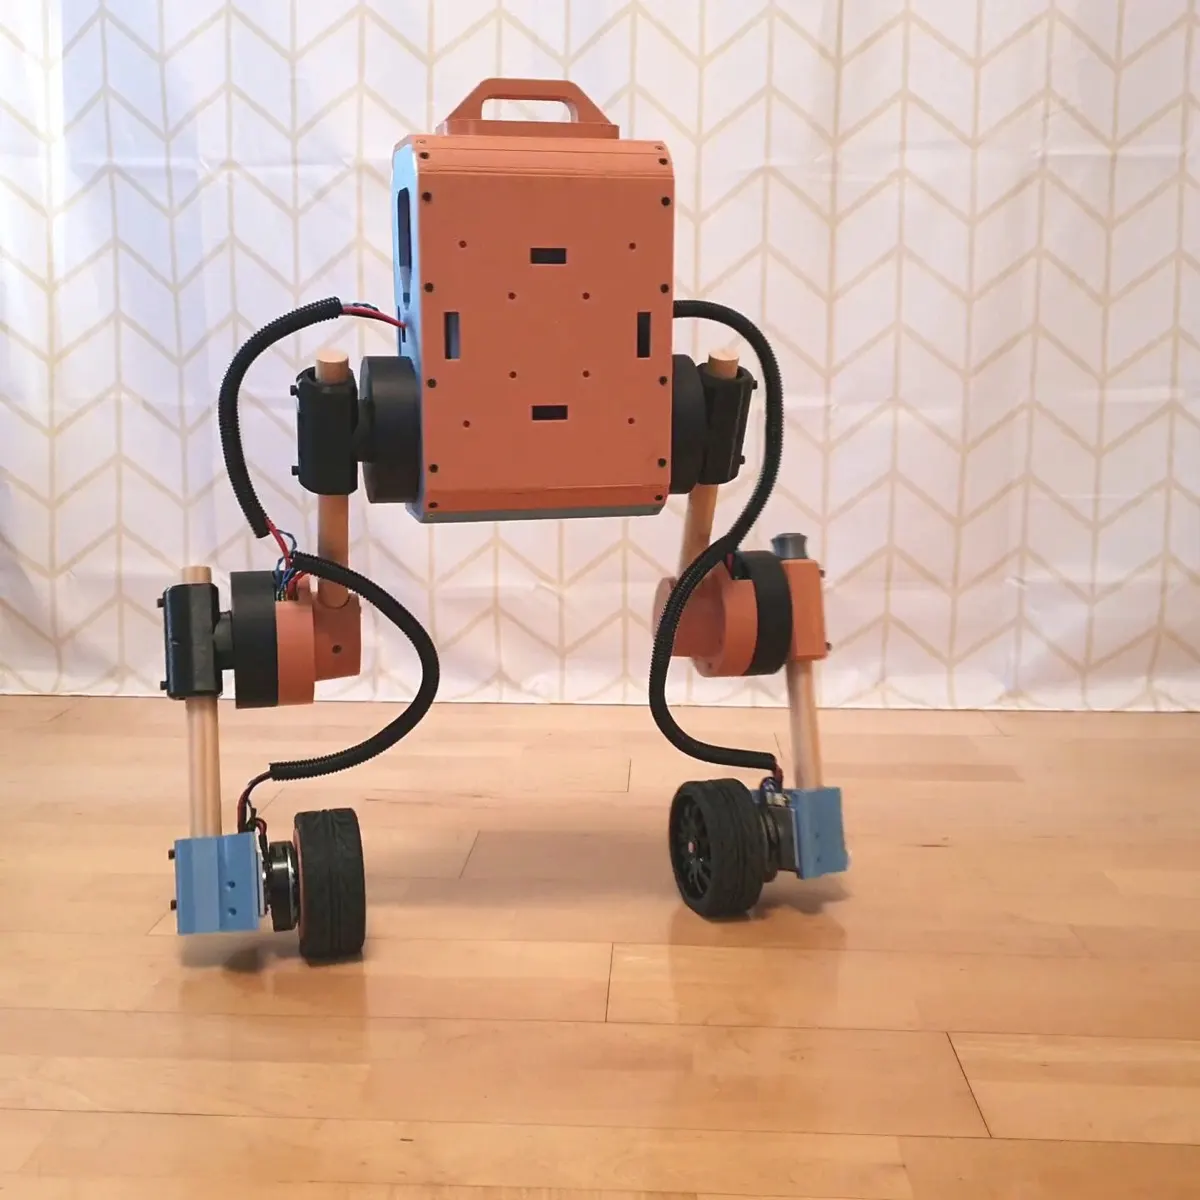
Overview
An open-source wheeled biped designed to be built with ordinary tools and mjbots qdd100 actuators. Its standout feature is the software, since Gymnasium environments and sim-to-real workflows make it a favorite for learning balance control and RL on real hardware. Expect to source every part and do the assembly.
- Type
- Biped robot · Wheel-legged balancers
- Maker
- Stéphane Caron / open-source community (France)
- Released
- 2022
- Price
- DIY (open source)
- Status
- Not for sale (research)
- Best for
- Ages 16+
- Programming
- Open source (hardware + software)
Price and shipping
Built from off-the-shelf parts (mjbots actuators, Raspberry Pi). No kit is sold
Shipping: Build (weeks). Not for sale. Parts come from mjbots and standard suppliers. Build instructions are on the docs site. Build guide ↗
Specifications
| Category | Bipeds · Wheel-legged balancers |
|---|---|
| Released | 2022 |
| Country | France |
| Availability | Not for sale (research) |
| DIY build plans | Upkie wheeled biped · parts $4,600 (estimate) · difficulty 4/5 |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No built-in LLM. Its SDK lets software on a computer control it. |
| MuJoCo simulation | Maker URDF only · Maker's URDF only. Official simulation uses PyBullet. Community MuJoCo course exists (Yhx888/LocoVLA). upkie_description ↗ |
| NVIDIA Isaac simulation | Maker URDF only · Maker's URDF only, no Isaac package. upkie_description ↗ |
| Gazebo simulation | Maker URDF only · Maker's URDF only, no Gazebo package. upkie_description ↗ |
| Best for | Ages 16+ (estimated) |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Raspberry Pi |
| Balance type | Wheel balance |
| Height | Not published |
| Weight | Not published |
| Compute | Raspberry Pi (4 or 5) |
| Speed | Not published |
| DOF | 6 (hip, knee, wheel per leg) |
| Sensors | IMU, actuator encoders |
| Balance | Wheel-inverted-pendulum balancing with the legs setting height. Controllers range from PID/MPC to learned policies. |
| SDK | Python and C++ with Gymnasium environments, Bullet/MuJoCo simulation, PyPI and conda packages |
Common questions
How much does Upkie cost?
DIY (open source). Built from off-the-shelf parts (mjbots actuators, Raspberry Pi). No kit is sold.
Can Upkie be bought today?
No. It was never sold to the public.
Who makes Upkie?
Upkie is made by Stéphane Caron / open-source community (France). It came out in 2022.
Can Upkie be programmed?
Open source (hardware + software). Python and C++ with Gymnasium environments, Bullet/MuJoCo simulation, PyPI and conda packages.
Does Upkie have AI chat or LLM support?
Possible via SDK. No built-in LLM. Its SDK lets software on a computer control it.
What age is Upkie for?
Ages 16+ (estimated).
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
- MuJoCo Guide · the simulator used to train walking robots
- ROS 2 Guide · the software framework many robots use
- Robot Vision and Depth Sensors · cameras, lidar and other distance sensors
Similar robots
 StackForce Mini Wheel-Legged
 XGO-Rider2
 DIABLO
 TITA
 TRON 1
 Ascento Guard
Sources
Image credits
- Image 1: source (README image, Apache-2.0 repository)