Comparison table
| Unit | Price | Torque | Speed | Weight | Interface | Status |
|---|---|---|---|---|---|---|
| DYNAMIXEL AX-12A | $57.39 | 1.5 N·m | 59 rpm no load at 12 V | 54.6 g | TTL, Protocol 1.0 | Available |
| DYNAMIXEL XL-320 | $30.94 | 0.39 N·m | 114 rpm no load at 7.4 V | 16.7 g | TTL, Protocol 2.0 | Available |
| DYNAMIXEL XL330-M288-T | $27.49 | 0.52 N·m | 103 rpm no load at 5 V | 18 g | TTL, Protocol 2.0 | Available |
| DYNAMIXEL XL330-M077-T | $27.49 | 0.215 N·m | 383 rpm no load at 5 V | 18 g | TTL, Protocol 2.0 | Available |
| DYNAMIXEL XC330-T288-T (XC330 family) | $103.39 | 0.92 N·m | 65 rpm no load at 11.1 V | 23 g | TTL, Protocol 2.0 | Available |
| DYNAMIXEL XL430-W250-T (and 2XL430-W250-T) | $27.50 | 1.4 N·m | 57 rpm no load at 11.1 V | 57.2 g | TTL, Protocol 2.0 | Available |
| DYNAMIXEL XC430-W150-T / XC430-W240-T | $137.89 | 1.4 N·m at 11.1 V (W150) | W150 runs 99 rpm no load at 11.1… | 65 g | TTL, Protocol 2.0 | Available |
| DYNAMIXEL XM430-W350-T / -R | $310.39 – $333.39 | 4.1 N·m | 46 rpm no load at 12 V | 82 g | TTL or RS-485, Protocol 2.0 | Available |
| DYNAMIXEL XH540-W270-T / -R | $620.89 – $632.39 | 9.9 N·m | 39 rpm no load at 12 V | 165 g | TTL or RS-485, Protocol 2.0 | Available |
| DYNAMIXEL MX-28 (MX-28AT / AR, 2.0 firmware) | $298.89 – $344.89 | 2.5 N·m | 55 rpm no load at 12 V | 72 g | TTL or RS-485, Protocol 1.0 and 2.0 | Available |
| DYNAMIXEL MX-64 (MX-64AT / AR, 2.0 firmware) | $425.39 – $436.89 | 6.0 N·m | 63 rpm no load at 12 V | 126 g | TTL or RS-485, Protocol 1.0 and 2.0 | Available |
| DYNAMIXEL-P PH54-200-S500-R | $3,541.89 | 44.7 N·m continuous | 33.1 rpm no load | 855 g | RS-485, Protocol 2.0 | Available |
DYNAMIXEL AX-12A
ROBOTIS America store, October 2026 check. A 6-pack sells for $310.39 there.
The AX-12 line goes back to the Bioloid kits of the mid-2000s (exact launch year unconfirmed), and the AX-12A is its updated form. It made the daisy-chained 'smart servo' idea popular, with one TTL bus carrying commands and feedback for every joint. It still uses a potentiometer instead of a magnetic encoder (unconfirmed) and speaks only Protocol 1.0, so today it is mostly a legacy part kept in production for kits and spares.
- Torque
- 1.5 N·m (15.3 kg·cm) stall at 12 V, 1.5 A
- Speed
- 59 rpm no load at 12 V (about 0.17 s/60°)
- Weight
- 54.6 g
- Size
- 32 × 50 × 40 mm
- Voltage
- 9–12 V (11.1 V recommended)
- Current
- stall 1.5 A at 12 V
- Gearing
- 254:1, engineering plastic gears
- Motor
- cored DC
- Feedback
- potentiometer-based position (unconfirmed), 0.29° resolution (1024 steps over 300°); position, temperature, load and input voltage readback
- Interface
- TTL half-duplex multidrop serial bus, 7,843 bps to 1 Mbps, DYNAMIXEL Protocol 1.0 only (not compatible with Protocol 2.0 packets)
- Range
- joint mode 0–300°, endless wheel mode
- Other
- Fits only AX-series frames. Plastic case and gears. Replacement gear sets cost $9.43 at ROBOTIS America.
Classroom kits, hexapods and repairs of existing Bioloid or PhantomX robots, where a daisy-chained servo with position and load feedback matters more than precision.
New designs that need a fine encoder, current control or modern Protocol 2.0 tooling, since the X series offers all of these for less money.
Robots in the guide that use it
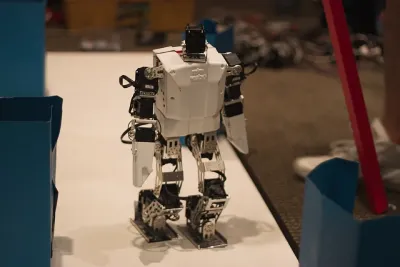 Bioloid Premium / GPWas ~$1,000 – $1,500
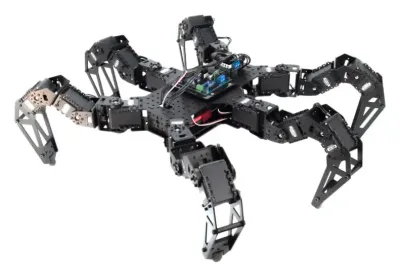 PhantomX AX HexapodWas $1,095.95 – $1,999.95
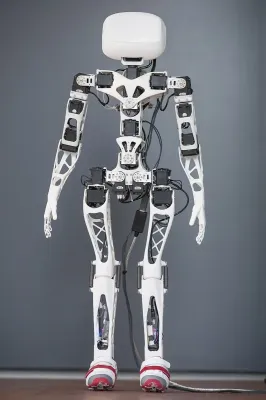 Poppy HumanoidDIY (open source)
Also the servo in many university hexapods, robot arms and Bioloid-derived RoboCup Junior and FIRA builds.
Sources Datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier. The store ships only within North, Central and South America.
DYNAMIXEL XL-320
ROBOTIS America store, October 2026 check.
The XL-320 arrived in 2014 (unconfirmed) with the DARwIn-MINI (later ROBOTIS MINI) kit as ROBOTIS's smallest Dynamixel. It speaks Protocol 2.0, unlike the AX series, but it kept the AX-style 300° joint range and coarse 0.29° resolution. The XL330 family has largely replaced it for new small robots.
- Torque
- 0.39 N·m (4.0 kg·cm) stall at 7.4 V, 1.1 A
- Speed
- 114 rpm no load at 7.4 V (about 0.09 s/60°)
- Weight
- 16.7 g
- Size
- 24 × 36 × 27 mm
- Voltage
- 6–8.4 V (7.4 V recommended)
- Current
- stall 1.1 A, no load 0.18 A at 7.4 V
- Gearing
- 238:1, engineering plastic gears
- Motor
- cored DC
- Feedback
- 0.29° resolution over 300°; position, temperature, load and input voltage readback
- Interface
- TTL half-duplex multidrop serial bus, 7,343 bps to 1 Mbps, DYNAMIXEL Protocol 2.0, 3-pin Molex 51065-0300 connector rather than the JST EHR-03 of the X series, so it needs its own cables
- Range
- joint mode 0–300°, endless wheel mode
- Other
- Plastic case and gears. Built for the ROBOTIS MINI humanoid and frame system.
Tiny humanoids, classroom arms and repairs of ROBOTIS MINI robots, where size and price matter more than torque.
Anything that needs real holding torque or accurate positioning, since the XL330-M288 is stronger, has a 4096-step encoder and costs less.
Robots in the guide that use it
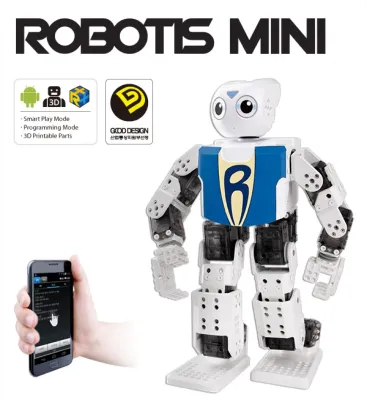
Also the servo of the Poppy Ergo Jr arm, which uses six of them.
Sources Datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store ↗ · Poppy Ergo Jr motor config (GitHub) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier.
DYNAMIXEL XL330-M288-T
ROBOTIS America store, October 2026 check. The listing warned of an estimated 2-month lead time.
The XL330 arrived around the start of 2021 and brought the full X-series feature set, 4096-step encoder, current control and Protocol 2.0, down to a 5 V, 18 g servo. The M288 is the torque version, and it became a default part for low-cost research hardware such as the upper joints of the Koch follower arm and the Reachy Mini Stewart-platform head. Its low voltage lets a USB-powered or single-cell build drive it directly.
- Torque
- 0.52 N·m (5.3 kg·cm) stall at 5 V, 1.47 A; 0.42 N·m at 3.7 V; 0.60 N·m at 6 V
- Speed
- 103 rpm no load at 5 V (about 0.10 s/60°); 76 rpm at 3.7 V; 123 rpm at 6 V
- Weight
- 18 g
- Size
- 20 × 34 × 26 mm
- Voltage
- 3.7–6 V (5 V recommended)
- Current
- stall 1.47 A at 5 V, standby 17 mA
- Gearing
- 288.4:1, engineering plastic gears
- Motor
- cored DC
- Feedback
- contactless 12-bit absolute magnetic encoder (ams AS5601), 4096 steps/rev; position, velocity, current, temperature, input voltage and trajectory readback
- Interface
- TTL half-duplex multidrop bus (3.3 V logic, 5 V tolerant), 9,600 bps to 4 Mbps, DYNAMIXEL Protocol 2.0; experimental S.BUS, iBUS and RC-PWM input modes
- Range
- 0–360° position mode, multi-turn extended position mode, velocity mode
- Other
- Six modes including current control and current-based position control, Cortex-M0+ MCU. Plastic case and gears.
Small arms, grippers, desk robots and toy-scale bipeds that run from 5 V and benefit from current sensing and a fine encoder at a hobby-servo price.
Load-bearing joints on anything bigger than a small desk robot, since 0.52 N·m and plastic gears run out quickly.
Robots in the guide that use it
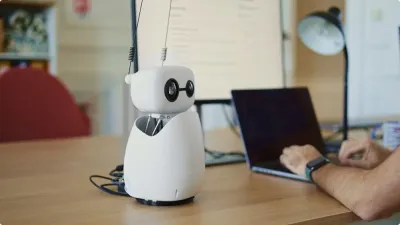
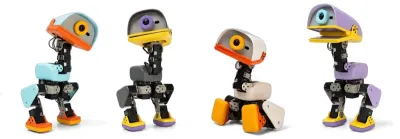
Also used in the LEAP Hand Lite (ROBOTIS sells an XL330 bundle) and many LeRobot-era leader and follower arms.
Sources Datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store ↗ · Koch arm BOM (GitHub) ↗ · Reachy Mini hardware docs (GitHub) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier. At the October 2026 check the product page warned of an estimated 2-month lead time.
DYNAMIXEL XL330-M077-T
ROBOTIS America store, October 2026 check.
The M077 is the fast, low-ratio twin of the XL330-M288, in the same 18 g case with the same electronics. Its 77.5:1 gearbox turns easily by hand, so it works as a joint sensor that can also apply light force feedback, which made it the standard leader-arm servo for the Koch arm. Reachy Mini uses two for its animated antennas.
- Torque
- 0.215 N·m (2.2 kg·cm) stall at 5 V, 1.47 A; 0.180 N·m at 3.7 V; 0.228 N·m at 6 V
- Speed
- 383 rpm no load at 5 V (about 0.03 s/60°); 278 rpm at 3.7 V; 456 rpm at 6 V
- Weight
- 18 g
- Size
- 20 × 34 × 26 mm
- Voltage
- 3.7–6 V (5 V recommended)
- Current
- stall 1.47 A at 5 V
- Gearing
- 77.5:1, engineering plastic gears
- Motor
- cored DC
- Feedback
- contactless 12-bit absolute magnetic encoder (ams AS5601), 4096 steps/rev; position, velocity, current, temperature, input voltage and trajectory readback
- Interface
- TTL half-duplex multidrop bus (3.3 V logic, 5 V tolerant), 9,600 bps to 4 Mbps, DYNAMIXEL Protocol 2.0; experimental S.BUS, iBUS and RC-PWM input modes
- Range
- 0–360° position mode, multi-turn extended position mode, velocity mode
- Other
- Low gear ratio makes it easy to backdrive by hand, which is why it is popular for teleoperation leader arms.
Leader arms for teleoperation, fast light mechanisms such as antennas or ears, and small wheels, where speed and easy backdriving matter.
Holding any real load, since stall torque is only about 0.2 N·m.
Robots in the guide that use it
Also common as the leader-arm servo in other low-cost teleoperation setups.
Sources Datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store ↗ · Koch arm BOM (GitHub) ↗ · Reachy Mini hardware docs (GitHub) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier.
DYNAMIXEL XC330-T288-T (XC330 family)
ROBOTIS America store, October 2026 check. The XC330-T181 and M288 variants list at the same price. The page warned of an estimated 2-month lead time.
The XC330 is the premium version of the XL330 form factor, with a coreless motor, full metal gears and dual bearings. The 12 V T288 and the 5 V M288 both reach about 1 N·m stall, the most of any servo in this case size. ToddlerBot uses the T288 for its neck, waist, hip yaw and gripper, and Reachy Mini's body rotation runs on a custom plastic-gear XC330-M288.
- Torque
- 0.92 N·m (9.4 kg·cm) stall at 11.1 V, 0.80 A; 0.76 N·m at 9 V; 1.00 N·m at 12 V
- Speed
- 65 rpm no load at 11.1 V (about 0.15 s/60°); 52 rpm at 9 V; 71 rpm at 12 V
- Weight
- 23 g
- Size
- 20 × 34 × 26 mm
- Voltage
- 6.5–12 V (11.1 V recommended); M-variants run on 3.7–6 V
- Current
- stall 0.80 A at 11.1 V, standby 17 mA
- Gearing
- 288.35:1, full metal gears, dual bearings
- Motor
- coreless DC
- Feedback
- contactless 12-bit absolute magnetic encoder (ams AS5601), 4096 steps/rev; position, velocity, current, temperature and input voltage readback
- Interface
- TTL half-duplex multidrop bus (5 V logic), 9,600 bps to 4 Mbps, DYNAMIXEL Protocol 2.0; experimental S.BUS, iBUS and RC-PWM input modes
- Range
- 0–360° position mode, multi-turn extended position mode, velocity mode
- Other
- Same 20 × 34 × 26 mm case as the XL330 but with metal gears and a coreless motor. Family has T288 and T181 (12 V) plus M288 and M181 (5 V) versions.
Small robots that need XL330 size but metal gears and roughly double the torque, such as fingers, necks and grippers on research hands and small humanoids.
Budget builds, since it costs nearly four times an XL330, and large joints that need more than about 1 N·m.
Robots in the guide that use it
Also used in the LEAP Hand (ROBOTIS sells an XC330 bundle).
Sources Datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store ↗ · ToddlerBot paper, Table 2 (arXiv) ↗ · Reachy Mini hardware docs (GitHub) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier. At the October 2026 check the product page warned of an estimated 2-month lead time and asked buyers to contact ROBOTIS America.
DYNAMIXEL XL430-W250-T (and 2XL430-W250-T)
ROBOTIS America store, October 2026 check. The dual-axis 2XL430-W250-T lists at $149.39.
The XL430 is the entry point to ROBOTIS's 430 case, the size most mid-range research robots are built around. TurtleBot 3 Burger drives its wheels with two of them, the PincherX 100 is built entirely from them, and Koch and WidowX arms use them where load is light. The dual-axis 2XL430 forms most of the joints of the ENGINEER kit and ToddlerBot's arms.
- Torque
- 1.4 N·m (14.3 kg·cm) stall at 11.1 V, 1.3 A
- Speed
- 57 rpm no load at 11.1 V (about 0.18 s/60°)
- Weight
- 57.2 g
- Size
- 28.5 × 46.5 × 34 mm
- Voltage
- 6.5–12 V (11.1 V recommended)
- Current
- stall 1.3 A at 11.1 V, standby 52 mA
- Gearing
- 258.5:1, engineering plastic gears
- Motor
- cored DC
- Feedback
- contactless 12-bit absolute magnetic encoder (ams), 4096 steps/rev; position, velocity, load, temperature and input voltage readback
- Interface
- TTL half-duplex multidrop bus (5 V logic), 9,600 bps to 4.5 Mbps, DYNAMIXEL Protocol 2.0
- Range
- 0–360° position mode, multi-turn extended position mode, velocity (wheel) mode
- Other
- No current-control mode (velocity, position, extended position and PWM only). Shares the 430 case and horn pattern with the XC430, XM430 and XH430. The 2XL430 packs two XL430 drives in one case for two-axis joints.
Low-cost arms, wheeled robots and pan-tilt heads that need a 4096-step encoder and 1.4 N·m in the standard 430 case.
Force-controlled tasks, since it lacks the current-control modes of the XM430, and long hard use, since its gears are plastic.
Robots in the guide that use it
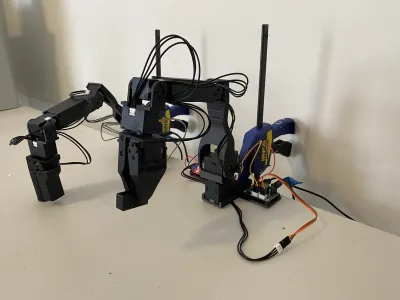 Koch v1.1 Low-Cost Robot Arm~$477 DIY parts (pair)
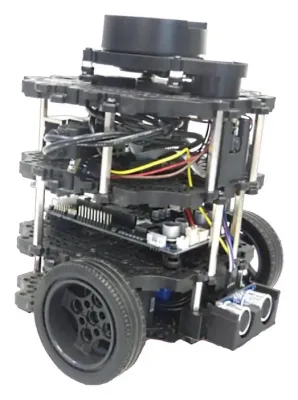 TurtleBot 3$758 – $1,934
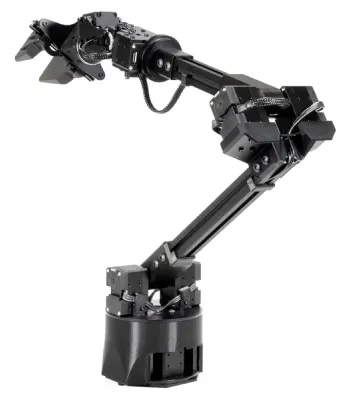 Interbotix WidowX 250Was $2,895.95
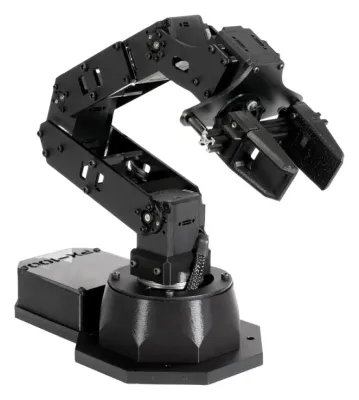 Interbotix PincherX 100Was $769.95
 ALOHA 2 / Trossen AI Stationary$23,995.95
 Mobile ALOHA~$32,000 (BOM) / $33,696…
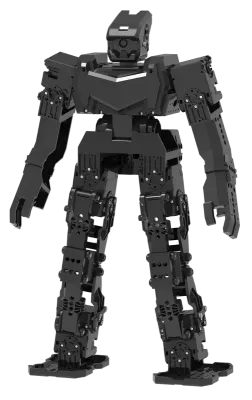 ENGINEER Kit 1$1,139
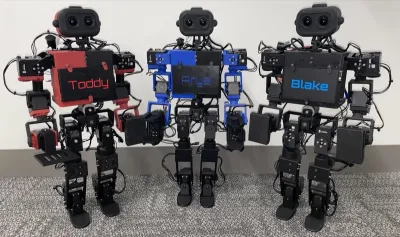 ToddlerBot 2.0~$6,000 DIY · $4,299 built
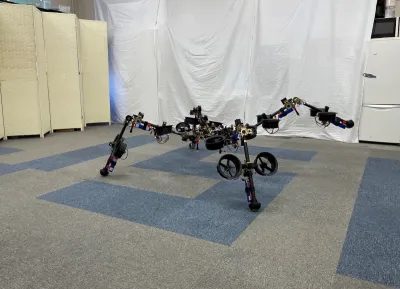 SPIDARNot for sale
Also used in many university arms, pan-tilt heads and mobile robots.
Sources Datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store ↗ · 2XL430 store page ↗ · TurtleBot3 specs (ROBOTIS e-Manual) ↗ · Interbotix arm servo tables (Trossen docs) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier.
DYNAMIXEL XC430-W150-T / XC430-W240-T
ROBOTIS America store, October 2026 check, same price for the W150, W240 and the dual-bearing T240BB. The dual-axis 2XC430-W250-T lists at $298.89. The W150 page warned of an estimated 2-week lead time.
The XC430 sits between the plastic-geared XL430 and the XM430 in ROBOTIS's 430 case. The W150 trades torque for speed, while the W240 is the stronger, slower version. ToddlerBot uses the dual-bearing XC430-T240BB in its shoulders and ankles and the dual-axis 2XC430-W250 in its hips.
- Torque
- W150 reaches 1.4 N·m (14.3 kg·cm) stall at 11.1 V, 1.3 A, and 1.6 N·m at 12 V, 1.4 A. W240 reaches 1.7 N·m (17.3 kg·cm) stall at 11.1 V, 1.3 A, and 1.9 N·m at 12 V, 1.4 A
- Speed
- W150 runs 99 rpm no load at 11.1 V and 106 rpm at 12 V (about 0.09 s/60°). W240 runs 65 rpm at 11.1 V and 70 rpm at 12 V (about 0.14 s/60°)
- Weight
- 65 g
- Size
- 28.5 × 46.5 × 34 mm
- Voltage
- 6.5–14.8 V (12 V recommended)
- Current
- stall 1.4 A at 12 V for both, standby 46 mA
- Gearing
- W150 159.59:1, W240 245.22:1, full metal gears
- Motor
- coreless DC
- Feedback
- contactless 12-bit absolute magnetic encoder (ams), 4096 steps/rev; position, velocity, load, temperature and input voltage readback
- Interface
- TTL half-duplex multidrop bus, 9,600 bps to 4.5 Mbps, DYNAMIXEL Protocol 2.0
- Range
- 0–360° position mode, multi-turn extended position mode, velocity mode
- Other
- No current-control mode. Same case as the XL430 and XM430, so it drops into the same frames.
Upgrading an XL430 design to metal gears and a coreless motor without changing frames, especially fast joints (W150) or moderate-torque joints (W240).
Torque or force-control work, since the XM430 costs about twice as much but adds current control and over twice the torque.
Robots in the guide that use it
Sources XC430-W150 datasheet (ROBOTIS e-Manual) ↗ · XC430-W240 datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store (W150) ↗ · ROBOTIS America store (W240) ↗ · ToddlerBot paper, Table 2 (arXiv) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier. At the October 2026 check the W150 page warned of an estimated 2-week lead time.
DYNAMIXEL XM430-W350-T / -R
ROBOTIS America store, October 2026 check. $310.39 for the TTL (-T) version, $333.39 for RS-485 (-R).
The XM430-W350 is the workhorse of mid-size research robots. All 20 joints of the ROBOTIS OP3 humanoid use the RS-485 version, and Interbotix built most of the WidowX 250 and the ViperX 300 wrist from it, which carried it into the ALOHA teleoperation rigs. Current-based position control lets a gripper squeeze an object without stalling at full power.
- Torque
- 4.1 N·m (41.8 kg·cm) stall at 12 V, 2.3 A; 3.8 N·m at 11.1 V; 4.8 N·m at 14.8 V
- Speed
- 46 rpm no load at 12 V (about 0.22 s/60°); 43 rpm at 11.1 V; 57 rpm at 14.8 V
- Weight
- 82 g
- Size
- 28.5 × 46.5 × 34 mm
- Voltage
- 10–14.8 V (12 V recommended)
- Current
- stall 2.3 A at 12 V, standby 40 mA
- Gearing
- 353.5:1, full metal gears, backlash 15 arcmin (0.25°)
- Motor
- coreless DC
- Feedback
- contactless 12-bit absolute magnetic encoder (ams AS5045), 4096 steps/rev; position, velocity, current, temperature and input voltage readback
- Interface
- -T version TTL half-duplex multidrop bus, -R version RS-485 multidrop bus; 9,600 bps to 4.5 Mbps, DYNAMIXEL Protocol 2.0
- Range
- 0–360° position mode, multi-turn extended position mode, velocity mode
- Other
- Six modes including current control and current-based position control, which allow torque-limited grasping and compliant joints.
Research arms, humanoid legs and grippers that need about 4 N·m, current-based compliance and reliable metal gears in a compact case.
Cost-sensitive builds, since each one costs about eleven XL430s, and joints needing more than about 4 N·m, where the XM540 or XH540 fit better.
Robots in the guide that use it
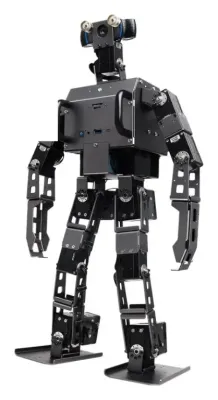 OP3~$12,000 – $13,800Interbotix WidowX 250Was $2,895.95
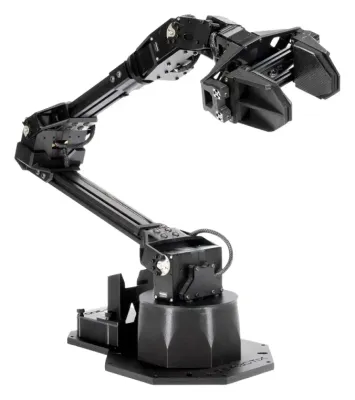 Interbotix ViperX 300 / 300 SWas $6,742.95ALOHA 2 / Trossen AI Stationary$23,995.95Mobile ALOHA~$32,000 (BOM) / $33,696…
Also the servo of all five joints of the OpenMANIPULATOR-X arm. TurtleBot 3 Waffle Pi and ToddlerBot use the faster XM430-W210 sibling instead.
Sources Datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store (-T) ↗ · ROBOTIS America store (-R) ↗ · OP3 specifications (ROBOTIS e-Manual) ↗ · Interbotix arm servo tables (Trossen docs) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier.
DYNAMIXEL XH540-W270-T / -R
ROBOTIS America store, October 2026 check. $620.89 for TTL (-T), $632.39 for RS-485 (-R).
The XH540-W270 is one of the strongest X-series servos, with a Maxon coreless motor in the larger 540 case. It keeps the same bus, protocol and software as the small XL330, so a design can mix tiny and large joints on one SDK. The XM540-W270, used in the ViperX 300 arm, shares the case, is rated slightly higher at 10.6 N·m stall at 12 V and costs less ($482.89 for the TTL version), but ROBOTIS lists a Maxon motor only for the XH line.
- Torque
- 9.9 N·m (101 kg·cm) stall at 12 V, 4.9 A; 9.2 N·m at 11.1 V; 11.7 N·m at 14.8 V
- Speed
- 39 rpm no load at 12 V (about 0.26 s/60°); 36 rpm at 11.1 V; 46 rpm at 14.8 V
- Weight
- 165 g
- Size
- 33.5 × 58.5 × 44 mm
- Voltage
- 10–14.8 V (12 V recommended)
- Current
- stall 4.9 A at 12 V
- Gearing
- 272.5:1, full metal gears, backlash 15 arcmin (0.25°)
- Motor
- coreless DC (Maxon)
- Feedback
- contactless 12-bit absolute magnetic encoder (ams), 4096 steps/rev; position, velocity, current, temperature and input voltage readback
- Interface
- -T version TTL multidrop bus, -R version RS-485 multidrop bus; 9,600 bps to 4.5 Mbps, DYNAMIXEL Protocol 2.0
- Range
- 0–360° position mode, multi-turn extended position mode, velocity mode
- Other
- Six modes including current control. The 540 case is larger than the 430 case, and the XH line uses Maxon motors.
Shoulders and elbows of larger research arms and legs of mid-size humanoids, where about 10 N·m with current control is needed in a bus servo.
Tight budgets or small robots, and highly dynamic legged robots, where quasi-direct-drive brushless actuators are far more backdrivable.
Sources Datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store (-T) ↗ · ROBOTIS America store (-R) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier.
DYNAMIXEL MX-28 (MX-28AT / AR, 2.0 firmware)
ROBOTIS America store, October 2026 check. MX-28T $298.89, MX-28R $310.39, MX-28AT $333.39, MX-28AR $344.89.
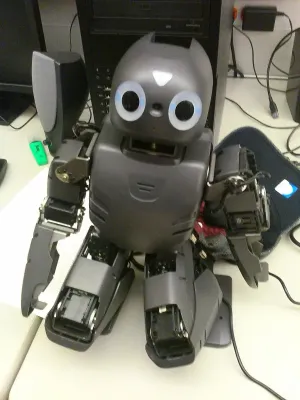
The MX series brought a contactless 360° magnetic encoder and a Maxon coreless motor to Dynamixels at a mid-range price, and the MX-28 was the joint servo of the DARwIn-OP humanoid that won the RoboCup KidSize league from 2011 to 2013. ROBOTIS later released the MX(2.0) firmware, which brings Protocol 2.0 and the X-series control table to the same hardware. It remains in production, mostly for existing robots.
- Torque
- 2.5 N·m (25.5 kg·cm) stall at 12 V, 1.4 A; 2.3 N·m at 11.1 V; 3.1 N·m at 14.8 V
- Speed
- 55 rpm no load at 12 V (about 0.18 s/60°); 50 rpm at 11.1 V; 67 rpm at 14.8 V
- Weight
- 72 g (T/R), 77 g (AT/AR)
- Size
- 35.6 × 50.6 × 35.5 mm
- Voltage
- 10–14.8 V (12 V recommended)
- Current
- stall 1.4 A at 12 V
- Gearing
- 193:1, full metal gears, backlash 20 arcmin (0.33°)
- Motor
- coreless DC (Maxon)
- Feedback
- contactless 12-bit absolute magnetic encoder (ams), 4096 steps/rev; position, velocity, temperature and input voltage readback
- Interface
- T/AT versions TTL multidrop bus, R/AR versions RS-485 multidrop bus; 8,000 bps to 4.5 Mbps. Original MX firmware speaks Protocol 1.0, and MX(2.0) firmware supports both Protocol 1.0 and 2.0 with an X-series-style control table
- Range
- 0–360° position mode, multi-turn extended position mode, velocity mode
- Other
- The A versions have a metal front housing. Radial load 30 N at 10 mm from the horn, axial load 15 N.
Repairing and extending DARwIn-OP, ROBOTIS OP2 and Poppy robots, which were designed around its case and horn.
New designs, since the XM430-W350 offers more torque, current control and a smaller case for less money.
Robots in the guide that use it
Also used in many RoboCup KidSize humanoids of the 2010s and research arms of that era.
Sources Datasheet, MX(2.0) firmware (ROBOTIS e-Manual) ↗ · ROBOTIS America store (MX-28AT) ↗ · Poppy Humanoid motor config (GitHub) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier.
DYNAMIXEL MX-64 (MX-64AT / AR, 2.0 firmware)
ROBOTIS America store, October 2026 check. MX-64AT and MX-64R $425.39, MX-64AR $436.89. The MX-64AT page noted a 2–3 week lead time.
The MX-64 is the larger sibling of the MX-28, giving about 6 N·m at 12 V with a Maxon motor and metal gears. Poppy Humanoid uses four of them in its hips and trunk where the MX-28 runs out of torque. Like the MX-28 it now ships with optional MX(2.0) firmware for Protocol 2.0.
- Torque
- 6.0 N·m (61.2 kg·cm) stall at 12 V, 4.1 A; 5.5 N·m at 11.1 V; 7.3 N·m at 14.8 V
- Speed
- 63 rpm no load at 12 V (about 0.16 s/60°); 58 rpm at 11.1 V; 78 rpm at 14.8 V
- Weight
- 126 g (T/R), 135 g (AT/AR)
- Size
- 40.2 × 61.1 × 41 mm
- Voltage
- 10–14.8 V (12 V recommended)
- Current
- stall 4.1 A at 12 V
- Gearing
- 200:1, full metal gears
- Motor
- coreless DC (Maxon)
- Feedback
- contactless 12-bit absolute magnetic encoder (ams), 4096 steps/rev; position, velocity, current, temperature and input voltage readback
- Interface
- T/AT versions TTL multidrop bus, R/AR versions RS-485 multidrop bus; 8,000 bps to 4.5 Mbps. MX(2.0) firmware supports Protocol 1.0 and 2.0
- Range
- 0–360° position mode, multi-turn extended position mode, velocity mode
- Other
- Has current sensing, so the 2.0 firmware adds current and current-based position modes that the MX-28 lacks.
Repairs and upgrades of 2010s research robots built around the MX case.
New designs, since the XM540 and XH540 give similar or more torque with current control in a current-generation part.
Robots in the guide that use it
Also used in the legs of larger RoboCup humanoids and in older research arms.
Sources Datasheet, MX(2.0) firmware (ROBOTIS e-Manual) ↗ · ROBOTIS America store (MX-64AT) ↗ · Poppy Humanoid motor config (GitHub) ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier. At the October 2026 check the MX-64AT page noted a 2–3 week lead time.
DYNAMIXEL-P PH54-200-S500-R
ROBOTIS America store, October 2026 check. The lower-power PH54-100-S500-R lists at $3,288.89. The store warns that DYNAMIXEL-P models may have up to a 6-month lead time.
DYNAMIXEL-P is ROBOTIS's professional line, with Maxon brushless motors, planetary gearboxes and 24 V RS-485 networking. The PH54-200 is the flagship, rated 200 W and about 45 N·m continuous, at roughly the price of a full hobby robot per joint. It shares Protocol 2.0 and the DYNAMIXEL SDK with the small X-series servos.
- Torque
- 44.7 N·m continuous (no stall figure published, ROBOTIS gives a performance curve instead)
- Speed
- 33.1 rpm no load, 29.0 rpm at continuous torque, at 24 V
- Weight
- 855 g
- Size
- 54 × 126 × 54 mm
- Voltage
- 24 V nominal
- Current
- 9.3 A continuous, 1.65 A no load
- Gearing
- 501.9:1 integrated planetary gearbox, backlash under 6 arcmin (0.1°)
- Motor
- BLDC (Maxon), 200 W
- Feedback
- output resolution 1,003,846 pulses/rev; position, velocity, current and temperature readback
- Interface
- RS-485 multidrop bus, 9,600 bps to 10.5 Mbps, DYNAMIXEL Protocol 2.0 (Modbus-RTU also supported)
- Other
- Industrial-grade line that grew out of the older DYNAMIXEL PRO series. Family includes PH54-100, PH42-020 and the PM54 and PM42 models.
Collaborative-style arms and large animatronic figures that need tens of N·m with very fine position resolution on the familiar Dynamixel bus.
Hobby or student budgets, and dynamic legged robots, since the high gear ratio makes it slow and hard to backdrive.
Also the two base joints of ROBOTIS's OpenMANIPULATOR-P arm, which uses the PH54-100 and PH42-020 further out, and research manipulators. Realbotix's Melody humanoid is described only as using DYNAMIXEL-P servos, with no model named.
Sources Datasheet (ROBOTIS e-Manual) ↗ · ROBOTIS America store ↗
Buying ROBOTIS America (robotis.us) ships from its Corona, California warehouse by FedEx, UPS or USPS, normally within 2 business days of the order; delivery time depends on the carrier. The store warns that DYNAMIXEL-P models may take up to 6 months, so buyers should ask [email protected] about stock first.