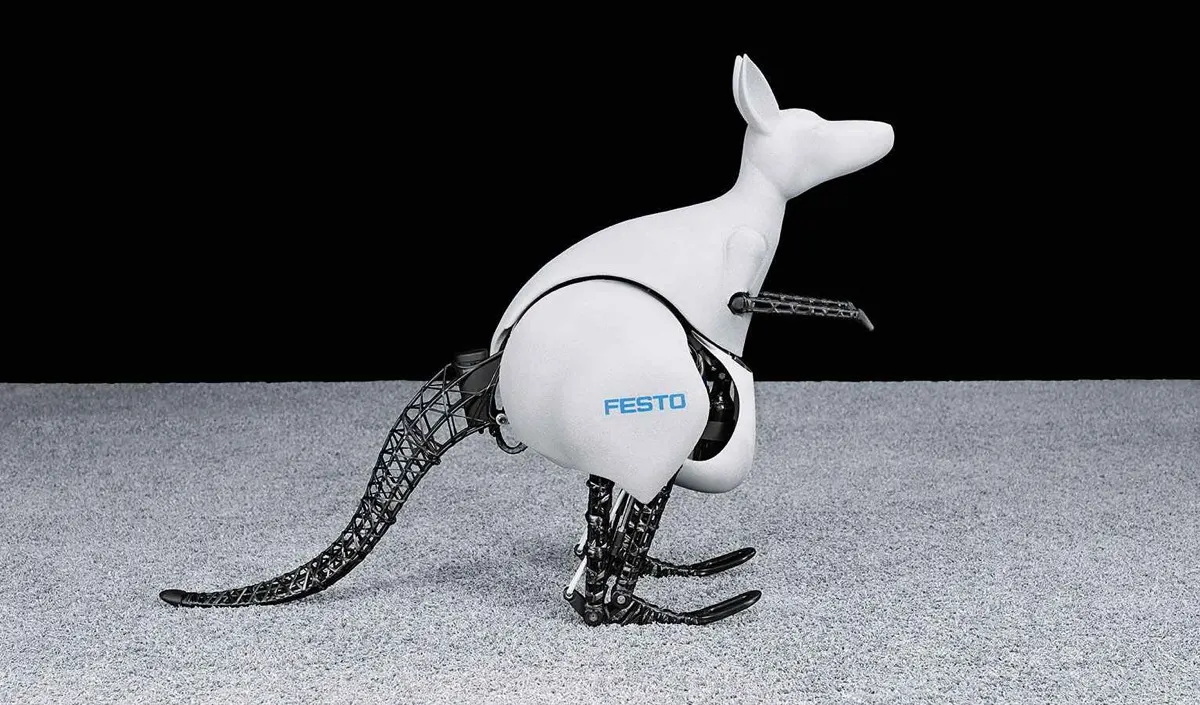
Not soldTechnology demonstrator from Festo's Bionic Learning Network; shown at Hannover Messe 2014.
Not for sale (research)Not programmableBionic demoEnergy recoveryGesture controlPneumatic
Not soldShipping: N/A. Not available; a Festo research and trade-fair demonstrator.
Remote control: Not possible. A Festo exhibition piece controlled only by its gesture armband.
Overview
Festo spent two years recreating the kangaroo's elastic hop. An elastic tendon is pretensioned pneumatically, released for take-off and recharged by the landing, so successive jumps reuse stored energy. The tail servo counters the leg swing to keep the body level in flight. Like most Festo bionic projects it was built to showcase pneumatics and control rather than for sale, and it toured trade fairs from 2014.
Specifications
| Category | Jumpers & hoppers · Jumping & hopping robots |
|---|---|
| Released | 2014 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Mixed |
| Audio | No audio |
| Compute type | Proprietary / undisclosed |
| Remote control | Not programmable |
| Size | 100 cm upright (60 cm sitting), 7 kg |
| Locomotion | Two hind legs driven by Festo DSNUP-20 pneumatic cylinders with a rubber 'Achilles tendon' that stores landing energy; electric servos (3 Harmonic Drive motors) for hips and balancing tail |
| Compute | Festo CECC compact controller (Ethernet, CAN, RS232/485, IO-Link) |
| Camera | None |
| Sensors | Xsens AHRS, Festo SPTE pressure transmitter, Hall rotary potentiometer |
| Runtime | Not published; on-board compressor or high-pressure air tank plus LiPo batteries |
| Speed | Jumps up to 40 cm high and 80 cm long |
| SDK | None; controlled by gestures through a Thalmic Labs Myo EMG armband over Bluetooth (50 m range) |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 Parrot Jumping Sumo (and Jumping Race / Night)Parrot (France)Was $159.99 (2014)
 SALTO / SALTO-1PUC Berkeley Biomimetic Millisystems Lab (USA)Not sold
 Sand FleaBoston Dynamics (USA)Not sold
 UCSB 30-Meter JumperUC Santa Barbara Hawkes Lab with Disney Research and Caltech (USA)Not sold
 SpaceHopperETH Zurich Robotic Systems Lab student focus project (Switzerland)Not sold
 Disney Research One-Legged Hopper (LEAP)Disney Research (USA)Not sold
Image credits
- Image 1: source (Festo press image)