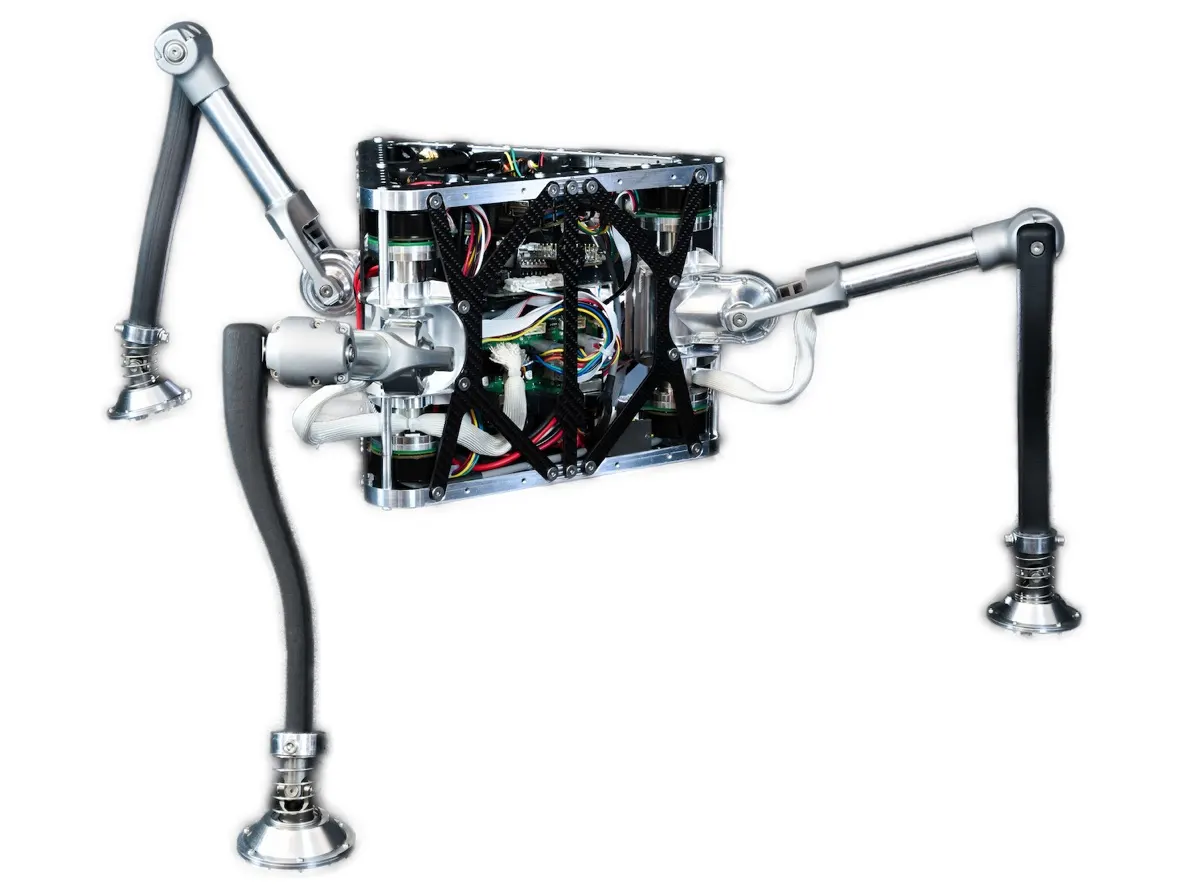
Not soldStudent research robot supported by ESA Education.
Not for sale (research)Not programmableResearchLow gravityThree legsRL control
Not soldShipping: N/A. Not available; a university research robot.
Remote control: Not possible. A lab prototype not distributed outside ETH Zurich.
Overview
A three-legged hopper designed for asteroids and small moons, where wheels lose traction and each jump can carry a robot far. Instead of reaction wheels it uses learned leg motions to twist its body mid-flight and land feet-first, demonstrated on a gimbal (within 9.7°) and on a counterweight rig in Earth gravity. Built by a ten-student ETH team from 2022–2023 and published at ICRA 2024, with parabolic-flight testing planned as the next step.
Specifications
| Category | Jumpers & hoppers · Jumping & hopping robots |
|---|---|
| Released | 2023 |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | NVIDIA Jetson, Arduino / ESP32 / microcontroller |
| Remote control | Not programmable |
| Size | 245 mm body, 5.2 kg; three legs of 1.17 kg each |
| Locomotion | Three symmetric legs with 3 DoF each (9 motors over EtherCAT); hops in low gravity and swings its legs to reorient in flight without flywheels |
| Compute | NVIDIA Jetson Nano plus STM32 safety microcontroller |
| Camera | None (camera proposed for future visual-inertial odometry) |
| Sensors | Three laser range finders, joint encoders, battery management and temperature sensing |
| Runtime | Not published (7S Li-ion pack) |
| Speed | In simulated Ceres gravity (0.029 g), jumps to commanded targets up to 6 m away |
| SDK | None public; deep-RL (PPO) policies trained in Isaac Gym |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 Parrot Jumping Sumo (and Jumping Race / Night)Parrot (France)Was $159.99 (2014)
 SALTO / SALTO-1PUC Berkeley Biomimetic Millisystems Lab (USA)Not sold
 Sand FleaBoston Dynamics (USA)Not sold
 BionicKangarooFesto Bionic Learning Network (Germany)Not sold
 UCSB 30-Meter JumperUC Santa Barbara Hawkes Lab with Disney Research and Caltech (USA)Not sold
 Disney Research One-Legged Hopper (LEAP)Disney Research (USA)Not sold
Image credits
- Image 1: source (project image)