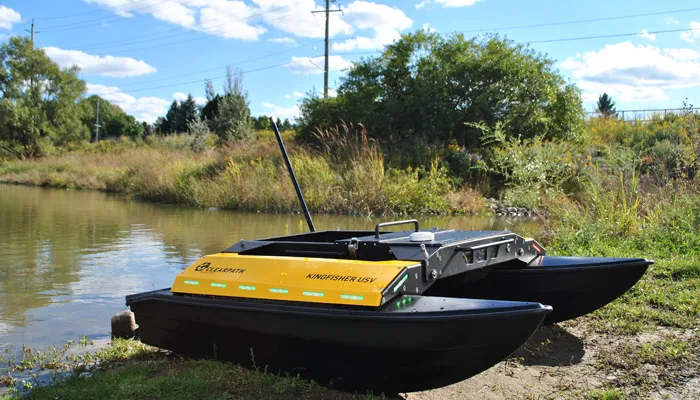
Was quote-onlySold on a get-a-quote basis. Price never published. The M100 was on sale by 2011 (unconfirmed) and the redesigned M200 was announced in November 2012.
Discontinued · unavailableVia SSH / web / bridgeROSCatamaranWater-jet driveDiscontinued
UnavailableShipping: Discontinued. No longer sold. Used units occasionally move between university labs.
Remote control: Join the boat's Wi-Fi network and run ROS on a laptop to send velocity commands and read GPS, IMU and camera topics.
Overview
Clearpath's first research boat, a small catamaran built for university autonomy work and shallow-water surveys. The M100 was followed by the M200 in late 2012, which added semi-planing hulls and jet thrusters. It shipped ready for teleoperation with ROS drivers, and around 2016 Clearpath replaced it with the Heron USV, which uses the same 1.35 m hull dimensions and specs. It is the water sibling of the Husky and Jackal ground robots.
Specifications
| Category | Swimming robots · Surface & autonomous boats |
|---|---|
| Released | 2011 |
| Country | Canada |
| Availability | Discontinued · unavailable |
| Programmability | Open source (hardware + software) |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Unknown |
| Audio | No audio |
| Compute type | x86 PC (Intel / AMD) |
| Remote control | Via SSH / web / bridge |
| Size | 1.35 × 0.98 × 0.32 m deployed (0.56 m wide stored), 28 kg |
| Propulsion | Catamaran with semi-planing hulls and two enclosed electric water-jet thrusters (40 N thrust) |
| Depth rating | Surface only (120 mm draught) |
| Tether / comms | None, Wi-Fi radio link |
| Camera | Front hazard camera |
| Sensors | GPS, IMU, compass, 10 kg payload for options such as sonar, ADCP, lidar and water-quality sensors |
| Runtime | 2.5 h (14.4 V 29 Ah NiMH pack, 8 h recharge) |
| Speed | 1.7 m/s (3.3 kn) |
| Compute | Onboard Intel Atom PC running Ubuntu and ROS |
| SDK | ROS drivers (cmd_vel, GPS and IMU topics), C++, MOOS-IvP |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 BlueBoat
 Saildrone Explorer
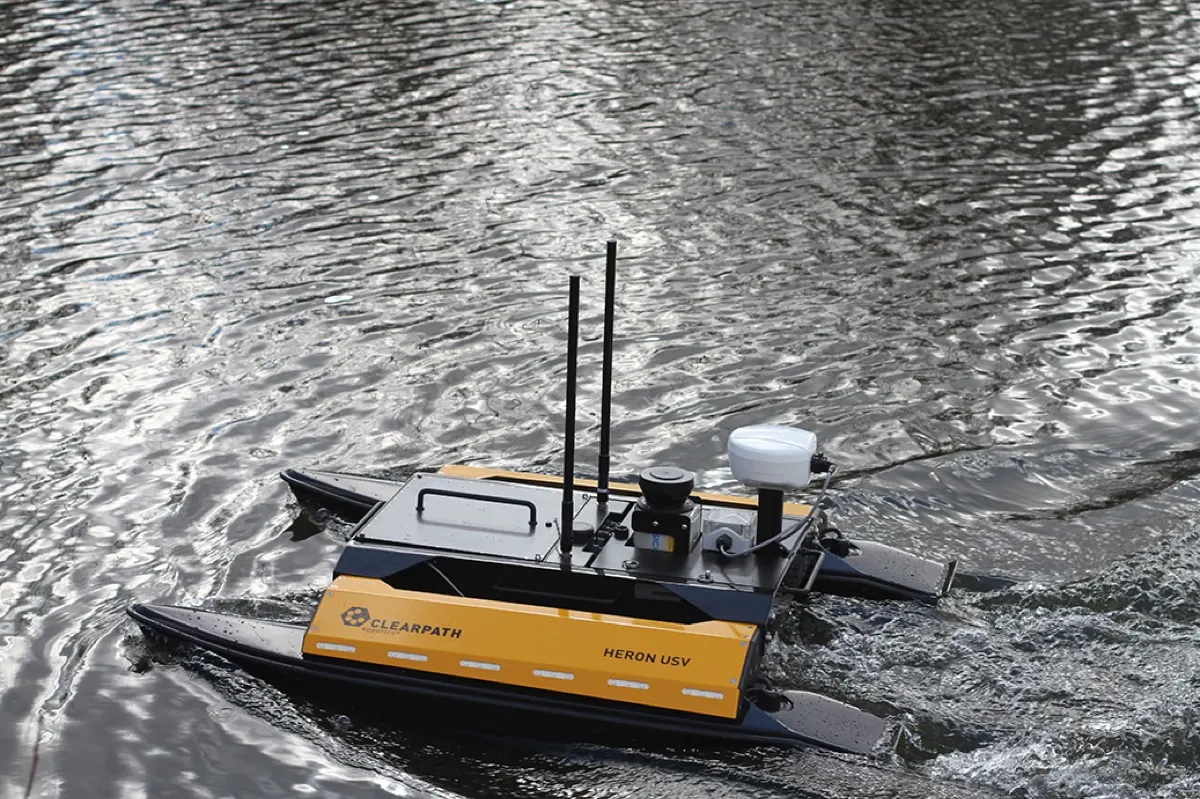 Heron USV
 Otter
 SL20
 HYCAT
Image credits
- Image 1: source (Kingfisher USV photo, rights with Clearpath Robotics)