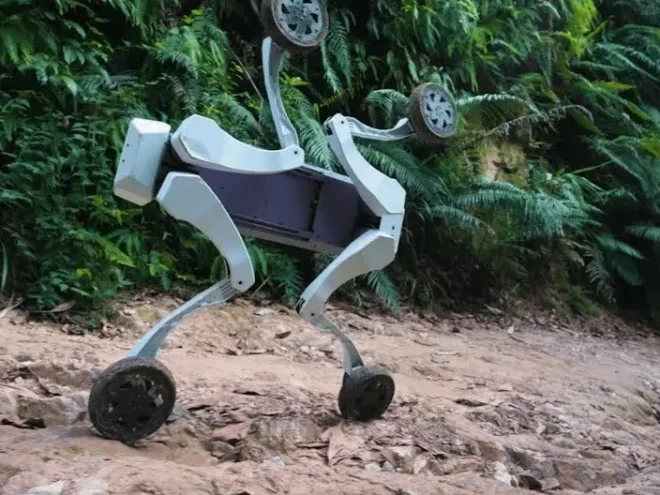
Overview
A wheeled-legged quadruped from a Shenzhen startup founded in 2025, shown in October 2025 as the first wheeled quadruped built on parallel-joint drive modules, which the maker says deliver 40% more force per unit of actuator effort than a conventional serial leg while keeping the body light. The launch video shows it climbing a 1 m wall, holding a 45° slope, descending stairs and rubble, balancing on two legs and dropping 1.2 m onto two feet. The maker quotes a 38 kg body, a 40 kg rated payload, 5 m/s on wheels and about 5 hours or 35 km per charge, with IP65 sealing and a -20 to 55°C operating range (unconfirmed). Pitched at outdoor inspection, emergency response and material transport over rough ground, the same dull, dirty and dangerous jobs targeted by DEEP Robotics LYNX M20 and Unitree B2-W, at a weight close to the LYNX and far above Unitree Go2-W.
No price, reseller or delivery has been found a year after the reveal, and the maker's website was unreachable from the US in October 2026, so the M1 is listed as announced rather than available. The company's co-founder and CEO, a CUHK robotics PhD and former DJI engineer, has since been reported leading a separate wheeled-legged startup, Lumisition Robotics, which adds uncertainty about the M1's path to market (unconfirmed). Buyers who need a wheeled-legged industrial robot today will find the LYNX M20 and B2-W easier to buy and better documented.
Specifications
| Category | Quadrupeds · Industrial |
|---|---|
| Released | 2025 |
| Country | China |
| Availability | Announced only |
| Programmability | Limited SDK |
| Built-in autonomy | Navigates · Goes to places on its own, such as mapped rooms, waypoints or its charging dock |
| LLM support | Possible via SDK · No built-in LLM. The maker's site says the M1 supports secondary development, so an LLM running on a computer could control it through whatever interface the maker provides, but no SDK documentation has been published (unconfirmed). Lightyear Robotics M1 page ↗ |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · Nothing found. No URDF or robot description has been published. |
| Best for | Professionals & labs |
| Vision sensors | Lidar, Camera |
| Actuators | Brushless / direct-drive motors |
| Audio | Unknown |
| Compute type | Proprietary / undisclosed |
| Compute | Not published |
| Weight | 38 kg, 40 kg rated payload (150 kg maximum, unconfirmed), about 5 hours and 35 km per charge unloaded (maker's site), with 3–4.5 hours and 15–30 km also quoted (unconfirmed) |
| Speed | 5 m/s (18 km/h) on wheels per the maker's site, 21.6 km/h in press coverage (unconfirmed) |
| DOF | Not published (four parallel-joint leg modules plus four wheel motors) |
| Sensors | Perception suite for autonomous mapping, omnidirectional obstacle avoidance and semantic navigation, sensor list not published, lidar and cameras (unconfirmed) |
| SDK | Secondary development supported per the maker's site, no SDK details or ROS support published (unconfirmed) |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 A2
 B2
 Jueying X20
 Spot
 ANYmal D
 Vision 60
Image credits
- Image 1: source (official launch video frame, cropped to remove a caption and logo)