Overview
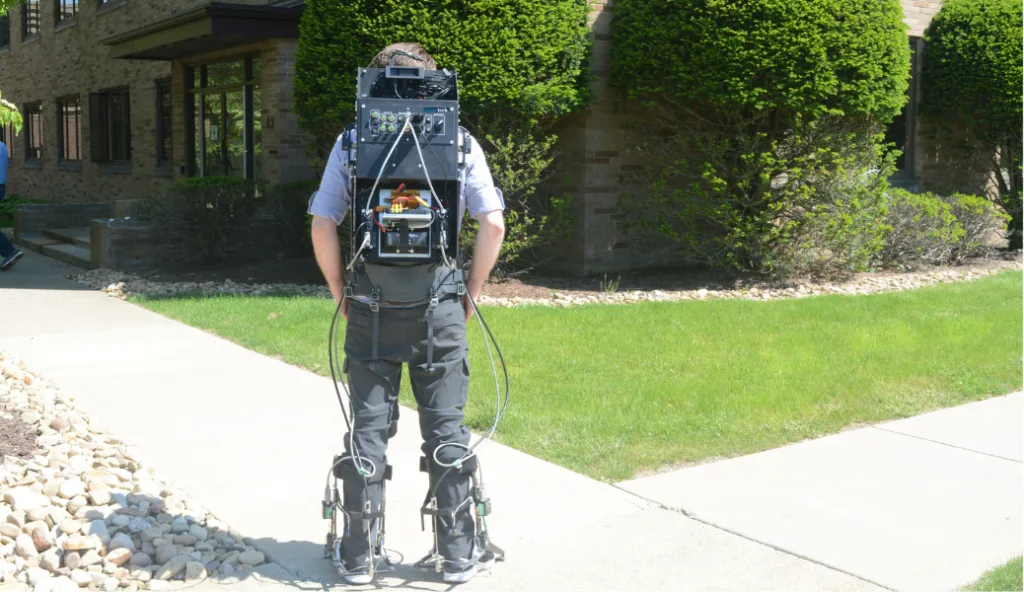
Caplex is Humotech's exoskeleton and prosthesis emulator, a lab system that grew out of Steve Collins' tethered emulator research at Carnegie Mellon and Stanford and was turned into a product by the Pittsburgh startup from about 2016. Powerful off-board motors and a real-time controller drive cables to interchangeable wearable end-effectors, including the EXO-001 ankle (adult and child sizes, up to 180 Nm), the EXO-004 hip (50 Nm) and the lighter EXO-005 ankle, so a researcher can try many device behaviors on one wearer without building new hardware. The Portable Caplex backpack (BCK-001, August 2021, about 9 to 13 kg) takes the system outside the lab, and Humotech also works on clinical use such as orthotic prescription studies. It is tethered and heavy, so it is a research tool rather than a wearable product, and it is sold only by quote to labs. The untethered Stanford exoskeleton boot was designed from years of Caplex-style emulator data.
Specifications
| Category | Exoskeletons & exosuits · Full-body, military & research |
|---|---|
| Released | 2016 |
| Country | USA |
| Availability | Available |
| Programmability | Full SDK |
| Built-in autonomy | Reactive · Responds to its surroundings without a map, such as avoiding obstacles or following a person |
| LLM support | None · No voice assistant or LLM. |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | x86 PC (Intel / AMD) |
| Control | SDK or research mode |
| Weight | 1.4 kg (EXO-001 ankle, with shoe), 3.7 kg (EXO-004 hip), 9 to 13 kg Portable Caplex backpack |
| Assistance | Off-board motors drive Bowden cables to lightweight end-effectors, giving up to 180 Nm of ankle plantarflexion on the EXO-001 and 50 Nm of two-way hip flexion and extension on the EXO-004, so researchers can emulate almost any exoskeleton or prosthesis behavior on one person. |
| Joints | Ankles or hips (interchangeable) |
| Battery & runtime | Wall-powered off-board actuator units for the lab systems; the Portable Caplex runs on AC wall power or a DC battery. |
| Operation | Researchers write controllers in MATLAB and Simulink using Humotech's block library and run them on a Speedgoat real-time target, with a Humotech GUI on a Windows host PC. |
| Sensors | Inline load cell on each cable (within 1%), 5,000-count optical encoders for joint angle, plus lab I/O for EMG, foot switches and motion capture. |
| Compute | Speedgoat real-time target running Simulink Real-Time, Windows host PC |
| SDK | Caplex software and Simulink library for custom control laws, EtherCAT actuator interface |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 Sarcos Guardian XOSarcos Robotics, now Palladyne AI (USA)$100,000 per year (rental)
 Lockheed Martin ONYXLockheed Martin (USA)Not sold
 NASA X1 exoskeletonNASA Johnson Space Center with IHMC (USA)Not sold
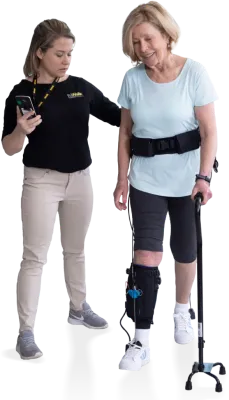 Harvard Soft Exosuit (and ReStore)Harvard Wyss Institute and Lifeward (USA)Quote only
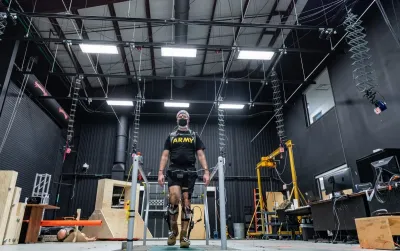 Dephy ExoBootDephy (USA)Was quote only
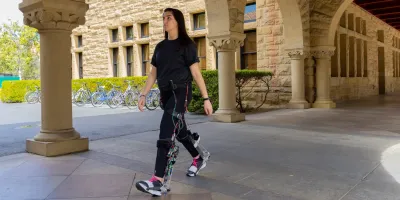 Stanford Exoskeleton BootStanford Biomechatronics Lab (USA)Not sold
Image credits
- Image 1: source (official product image, Portable Caplex)