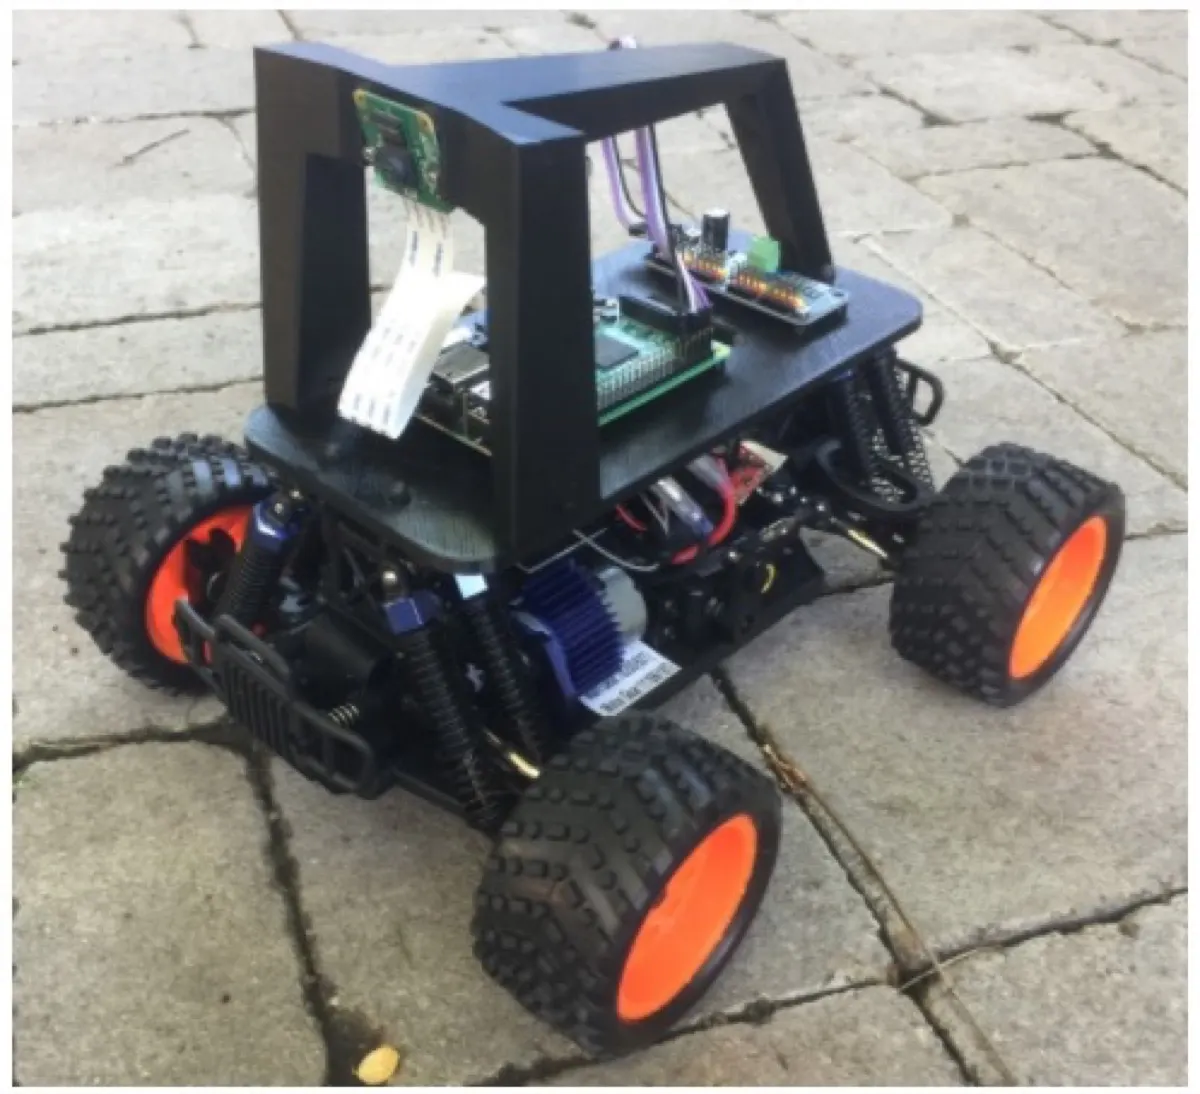
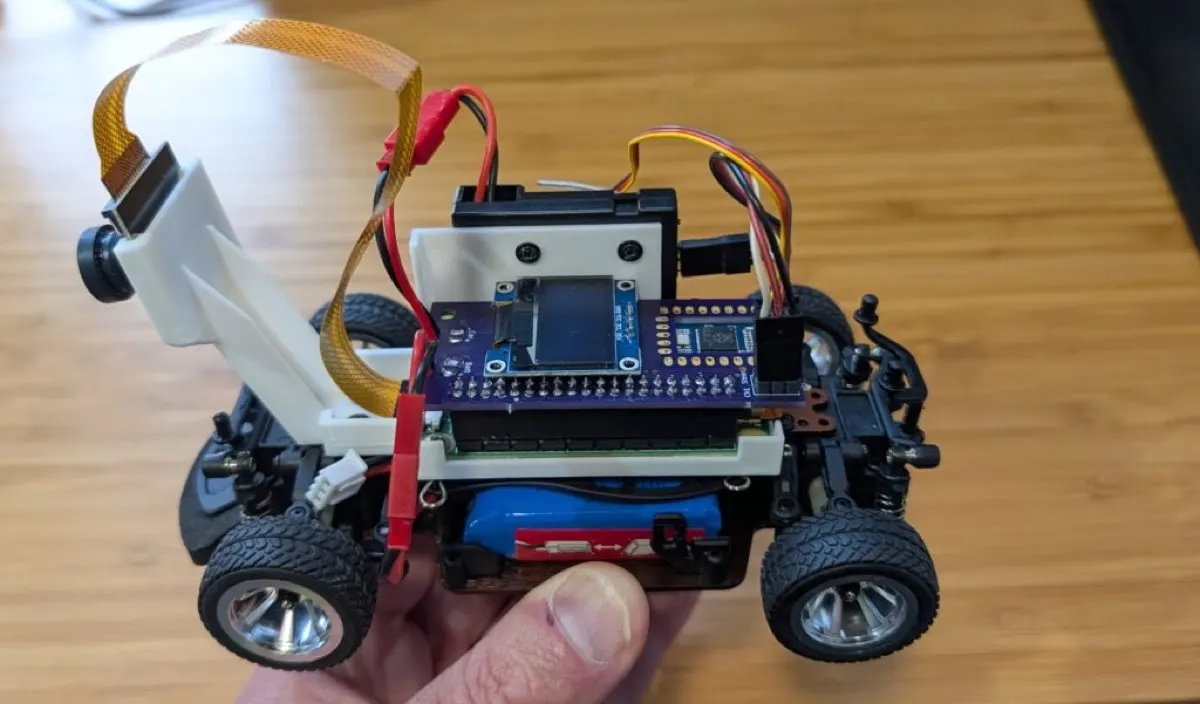
~$250–$500 (DIY, est.)Build cost for an RC chassis, Pi or Jetson, camera and parts; pre-made kits vary.
AvailableVia SSH / web / bridgeRC carBehavior cloningOpen sourceRacing
Possibly ≤ 1 weekShipping: Days. Built from standard RC and Pi parts, most available from Amazon with Prime shipping.
Remote control: Data is recorded on the car, copied to a laptop over SSH/rsync for training, and the model is pushed back; the car is driven from a browser-based web controller.
Overview
The best-known open-source DIY self-driving RC car. It is driven around a track while recording images and steering, a neural network is trained on a laptop, and then it drives itself. Home of the DIY Robocars racing community. Not a house robot, but an excellent introduction to end-to-end learning.
Specifications
| Category | Wheeled rovers · Ready-made dev rovers |
|---|---|
| Released | 2017 |
| Availability | Available |
| Programmability | Open source (hardware + software) |
| Best for | Ages 14+ (estimated) |
| Vision sensors | Camera, Lidar |
| Actuators | Mixed |
| Audio | No audio |
| Compute type | Raspberry Pi, NVIDIA Jetson |
| Remote control | Via SSH / web / bridge |
| Size | 1/16 or 1/10-scale RC car, ~1–2 kg (est.) |
| Drive | Ackermann steering (RC car chassis) |
| Compute | Raspberry Pi 4/5 or NVIDIA Jetson Nano/Orin |
| Vision | Wide-angle Pi camera |
| Lidar | Optional (RPLIDAR supported) |
| Sensors | Optional IMU, encoders, GPS |
| Runtime | ~30–60 min (est., battery dependent) |
| Speed | Several m/s (chassis dependent) |
| SDK | Python donkeycar library (Keras/PyTorch), web controller, simulator |
Ratings & reviews
Ratings and reviews load on the live site.
 MARS (Builders Edition)
 UGV Rover (PT / ROS 2 kit)
 UGV Beast (tracked)
 TurtleBot 4 / 4 Lite
 MentorPi M1
 ROSMASTER X3