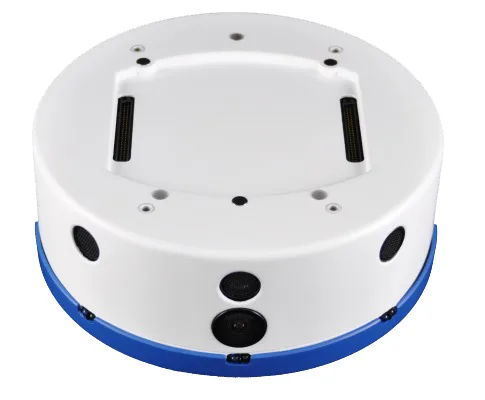
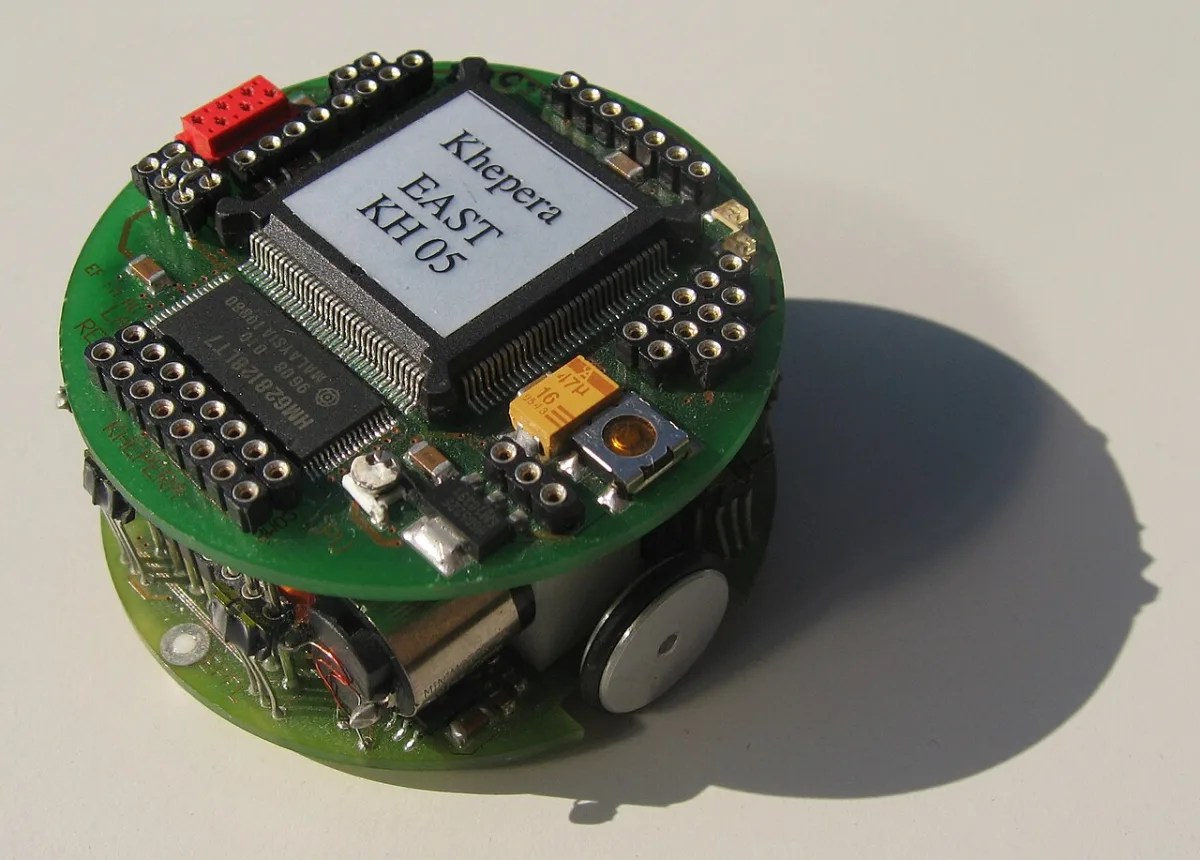
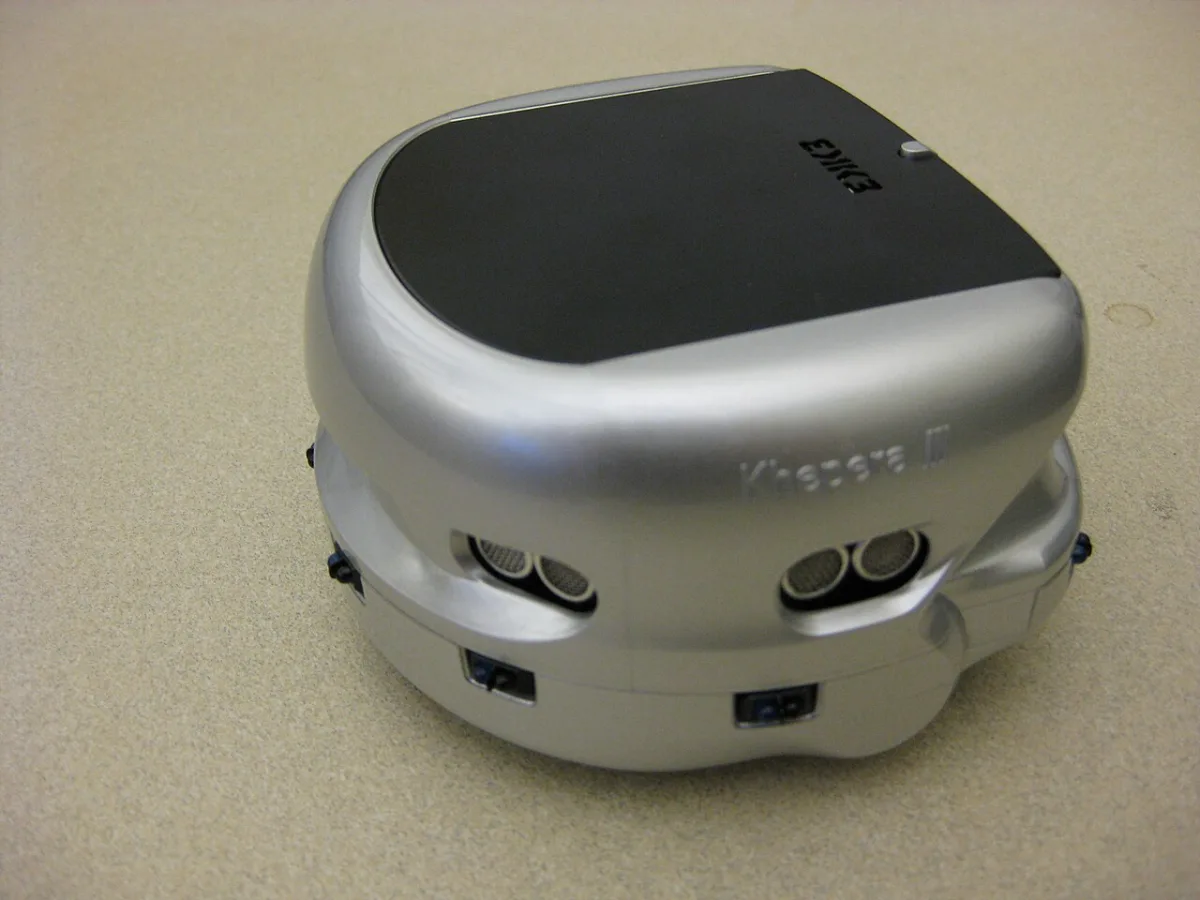
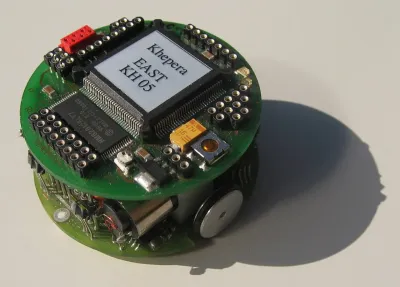
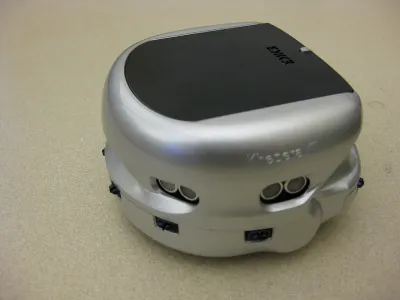
$3,260Last listed by K-Team at 2,700 CHF for the Khepera IV (excluding taxes and shipping), about $3,260 converted, on its product page archived in January 2024. October 2026 check found K-Team's website down (returning errors since January 2025) and the Generation Robots listing (€3,240) removed. Year 1991 is the first EPFL prototype; Khepera II came in 1998, Khepera III in 2005 and Khepera IV in 2014.
Out of stockVia SSH / web / bridgeLinux onboardResearch classicSince 1991
Weeks+Shipping: Unconfirmed. K-Team in Switzerland sold it directly and through distributors. Its website has been offline since early 2025 and the main European reseller has dropped the Khepera IV, so current availability is unconfirmed. Used units sometimes come from university labs.
Remote control: Programs are cross-compiled on a Linux PC (K-Team documents a VirtualBox setup for Windows) and run on the robot over SSH via Wi-Fi or USB. A Mac would need a Linux VM for the tool chain (unconfirmed).
Overview
The robot that defined small-scale mobile robotics research in the 1990s. The original 5.5 cm Khepera, built at EPFL's Microcomputing Lab and sold by spin-off K-Team, was used widely in evolutionary robotics and neural-network experiments. Each generation grew, and the 14 cm Khepera IV is hand-sized rather than palm-sized, with embedded Linux, a camera and a 7-hour battery. Its catch is a price above $3,000 and uncertain supply since K-Team's website went offline.
Specifications
| Category | Wheeled rovers · Research mobile manipulators & platforms |
|---|---|
| Released | 1991 |
| Country | Switzerland |
| Availability | Out of stock |
| Programmability | Full SDK |
| Built-in autonomy | Reactive · Responds to its surroundings without a map, such as avoiding obstacles or following a person |
| LLM support | Possible via SDK · No LLM features. It runs embedded Linux with C/C++ and Python 2.7, so an LLM could only be added through custom networked code. |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | Community model · UNED Robotic Park Lab's ROS 2 package includes a Gazebo Classic 11 simulation of the Khepera IV. Webots has an official Khepera IV model, which is not counted here. Robotic-Park-Lab/uned_kheperaIV_ros_pkg ↗ |
| Best for | Professionals & labs |
| Vision sensors | Camera, Sonar / ultrasonic |
| Actuators | DC / gear motors |
| Audio | Speaker, Microphone |
| Compute type | Other ARM chip, Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| Size | Original Khepera about 5.5 cm across; Khepera IV 140 mm diameter, 58 mm tall, 540 g |
| Drive | Two DC motors with encoders and gearboxes, differential drive (Khepera IV) |
| Compute | Khepera IV runs embedded Linux on an 800 MHz ARM Cortex-A8 (Gumstix Overo) with 256 MB RAM, plus a microcontroller for peripherals |
| Vision | Color camera, 752×480 at 30 fps (Khepera IV) |
| Lidar | None |
| Sensors | 8 infrared proximity/ambient light sensors, 4 infrared ground sensors, 5 ultrasonic sensors (25 cm to 2 m), 3-axis accelerometer and gyroscope, microphone, speaker, Wi-Fi, Bluetooth (Khepera IV) |
| Runtime | About 7 hours (7.4 V 3,400 mAh LiPo, Khepera IV) |
| Speed | Up to 1 m/s open loop, 0.8 m/s with the default speed controller (Khepera IV) |
| SDK | GNU C/C++ cross compiler with the libkhepera library, Python 2.7 on board, KB-250 extension bus for add-on turrets, Webots model, community ROS 2 packages |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
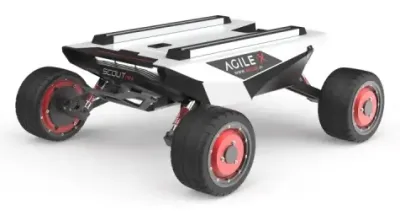 AgileX Scout MiniAgileX Robotics (China)$5,895.95 (Trossen)
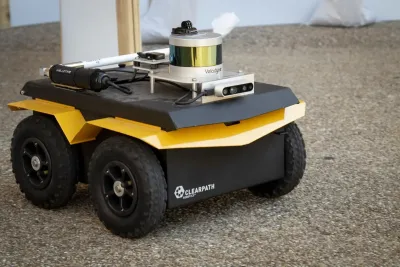 Clearpath JackalClearpath Robotics (Canada, part of Rockwell Automation)Quote (~$20,000+, est.)
 Clearpath Husky (A200 / A300)Clearpath Robotics (Canada, part of Rockwell Automation)Quote (~$30,000+, est.)
 PR2Willow Garage (USA)Was $400,000
 Hello Robot Stretch (RE1 / 2 / 3 / 4)Hello Robot (USA)$24,950 (Stretch 3) / $29,950 (Stretch 4)
 Fetch Mobile ManipulatorFetch Robotics (USA, later Zebra Technologies)Was about $100,000