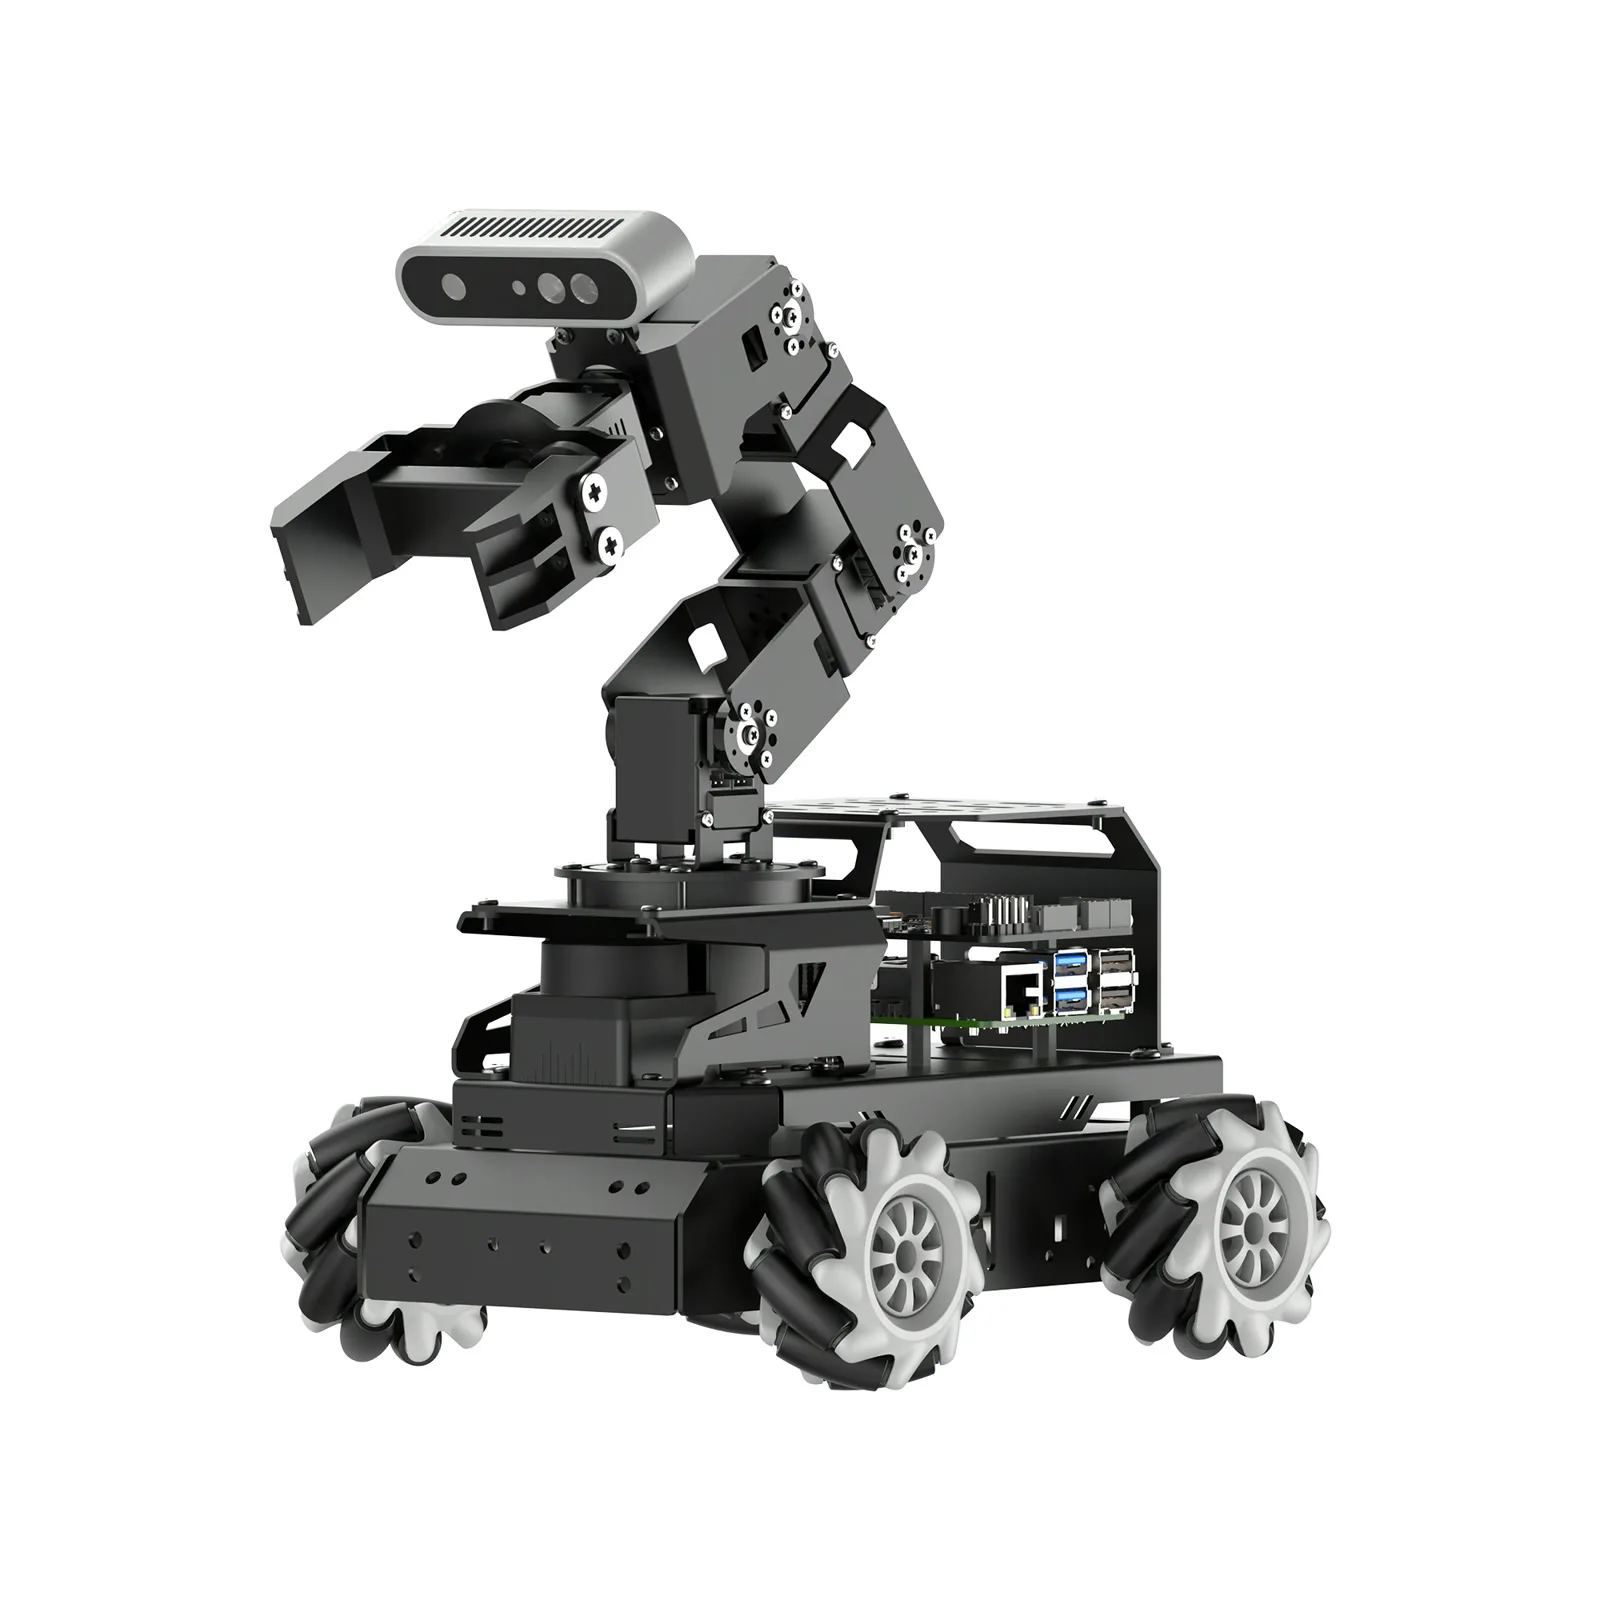
$429.99 – $1,039.99Hiwonder store, October 2026. Three kits, each with Mecanum, Ackermann or Tank chassis (Tank costs $30 more) and with no Pi or a Raspberry Pi 5 2, 4, 8 or 16 GB. Starter (monocular camera and lidar) $429.99 without a Pi to $869.99. Standard (depth camera and lidar) $569.99 without a Pi, $699.99 with a Pi 5 2 GB, up to $1,009.99. Advanced (adds the WonderEcho Pro voice box and the large AI model features) $599.99 to $1,039.99. The cheapest version with a depth camera is the Standard kit without a Pi at $569.99 (Mecanum or Ackermann), or $699.99 with a Pi 5 2 GB. A microSD card is not included in kits without a Pi 5. Amazon US lists Mecanum Starter and Advanced versions, with the Advanced kit and Pi 5 8 GB at $919.99.
AvailableVia SSH / web / bridgeROS 2LidarDepth cameraPi 5ArmMecanum wheels
Possibly ≤ 1 weekShipping: ~1–2 wks (est.), a few days on Amazon. Hiwonder's store says orders are processed within about 24 hours and shipped the next business day, with free shipping over $499. Hiwonder is based in China and the ship-from location for US orders is unconfirmed. The Amazon US listing for the Mecanum Advanced kit is sold by Hiwonder-US and ships from Amazon, quoting delivery in 2–5 days in October 2026. Hiwonder ↗
Remote control: Raspberry Pi OS on the Pi 5, with Ubuntu 22.04 and ROS 2 Humble inside Docker. Hiwonder's guides use VNC for remote access and a supplied Ubuntu virtual machine on the PC for RViz and Gazebo.
Overview
A Raspberry Pi 5 ROS 2 rover with a 6DOF arm, offered on Mecanum, Ackermann or Tank chassis, which suits learners who want mapping, navigation and grasping on one robot. The depth camera rides on the end of the arm, so it can look down to grab objects or forward for RTAB-Map 3D mapping, fall prevention and point-cloud tracking, and the Starter kit has only a monocular camera. Lidar SLAM and Nav2 lessons come with every kit, while voice and large model features need the Advanced kit and an online API key. Runtime is about an hour on a small 2,200 mAh battery, the Ackermann version lacks some depth demos, and speed is not published.
Specifications
| Category | Wheeled rovers · Ready-made dev rovers |
|---|---|
| Released | 2025 |
| Country | China |
| Availability | Available |
| Programmability | Full SDK |
| Built-in autonomy | Navigates · Goes to places on its own, such as mapped rooms, waypoints or its charging dock |
| LLM support | Official LLM tools · The Advanced kit adds the WonderEcho Pro voice box and Hiwonder's large AI model course, which uses OpenAI or OpenRouter API keys for voice control, vision language model tracking and function calling that drives navigation, lidar and the depth camera. Hiwonder's kit comparison says the large model features work only on the Advanced kit. Hiwonder LanderPi docs, Large AI Model Course ↗ |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | Official model · Hiwonder's course includes a LanderPi URDF, MoveIt2 arm simulation and Gazebo hardware and mapping simulation with Nav2. Hiwonder LanderPi docs, MoveIt & Gazebo Simulation ↗ |
| Best for | Ages 14+ (estimated) |
| Vision sensors | Lidar, Depth camera, Camera |
| Actuators | Mixed |
| Audio | Speaker, Microphone |
| Compute type | Raspberry Pi, Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| Size | 212×174×441 mm and 1.79 kg (Mecanum), 213×160×448 mm and 1.73 kg (Ackermann), 278×195×458 mm and 2.18 kg (Tank), with the arm |
| Drive | Mecanum (4 mecanum wheels), Ackermann (steering servo) or Tank (tracks) chassis. 310 metal geared DC motors on Mecanum and Ackermann, MC520 on Tank, all with AB-phase quadrature encoders. 6DOF arm with HX-06L bus servos (410 mm reach, 100 g payload) |
| Compute | Raspberry Pi 5 (2, 4, 8 or 16 GB, or bring a board), plus Hiwonder's RRC Lite STM32 controller |
| Vision | Starter kit has a monocular camera. Standard and Advanced have an Aurora930 Pro depth camera on the end of the arm, 640×400 at 12 fps, 0.15–3 m |
| Lidar | Oradar MS200 360° ToF lidar, 0.1–13.4 m (Hiwonder docs), on every kit |
| Sensors | IMU (named in the docs' calibration files), motor encoders, WonderEcho Pro voice box with microphone and speaker (Advanced only) |
| Runtime | About 60 min (7.4 V 2,200 mAh LiPo) |
| Speed | Not published |
| SDK | ROS 2 Humble, Python, C/C++, slam_toolbox mapping, Nav2 single and multi-point navigation, RTAB-Map 3D mapping and navigation with the depth camera, YOLO26 and YOLOv8 training, OpenCV, MediaPipe, MoveIt2, depth-based fall prevention, point-cloud object tracking and 3D grasping, multi-robot group control, phone app |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 MARS (Builders Edition)
 UGV Rover (PT / ROS 2 kit)
 UGV Beast (tracked)
 TurtleBot 4 / 4 Lite
 MentorPi M1
 ROSMASTER X3
Image credits
- Image 1: source (official product image)