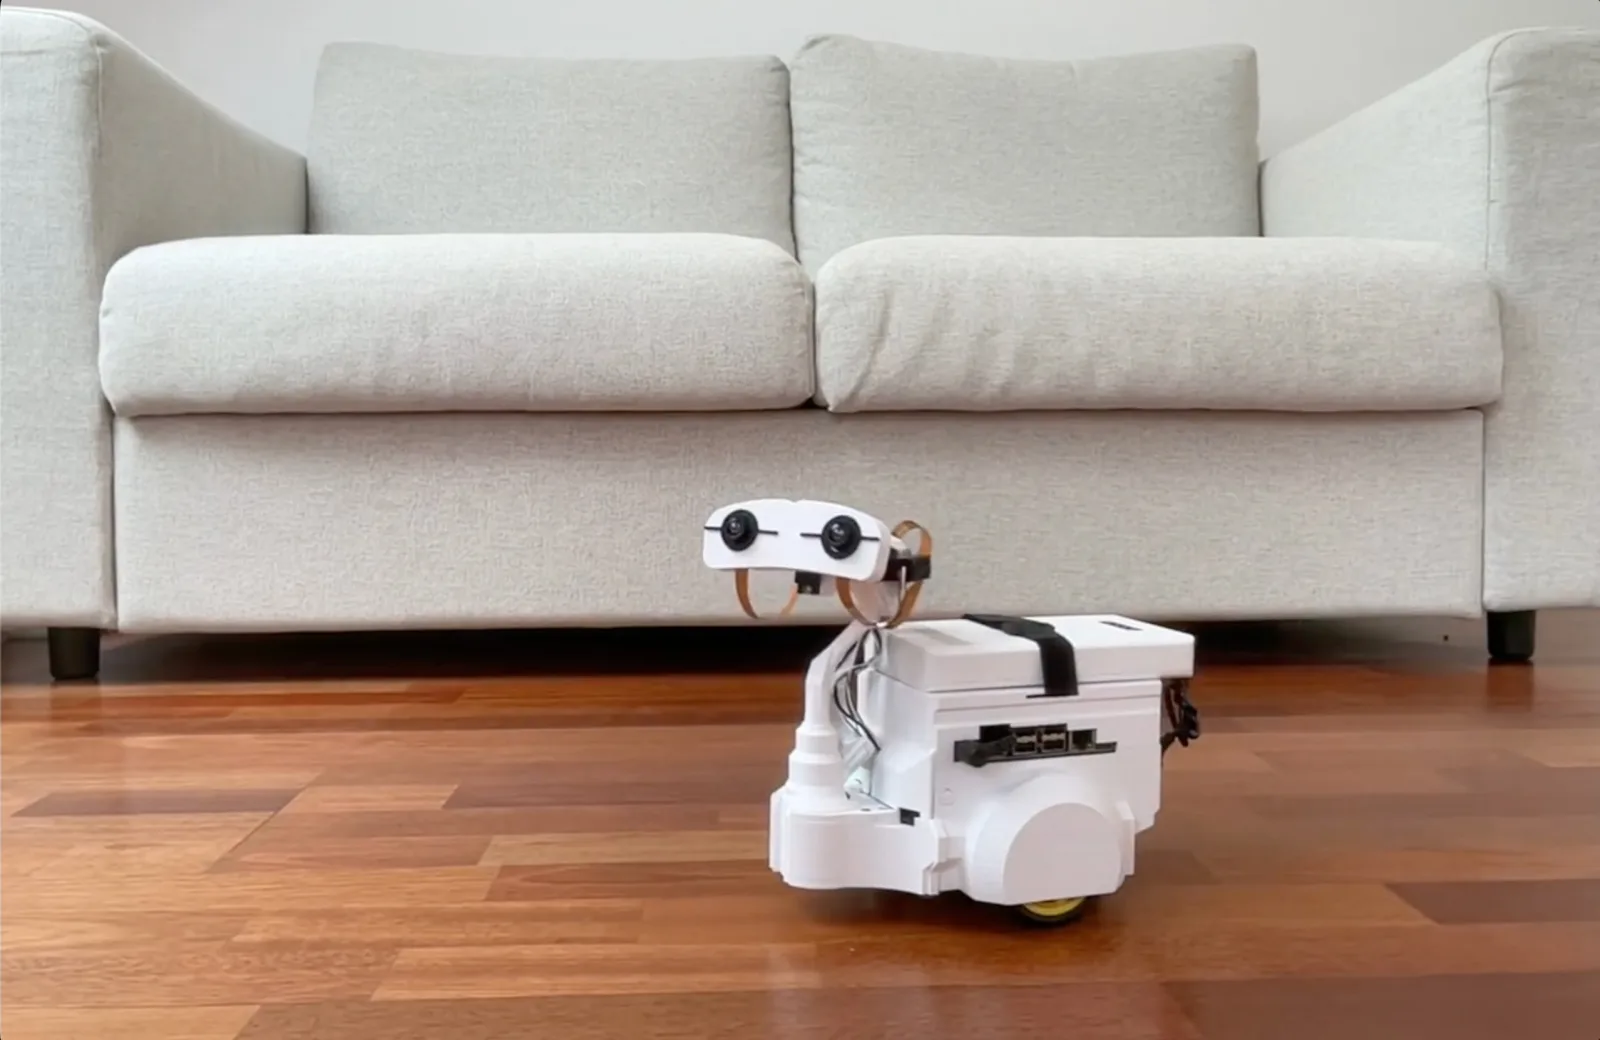
Overview
Mino is a small wheeled developer robot with an expressive stereo-camera head, built around an NVIDIA Jetson Orin Nano that runs speech recognition, a local LLM and depth perception on the robot instead of the cloud. A separate motion controller handles motors and servos with deterministic timing, and the robot reacts to touch by sensing servo load. Founder Nacho Mellado (formerly at Google X, Everyday Robots and Apple) has built it in public since 2024. The Kickstarter page is still in pre-launch, the documentation is "coming soon", and CE, FCC, UKCA and ISED certification is still pending. It suits ROS 2 developers who want a ready-made home robot with on-board AI and already own or will buy a Jetson.
Specifications
| Category | Wheeled rovers · Ready-made dev rovers |
|---|---|
| Released | 2024 |
| Country | Spain |
| Availability | Announced only |
| Crowdfunding | Kickstarter · Pre-launch page (as of Oct 6, 2026) Campaign ↗ |
| Programmability | Full SDK |
| Built-in autonomy | Reactive · Responds to its surroundings without a map, such as avoiding obstacles or following a person |
| LLM support | Official LLM tools · Mino ships with an on-robot LLM module (up to 36 tokens/s) that apps query as a ROS 2 action, for conversation or planning the robot's next actions. Mino official site ↗ |
| MuJoCo simulation | None found · Nothing found. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · Nothing found. |
| Best for | Ages 14+ (estimated) |
| Vision sensors | Depth camera, Camera |
| Actuators | Mixed |
| Audio | Speaker, Microphone |
| Compute type | NVIDIA Jetson |
| Remote control | Via SSH / web / bridge |
| Size | Not published |
| Drive | Wheeled base with a servo-driven neck and head, drive layout not published |
| Compute | NVIDIA Jetson Orin Nano Super Developer Kit (67 TOPS, 8 GB, sold as an add-on) plus a dedicated motion-control processor for motors and servos |
| Vision | Stereo camera pair as the eyes, stereo depth model at 10 fps using about 25% of the GPU |
| Lidar | None |
| Sensors | Microphone, speaker, impedance-based touch reaction through the servos, fused sensors for pose estimation |
| Runtime | Power bank strapped to the back (12–20 V, 60–90 W, not included), 2–5 h with more than 55 Wh. A wall adapter powers it for stationary development |
| Speed | Not published |
| SDK | ROS 2 on Ubuntu 22.04, open-source modules (speech-to-text, LLM, stereo depth, voice commands, emotion classification) running as ROS 2 nodes in Docker containers |
Timeline
- UpdateNacho Mellado started building Mino and documenting the project publicly. Ignacio Mellado ↗
- Kickstarter pre-launchThe Mino Kickstarter pre-launch page went up. Mino official site ↗
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 MARS (Builders Edition)
 UGV Rover (PT / ROS 2 kit)
 UGV Beast (tracked)
 TurtleBot 4 / 4 Lite
 MentorPi M1
 ROSMASTER X3
Image credits
- Image 1: source (official site image)