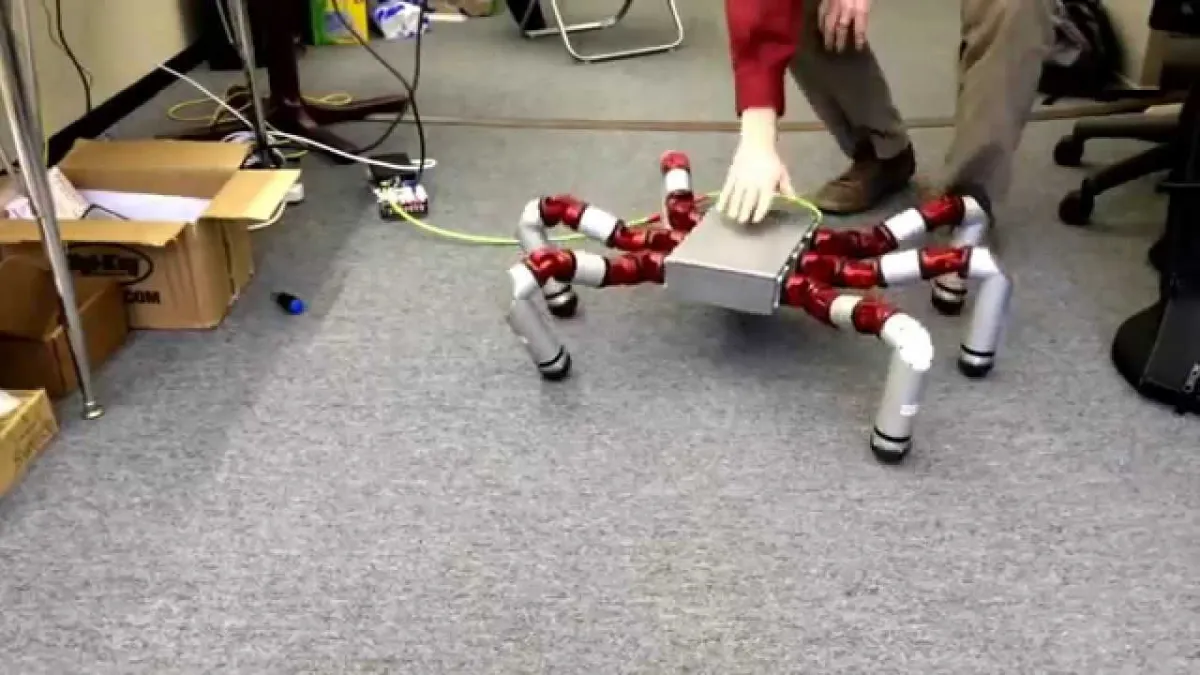
Not for saleLab research robot funded by DARPA's Maximum Mobility and Manipulation (M3) program. The later HEBI Daisy kit was the commercial descendant.
Not for sale (research)ResearchSeries-elastic modulesReconfigurableDARPA M3
Not for saleShipping: Not for sale. University research robot. The closest purchasable relative was HEBI's Daisy kit, now also off the catalog.
Overview
A six-legged walker built in about six months from the same series-elastic modules as CMU's modular snake robots, announced in January 2015 and shown at the DARPA Robotics Challenge finals. Because every joint senses force, it walks over rough ground with a simple tripod gait and no terrain map. The lab has reconfigured it with anywhere from two to twelve limbs, and the module team spun off as HEBI Robotics, whose Daisy hexapod descends from it.
Specifications
| Category | Multi-legged robots · Research & legacy |
|---|---|
| Released | 2015 |
| Country | USA |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Smart servos (Dynamixel, Feetech…) |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Compute | Modules networked over Ethernet, controlled from an off-board or onboard computer (details not published) |
| Weight | About 8 kg (18 lb) |
| Speed | Not published |
| Legs / DOF | 18 series-elastic joint modules as a hexapod (3 per leg), reconfigurable from 2 to 12 limbs |
| Sensors | Joint position, velocity and torque sensing in every module, plus optional camera and gripper modules |
| SDK | Lab code only. A public ROS workspace simulates the SEA snake and SEA hexapod |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 PhantomX AX Hexapod (MK-III)Interbotix Labs / Trossen Robotics (USA)Was $1,095.95 – $1,999.95
 Robugtix T8Robugtix / Amoeba RoboticsWas $2,950
 MekaMonReach Robotics (UK)Was $300
 Vincross HEXAVincross (China)Was $999
 RHexBoston Dynamics / multi-university DARPA project (USA)Not for sale
 LAURON VFZI Forschungszentrum Informatik (Germany)Not for sale
Image credits
- Image 1: source (thumbnail from the CMU Biorobotics Lab video "Snake Monster - Initial Locomotion", rights with CMU)