Overview
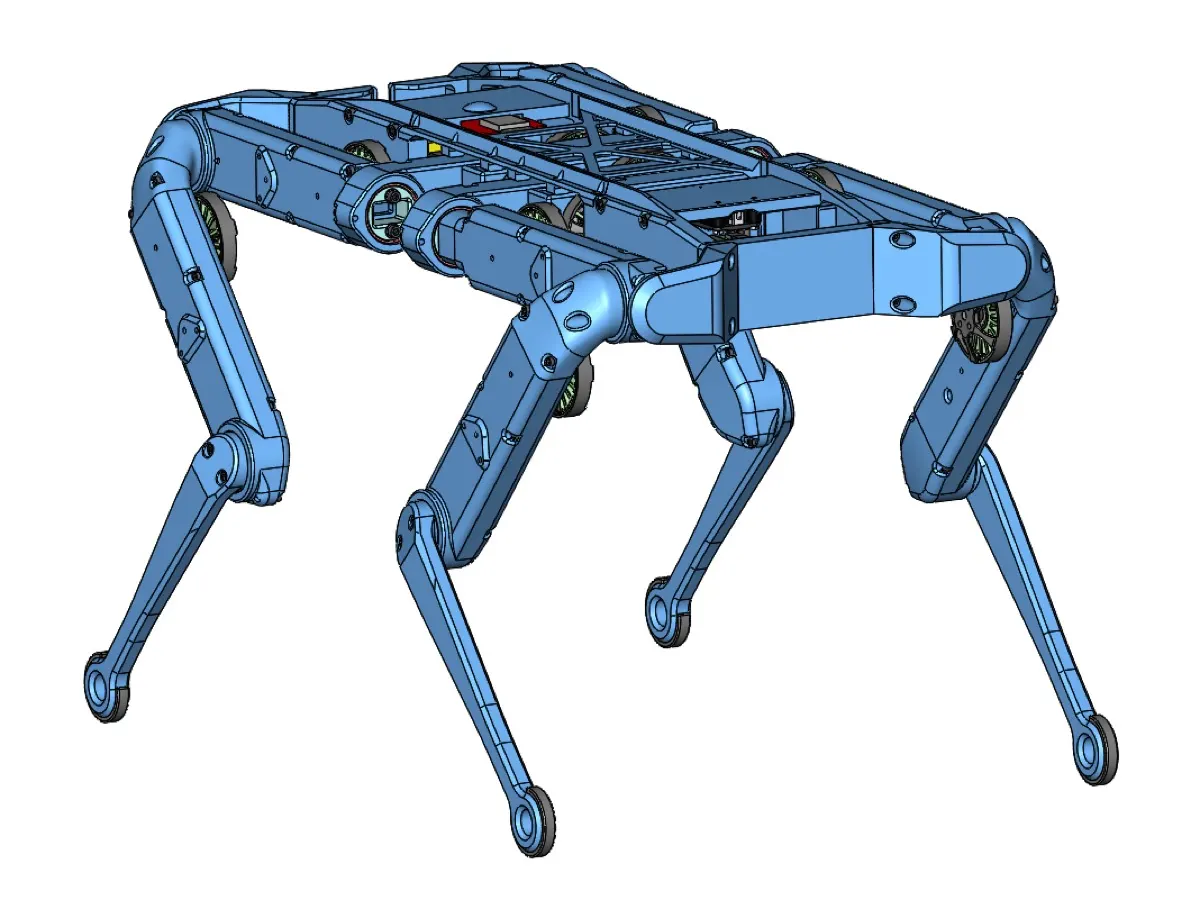
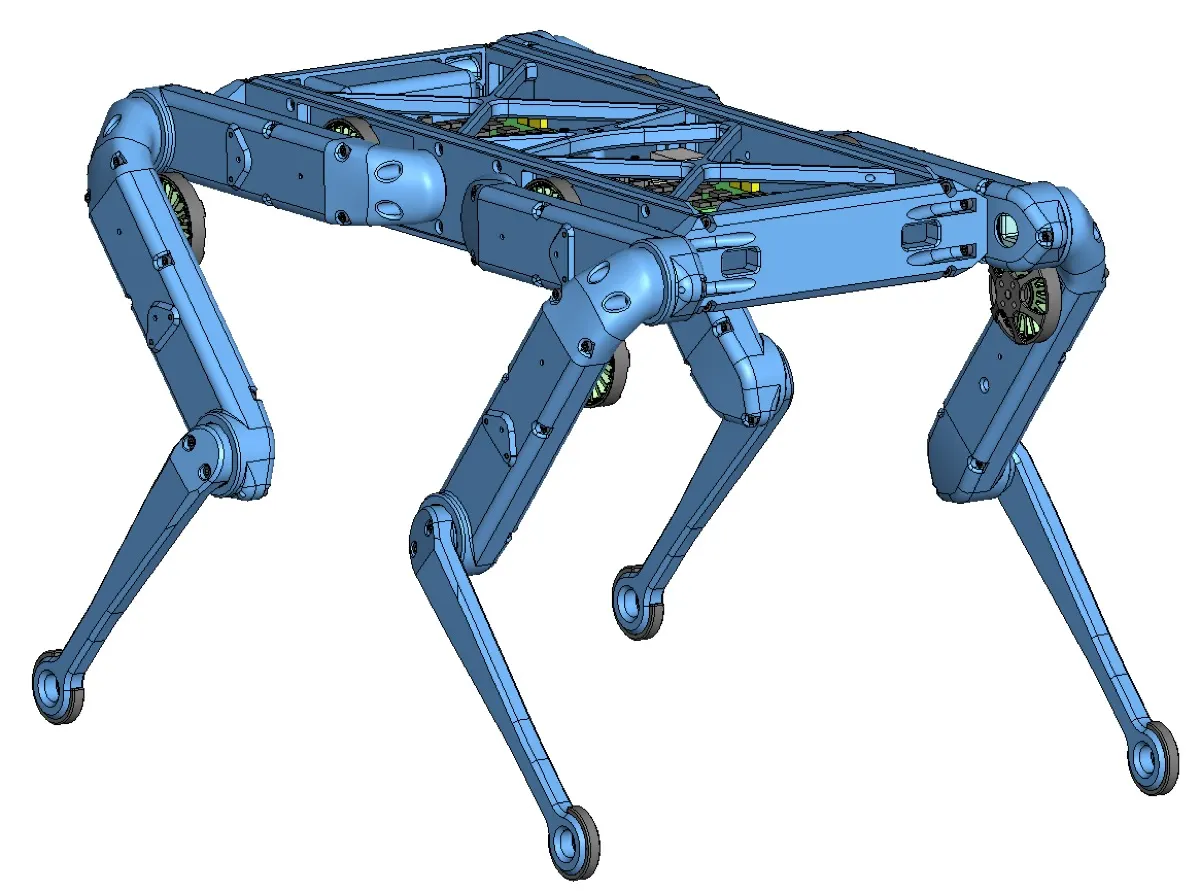
A fully open-source, torque-controlled quadruped built from 3D-printed parts and brushless actuators, published in 2019–2020 so labs could replicate it cheaply. Solo 12 adds hip abduction for full 3D motion. In its 2020 paper the 2.2 kg Solo 8 jumped up to a 65 cm base height from a 24 cm stance and landed undamaged. A research favorite for model-predictive and learned control.
- Type
- Quadruped robot · Research & legacy platforms
- Maker
- Open Dynamic Robot Initiative (MPI Tübingen, NYU, LAAS-CNRS)
- Released
- 2019
- Price
- Not for sale (DIY)
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- Open source (hardware + software)
Price and shipping
Open-source hardware (BSD 3-Clause). Labs build from the published files.
Shipping: Build it. Not for sale. Built from open-source files and off-the-shelf parts.
Specifications
| Category | Quadrupeds · Research & legacy platforms |
|---|---|
| Released | 2019 |
| Country | Germany, USA, France |
| Availability | Not for sale (research) |
| DIY build plans | ODRI Solo 12 · parts $7,100 (2022) (estimate) · difficulty 5/5 |
| Jumping Robots | Ranked #8 by jump height |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No built-in LLM. Its SDK lets software on a computer control it. |
| MuJoCo simulation | Maker URDF only · ODRI publishes Solo 8/12 URDF xacros, not packaged for MuJoCo. robot_properties_solo ↗ |
| NVIDIA Isaac simulation | Official model · ODRI member LAAS ships a Solo 12 Isaac Lab env (CaT) used on hardware. No deploy code, so not kit. constraints-as-terminations ↗ |
| Gazebo simulation | Maker URDF only · ODRI publishes Solo 8/12 URDF xacros, with no Gazebo launch files. robot_properties_solo ↗ |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Compute | Offboard PC via Ethernet/WiFi to custom motor driver boards |
| Weight | 2.2 kg (Solo 8) |
| Speed | Not published |
| DOF | 8 (Solo 8) / 12 (Solo 12) |
| Sensors | IMU, motor encoders |
| SDK | Open-source C++/Python stack |
Common questions
How much does Solo 8 / Solo 12 cost?
Not for sale (DIY). Open-source hardware (BSD 3-Clause). Labs build from the published files.
Can Solo 8 / Solo 12 be bought today?
No. It was never sold to the public.
Who makes Solo 8 / Solo 12?
Solo 8 / Solo 12 is made by Open Dynamic Robot Initiative (MPI Tübingen, NYU, LAAS-CNRS). It came out in 2019.
Can Solo 8 / Solo 12 be programmed?
Open source (hardware + software). Open-source C++/Python stack.
Does Solo 8 / Solo 12 have AI chat or LLM support?
Possible via SDK. No built-in LLM. Its SDK lets software on a computer control it.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Fastest Robot Dogs · the top 20 ranked by speed
- Robot Dog Actuators · how to choose the leg motors
- 8 vs 12 DOF Robot Dogs · two or three motors per leg
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
Similar robots
 Stanford DoggoStanford Student Robotics (Extreme Mobility team)Not for sale
 Laikago / Laikago ProUnitree Robotics (China)Was quote-only
 Swiss-Mile / RIVR wheeled-legged robotSwiss-Mile, now RIVR (Switzerland)Not for sale
 BigDogBoston Dynamics (US) for DARPANot for sale
 LS3 (Legged Squad Support System)Boston Dynamics (US) for DARPA/USMCNot for sale
 LittleDogBoston Dynamics (US) for DARPANot for sale