Overview
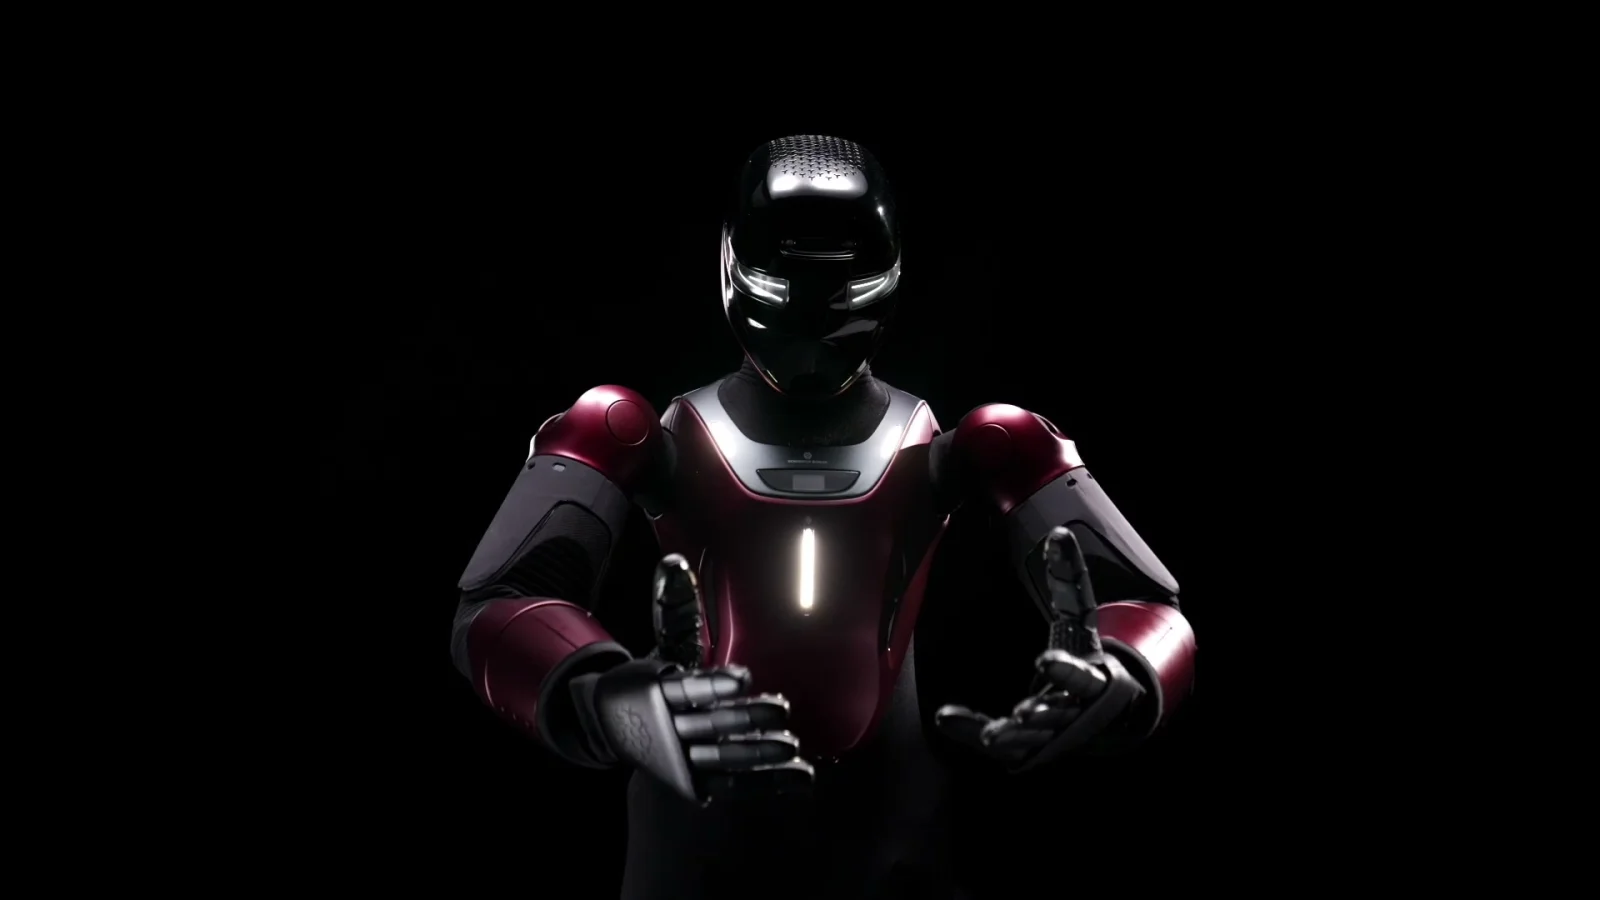
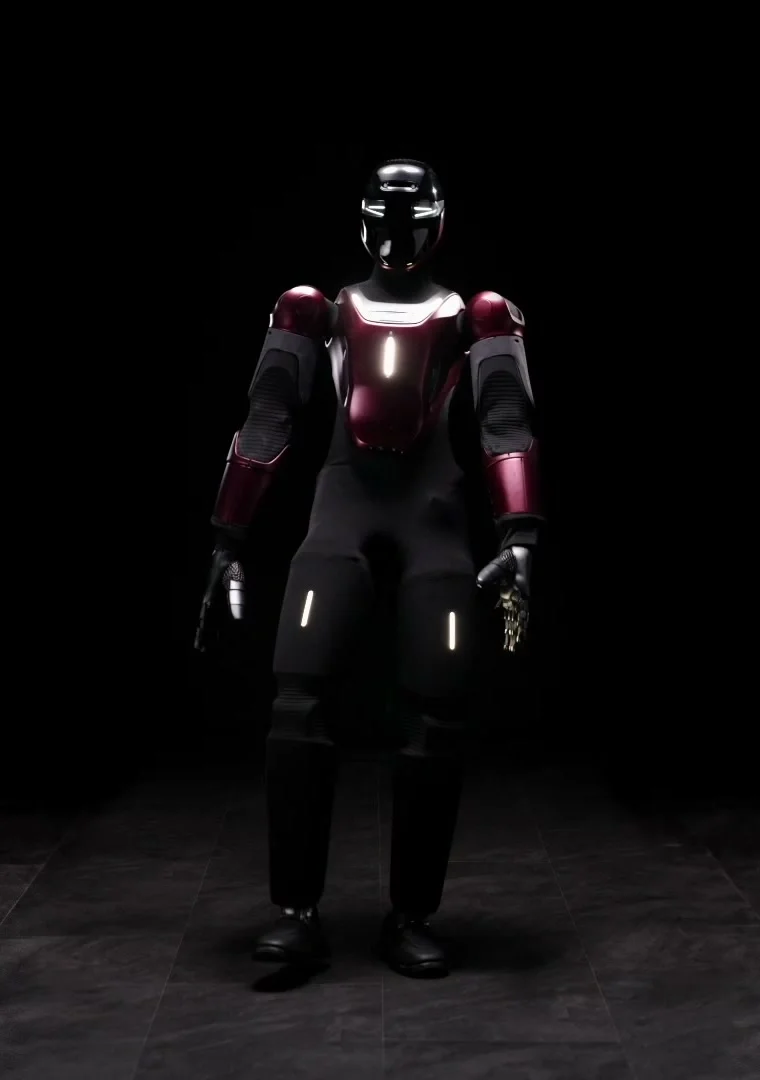
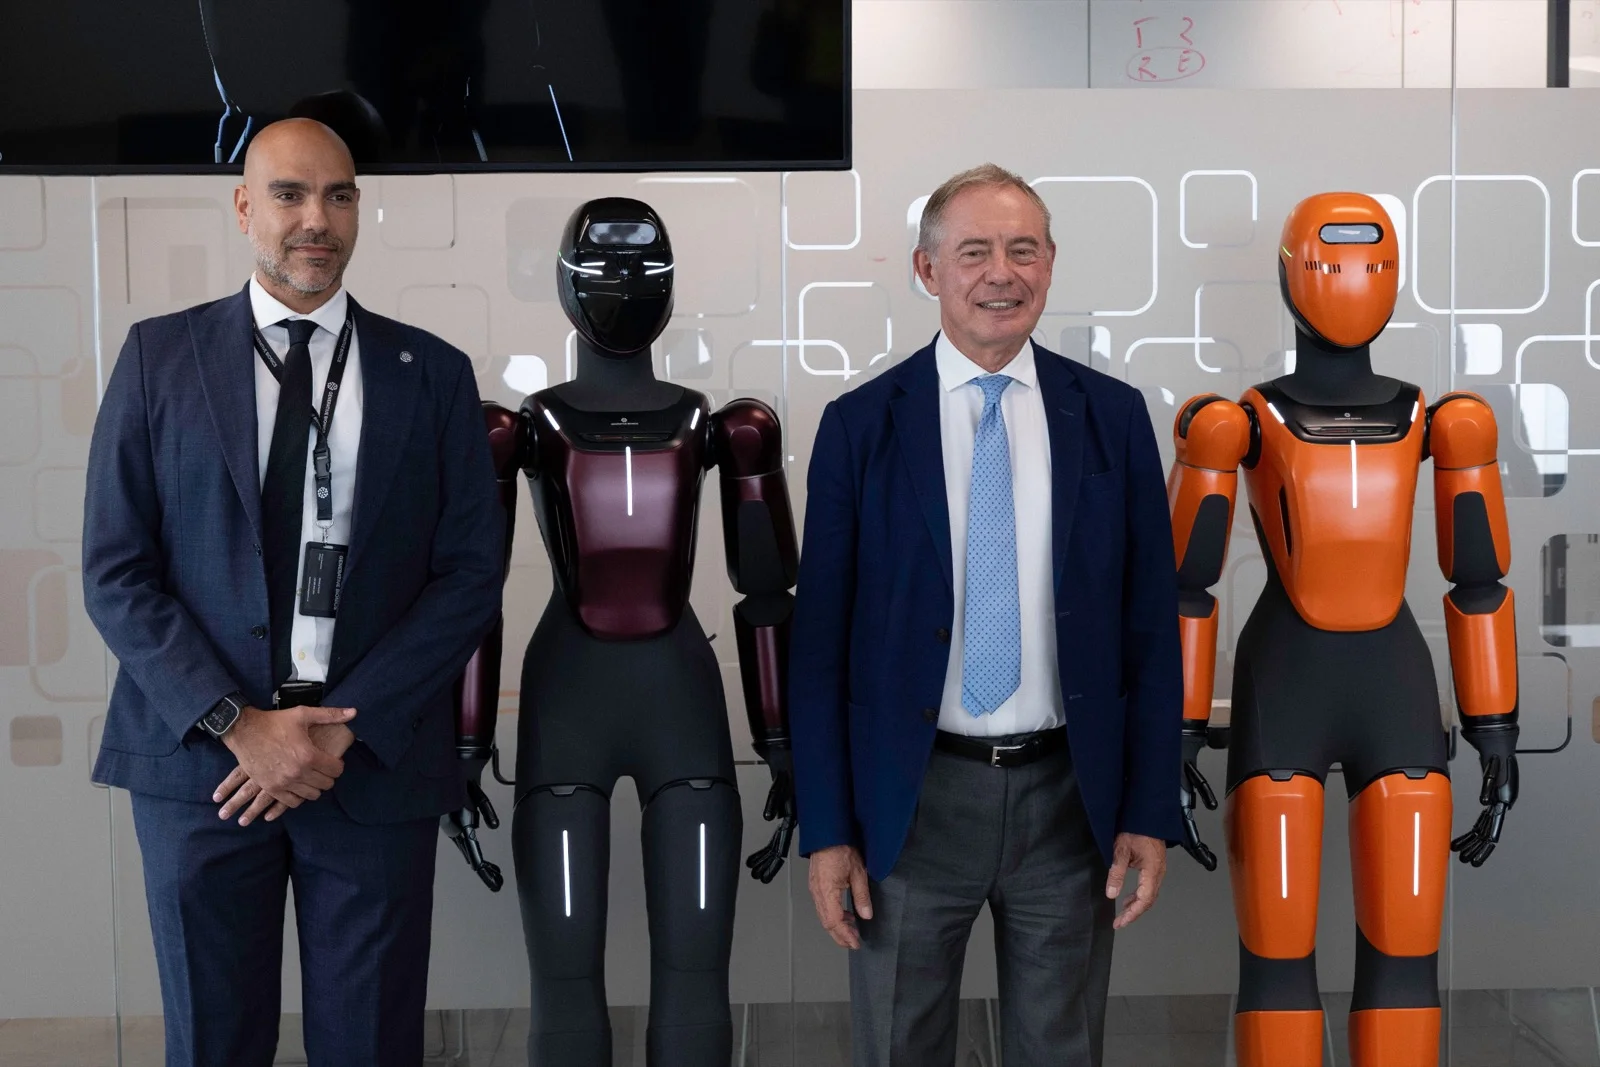
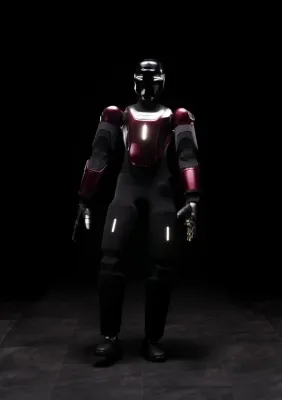
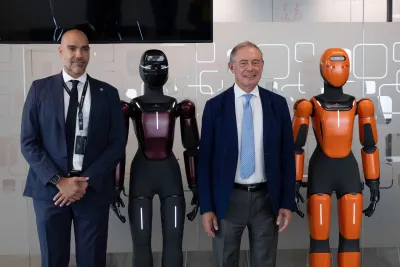
GENE.01 is a full-size industrial humanoid from Generative Bionics, a Genoa company built on two decades of humanoid research at the Istituto Italiano di Tecnologia, home of iCub. It appeared as a concept during AMD's CES keynote in January 2026. A working robot was unveiled on July 20, 2026, six months later. The company sells it as a base platform that gets custom AI, shells, hands and feet for each job. The first such version is a welding humanoid for Fincantieri's Sestri Ponente shipyard, with on-site tests planned by the end of 2026. Eni has also signed an MoU to study inspection and teleoperation uses.
Its main feature is a tactile skin across the whole body that senses touch, proximity, force and temperature, so it can react before and during contact with people. Force sensing also lets workers teach a task by showing the force needed, such as how hard to grip. AMD supplies the onboard CPUs, GPUs and FPGA boards, and Synapticon in Germany is developing the joint actuators. The digital twin, a robot description for simulators, is a URDF on GitHub, PyPI and conda-forge under a non-commercial license. It models 31 body joints and 21 per hand, at about 80 kg and 1.78 m (estimate). No price or official specs have been published, and launch is targeted for Q4 2026.
- Type
- Biped robot · Full-size humanoids
- Maker
- Generative Bionics (Genoa, Italy)
- Released
- 2026
- Price
- No price yet
- Status
- Announced only
- Best for
- Professionals & labs
- Programming
- Limited SDK
Price and shipping
Generative Bionics lists no price or order page (checked November 2026). It targets a Q4 2026 launch and builds custom versions for each industrial customer, so pricing will likely be by quote (unconfirmed).
Shipping: Launch targeted Q4 2026. No order page or pre-order exists. Generative Bionics targets a Q4 2026 launch for industrial customers, starting with the welding version being built with Fincantieri. Generative Bionics ↗
Specifications
| Category | Bipeds · Full-size humanoids |
|---|---|
| Released | 2026 |
| Country | Italy |
| Availability | Announced only |
| Programmability | Limited SDK |
| Built-in autonomy | Reactive · Responds to its surroundings without a map, such as avoiding obstacles or following a person |
| LLM support | None · No LLM is named. Generative Bionics plans to train World Action Models on data from GENE.01 fleets in its Physical AI Data Factory. No public SDK exists that an outside LLM could use to drive the robot. Data Factory press release ↗ |
| MuJoCo simulation | Maker URDF only · The official URDF in gb-robot-models would need converting. Closed-loop linkages are simplified to serial joints, and the license is non-commercial (CC BY-NC 4.0). gb-robot-models ↗ |
| NVIDIA Isaac simulation | Maker URDF only · The same official URDF would need importing. No Isaac Lab task or training code for GENE.01 was found. gb-robot-models ↗ |
| Gazebo simulation | Maker URDF only · The URDF ships with an RViz launch file for ROS 2 Jazzy, but no Gazebo package was found. gb-robot-models ↗ |
| Best for | Professionals & labs |
| Vision sensors | Camera, Depth camera |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | x86 PC (Intel / AMD) |
| Balance type | RL walking |
| Height | About 1.78 m (estimate, measured from the official URDF in its zero pose). No official figure |
| Weight | About 80 kg (estimate, sum of link masses in the official URDF). No official figure |
| Compute | AMD onboard computing, with CPUs, GPUs and FPGA-based embedded vision and sensor processing. Exact chips not published |
| Speed | Not published |
| DOF | 31 body joints in the official model (6 per leg, 7 per arm, 2 in the waist, 3 in the neck) plus 21 joints per hand. The model turns closed-loop linkages into serial joints, so the motor count is not published |
| Sensors | Full-body tactile skin that senses touch, proximity, force and temperature. The official model places RGB and depth cameras plus left, right and rear cameras in the head, a front chest camera and a chest IMU. Sensor-equipped footwear is mentioned in the Eni agreement |
| Balance | Walks on two legs in official videos. The control method is not published. The company's GitHub hosts both a model-based walking library from IIT and an RL motion-imitation library, so RL walking is unconfirmed. |
| SDK | No robot SDK published yet. The official gb-robot-models package (URDF and meshes) installs with pip or conda, or from source in a ROS 2 workspace, with Rerun and RViz viewers. ROS apt packages are still pending |
Common questions
How much does GENE.01 cost?
No price yet. Generative Bionics lists no price or order page (checked November 2026). It targets a Q4 2026 launch and builds custom versions for each industrial customer, so pricing will likely be by quote (unconfirmed).
Can GENE.01 be bought today?
Not yet. It has been announced but is not on sale. No order page or pre-order exists. Generative Bionics targets a Q4 2026 launch for industrial customers, starting with the welding version being built with Fincantieri.
Who makes GENE.01?
GENE.01 is made by Generative Bionics (Genoa, Italy). It came out in 2026.
Can GENE.01 be programmed?
Limited SDK. No robot SDK published yet. The official gb-robot-models package (URDF and meshes) installs with pip or conda, or from source in a ROS 2 workspace, with Rerun and RViz viewers. ROS apt packages are still pending.
Does GENE.01 have AI chat or LLM support?
None. No LLM is named. Generative Bionics plans to train World Action Models on data from GENE.01 fleets in its Physical AI Data Factory. No public SDK exists that an outside LLM could use to drive the robot.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
- MuJoCo Guide · the simulator used to train walking robots
- ROS 2 Guide · the software framework many robots use
- Robot Vision and Depth Sensors · cameras, lidar and other distance sensors
Similar robots
 Optimus (Gen 1 / Gen 2 / V3)
 Figure 01 / Figure 02
 Figure 03
 NEO
 Digit
 Apollo
Sources
GENE.01 unveiling press release (July 2026) ↗ · CES 2026 concept press release ↗ · Fincantieri welding robot press release ↗ · gb-robot-models on GitHub ↗ · gb-robot-models on PyPI ↗