Overview
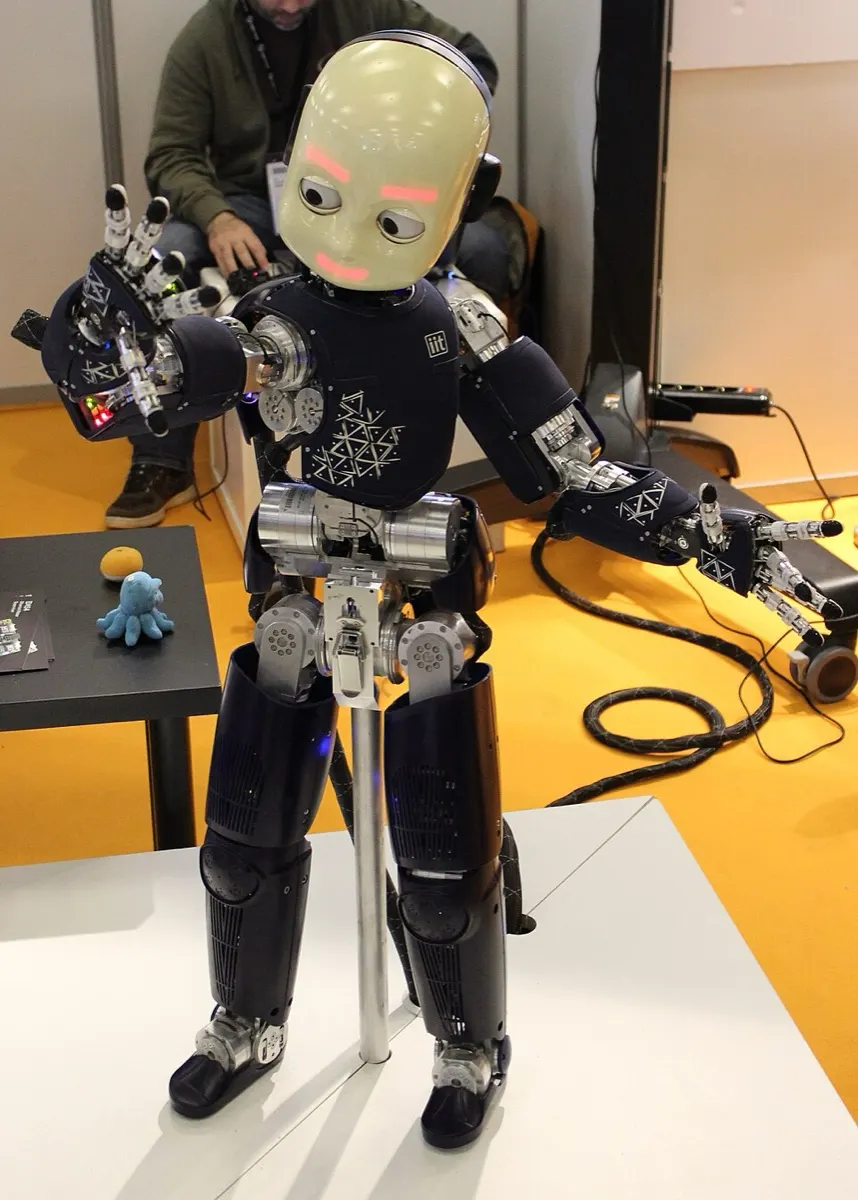
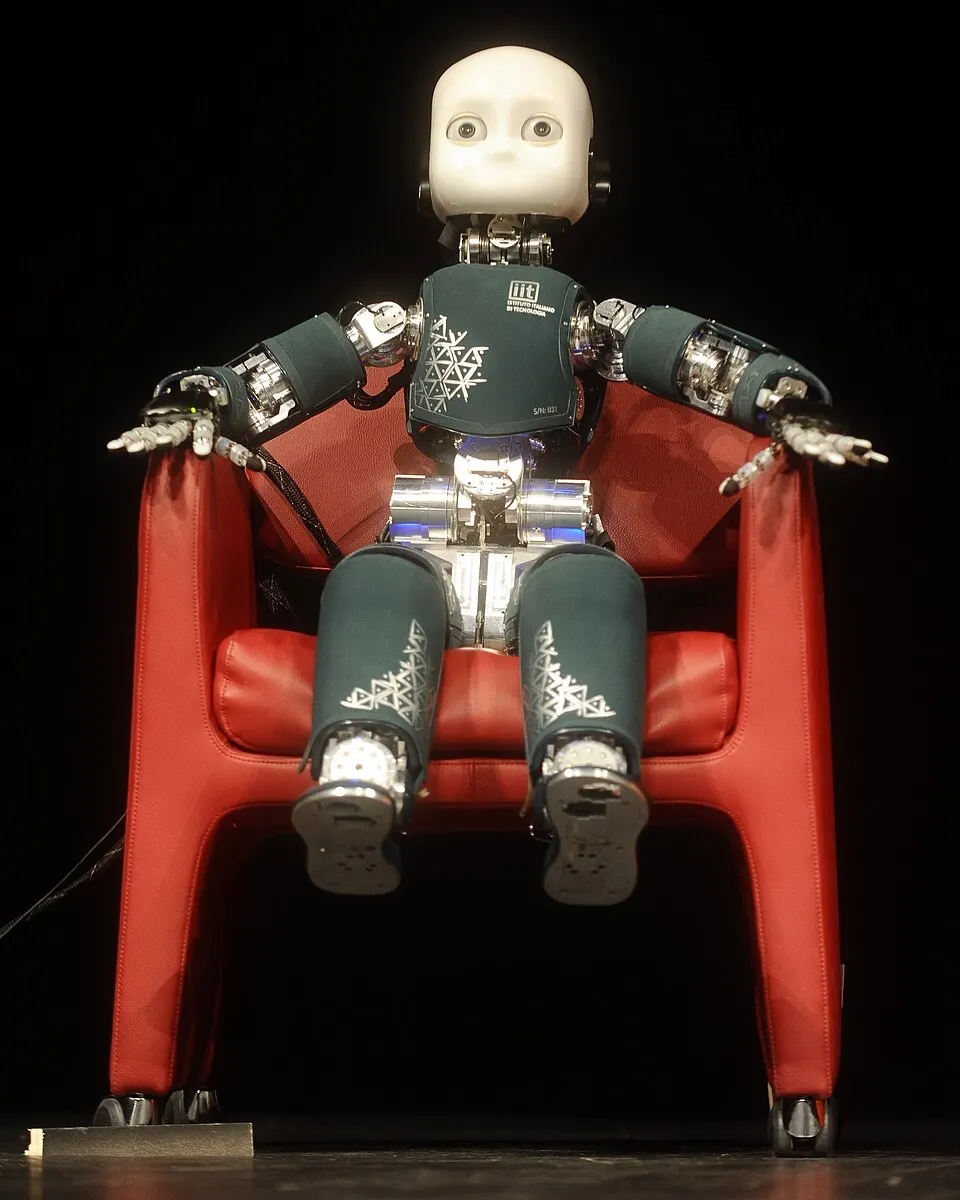
A child-sized open-source humanoid created by the EU RobotCub consortium to study embodied cognition, with dexterous hands and tactile skin. About thirty units are in labs, mostly in Europe. It is the research standard for developmental robotics rather than locomotion, although later versions walk.
- Type
- Biped robot · Research & legacy bipeds
- Maker
- Istituto Italiano di Tecnologia (Italy)
- Released
- 2008
- Price
- ~$280,000 (€250,000)
- Status
- Available
- Best for
- Professionals & labs
- Programming
- Open source (hardware + software)
Price and shipping
Built to order by IIT for research labs (per Wikipedia)
Shipping: Built to order. Built by IIT for research institutions on request. Months of lead time.
Specifications
| Category | Bipeds · Research & legacy bipeds |
|---|---|
| Released | 2008 |
| Country | Italy |
| Availability | Available |
| Sales | About 30 iCub units built, used in labs mostly across the EU (estimate) Wikipedia ↗ |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | Reactive · Responds to its surroundings without a map, such as avoiding obstacles or following a person |
| LLM support | Possible via SDK · Open-source YARP middleware gives full programmatic control, no built-in LLM. |
| MuJoCo simulation | Maker URDF only · IIT publishes official iCub URDF/SDF models. A small community MuJoCo port also exists. icub-models ↗ |
| NVIDIA Isaac simulation | Maker URDF only · IIT publishes official iCub URDF/SDF models, with no Isaac asset found. icub-models ↗ |
| Gazebo simulation | Official model · IIT's icub-models ships Gazebo-tuned iCub models, and robotology maintains YARP Gazebo plugins. icub-models ↗ |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Mixed |
| Audio | Microphone |
| Compute type | x86 PC (Intel / AMD) |
| Balance type | ZMP / IK gait |
| Height | ~1.04 m |
| Weight | ~33 kg (est.) |
| Compute | On-board PC104 / embedded PC with CAN bus |
| Speed | Not published |
| DOF | 53 |
| Sensors | Stereo cameras, mics, IMU, force/torque sensors, tactile skin |
| Balance | Torque-controlled whole-body balancing and ZMP/MPC walking developed in research papers. |
| SDK | YARP middleware, open-source (GPL) hardware and software |
Common questions
How much does iCub cost?
iCub is listed at ~$280,000 (€250,000). Built to order by IIT for research labs (per Wikipedia).
Can iCub be bought today?
Yes, it is on sale. Built by IIT for research institutions on request. Months of lead time.
Who makes iCub?
iCub is made by Istituto Italiano di Tecnologia (Italy). It came out in 2008.
Can iCub be programmed?
Open source (hardware + software). YARP middleware, open-source (GPL) hardware and software.
Does iCub have AI chat or LLM support?
Possible via SDK. Open-source YARP middleware gives full programmatic control, no built-in LLM.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
- MuJoCo Guide · the simulator used to train walking robots
- ROS 2 Guide · the software framework many robots use
- Robot Vision and Depth Sensors · cameras, lidar and other distance sensors
Similar robots
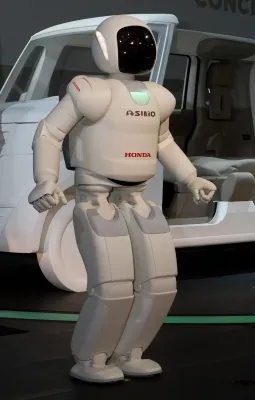 ASIMO (2011 "All-new ASIMO")Honda (Japan)Not for sale
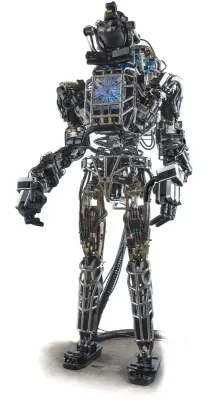 Atlas (hydraulic)Boston Dynamics (USA)Not for sale
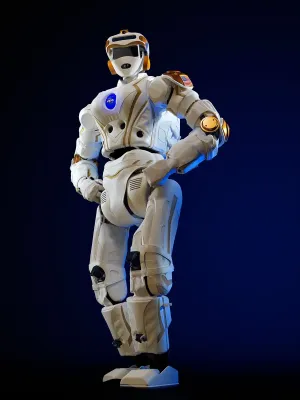 Valkyrie (R5)NASA Johnson Space Center (USA)Not for sale
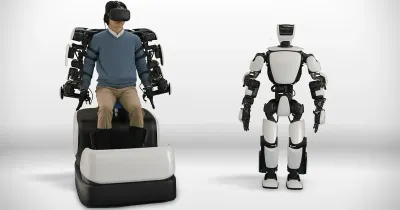 T-HR3Toyota (Japan)Not for sale
 CyberOneXiaomi (China)Not for sale
 Tiangong (Tien Kung)Beijing Humanoid Robot Innovation Center (China)Quote (China)