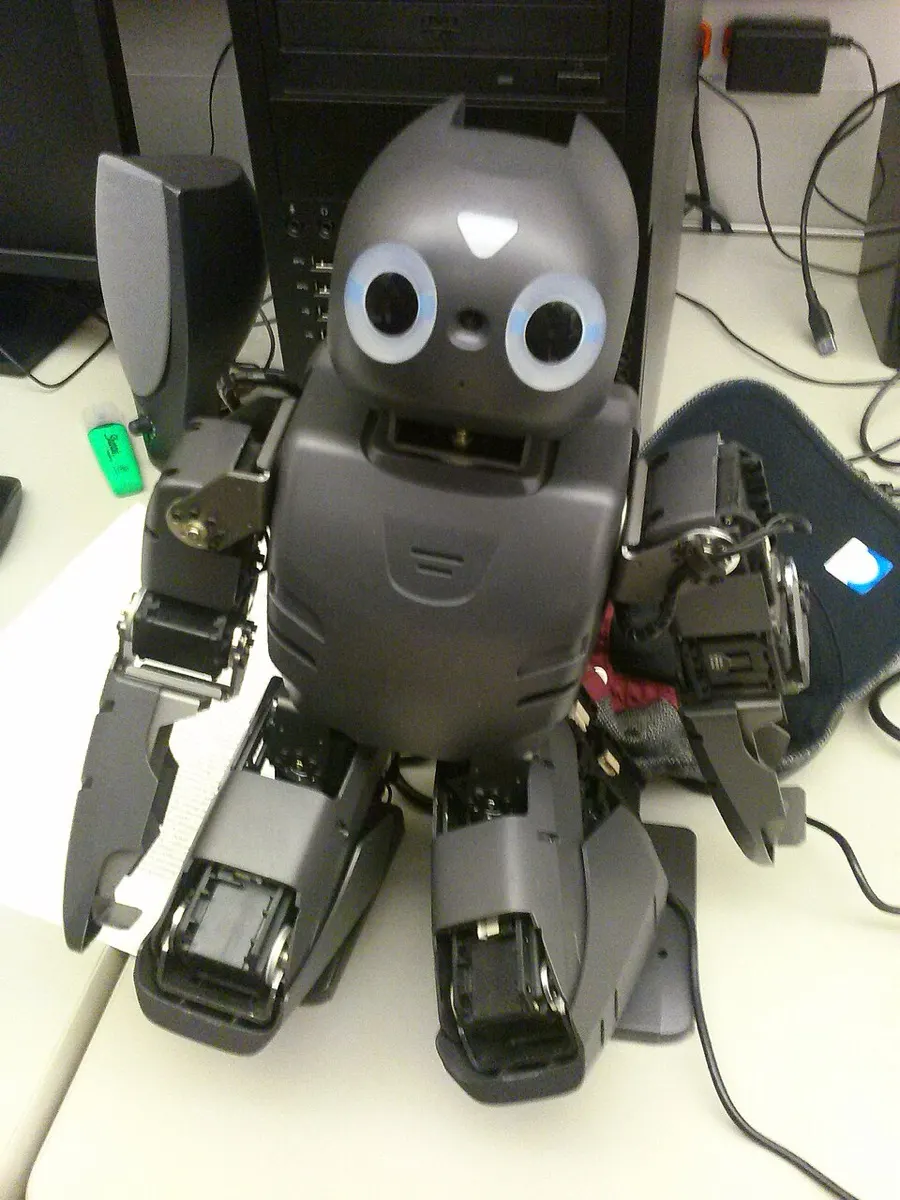
Overview
The open research humanoid that defined the category, backed by a $1.2M NSF grant and winner of the RoboCup KidSize league in 2011–2013. Its hardware and software were published in full, which is why so many later kid-size designs share its layout. It was succeeded by ROBOTIS OP2 (2015) and OP3. Used units still circulate among universities.
- Type
- Biped robot · Research & legacy bipeds
- Maker
- ROBOTIS with Virginia Tech (RoMeLa), Purdue, UPenn
- Released
- 2010
- Price
- Was ~$10,000 – $12,000
- Status
- Discontinued · used/leftover only
- Best for
- Professionals & labs
- Programming
- Open source (hardware + software)
Price and shipping
Historical research price (est.)
Shipping: Used. Discontinued. Used DARwIn-OP and OP2 units occasionally appear on eBay and university surplus.
Specifications
| Category | Bipeds · Research & legacy bipeds |
|---|---|
| Released | 2010 |
| Country | South Korea, USA |
| Availability | Discontinued · used/leftover only |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | Reactive · Responds to its surroundings without a map, such as avoiding obstacles or following a person |
| LLM support | Possible via SDK · No built-in LLM. Its SDK lets software on a computer control it. |
| MuJoCo simulation | Community model · Only a third-party Darwin-OP URDF (HumaRobotics, 2015), which would need converting. darwin_description ↗ |
| NVIDIA Isaac simulation | Community model · Only a third-party Darwin-OP URDF (HumaRobotics, 2015), which would need converting. darwin_description ↗ |
| Gazebo simulation | Official model · ROBOTIS's OP2 ROS packages include an op2_gazebo launch file. ROBOTIS-OP2 ↗ |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Smart servos (Dynamixel, Feetech…) |
| Audio | Speaker, Microphone |
| Compute type | x86 PC (Intel / AMD), Arduino / ESP32 / microcontroller |
| Balance type | ZMP / IK gait |
| Height | 45.5 cm |
| Weight | 2.9 kg |
| Compute | Intel Atom (fit-PC2i) + CM-730 |
| Speed | Not published |
| DOF | 20 Dynamixel MX-28 |
| Sensors | HD camera, 3-axis gyro, 3-axis accelerometer, mics |
| Balance | ZMP-based walking with gyro feedback. Falls under real pushes, then stands up. |
| SDK | Open C++ framework, ROS packages, open CAD and schematics |
Common questions
How much does DARwIn-OP / ROBOTIS OP2 cost?
It sold for ~$10,000 – $12,000. Historical research price (est.).
Can DARwIn-OP / ROBOTIS OP2 be bought today?
It is discontinued, though used or leftover units still turn up. Discontinued. Used DARwIn-OP and OP2 units occasionally appear on eBay and university surplus.
Who makes DARwIn-OP / ROBOTIS OP2?
DARwIn-OP / ROBOTIS OP2 is made by ROBOTIS with Virginia Tech (RoMeLa), Purdue, UPenn. It came out in 2010.
Can DARwIn-OP / ROBOTIS OP2 be programmed?
Open source (hardware + software). Open C++ framework, ROS packages, open CAD and schematics.
Does DARwIn-OP / ROBOTIS OP2 have AI chat or LLM support?
Possible via SDK. No built-in LLM. Its SDK lets software on a computer control it.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
- MuJoCo Guide · the simulator used to train walking robots
- ROS 2 Guide · the software framework many robots use
- Robot Vision and Depth Sensors · cameras, lidar and other distance sensors
Similar robots
 ASIMO (2011 "All-new ASIMO")Honda (Japan)Not for sale
 Atlas (hydraulic)Boston Dynamics (USA)Not for sale
 Valkyrie (R5)NASA Johnson Space Center (USA)Not for sale
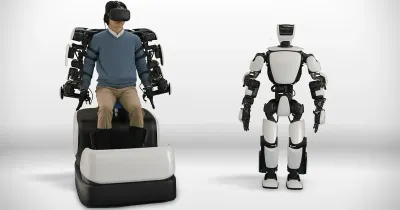 T-HR3Toyota (Japan)Not for sale
 CyberOneXiaomi (China)Not for sale
 Tiangong (Tien Kung)Beijing Humanoid Robot Innovation Center (China)Quote (China)
Sources
Image credits
- Image 1: source (CC BY-SA 4.0, KaputJonny)