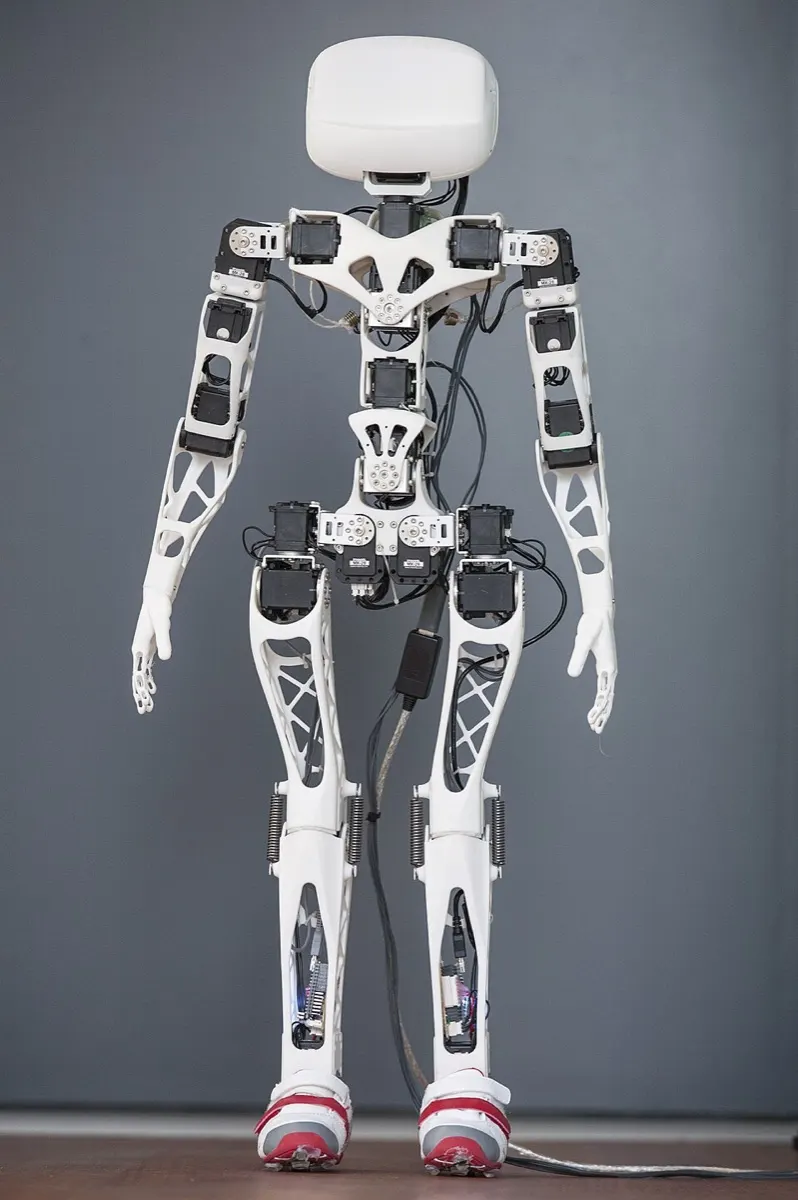
Overview
A 3D-printed open-source humanoid from Inria designed for research, education and art, with a multi-articulated trunk and a Python-first software stack. It walks only with assistance, so it belongs with the non-balancing robots. The project spun off into the Poppy Station community, and the files remain on GitHub.
- Type
- Biped robot · Research & legacy bipeds
- Maker
- Inria Flowers team / Poppy Project (France)
- Released
- 2014
- Price
- DIY (open source)
- Status
- Discontinued · used/leftover only
- Best for
- Professionals & labs
- Programming
- Open source (hardware + software)
Price and shipping
Kits were sold by Génération Robots. The project estimates a complete build at $8,000–9,000, about 60% of it for the 25 Robotis Dynamixel servos
Shipping: Build. Can be built from the open files with 3D-printed parts and Dynamixel servos. Complete kits are rarely offered now.
Specifications
| Category | Bipeds · Research & legacy bipeds |
|---|---|
| Released | 2014 |
| Country | France |
| Availability | Discontinued · used/leftover only |
| DIY build plans | Poppy Humanoid · parts $8,500 (2021) (estimate) · difficulty 3/5 |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No built-in LLM. Its SDK lets software on a computer control it. |
| MuJoCo simulation | Maker URDF only · Maker's repo publishes a URDF, no MuJoCo model found. poppy-humanoid URDF ↗ |
| NVIDIA Isaac simulation | Maker URDF only · Maker's repo publishes a URDF, no Isaac asset found. poppy-humanoid URDF ↗ |
| Gazebo simulation | Official model · Maker's repo includes a Gazebo launch file for the URDF. poppy-humanoid gazebo.launch ↗ |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Smart servos (Dynamixel, Feetech…) |
| Audio | No audio |
| Compute type | Raspberry Pi, Other ARM chip |
| Balance type | Scripted |
| Height | 83–84 cm |
| Weight | 3.5 kg |
| Compute | Raspberry Pi / ODROID |
| Speed | Not published |
| DOF | 25 Dynamixel |
| Sensors | Camera, IMU |
| Balance | Needs a support harness to walk. Used mostly for upper-body and interaction research. |
| SDK | pypot Python library, Snap! blocks, Jupyter, open CAD and software |
Common questions
How much does Poppy Humanoid cost?
DIY (open source). Kits were sold by Génération Robots. The project estimates a complete build at $8,000–9,000, about 60% of it for the 25 Robotis Dynamixel servos.
Can Poppy Humanoid be bought today?
It is discontinued, though used or leftover units still turn up. Can be built from the open files with 3D-printed parts and Dynamixel servos. Complete kits are rarely offered now.
Who makes Poppy Humanoid?
Poppy Humanoid is made by Inria Flowers team / Poppy Project (France). It came out in 2014.
Can Poppy Humanoid be programmed?
Open source (hardware + software). pypot Python library, Snap! blocks, Jupyter, open CAD and software.
Does Poppy Humanoid have AI chat or LLM support?
Possible via SDK. No built-in LLM. Its SDK lets software on a computer control it.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
- MuJoCo Guide · the simulator used to train walking robots
- ROS 2 Guide · the software framework many robots use
- Robot Vision and Depth Sensors · cameras, lidar and other distance sensors
Similar robots
 ASIMO (2011 "All-new ASIMO")Honda (Japan)Not for sale
 Atlas (hydraulic)Boston Dynamics (USA)Not for sale
 Valkyrie (R5)NASA Johnson Space Center (USA)Not for sale
 T-HR3Toyota (Japan)Not for sale
 CyberOneXiaomi (China)Not for sale
 Tiangong (Tien Kung)Beijing Humanoid Robot Innovation Center (China)Quote (China)
Image credits
- Image 1: source (CC BY-SA 4.0, Inria / Poppy-project.org / Photo H. Raguet)