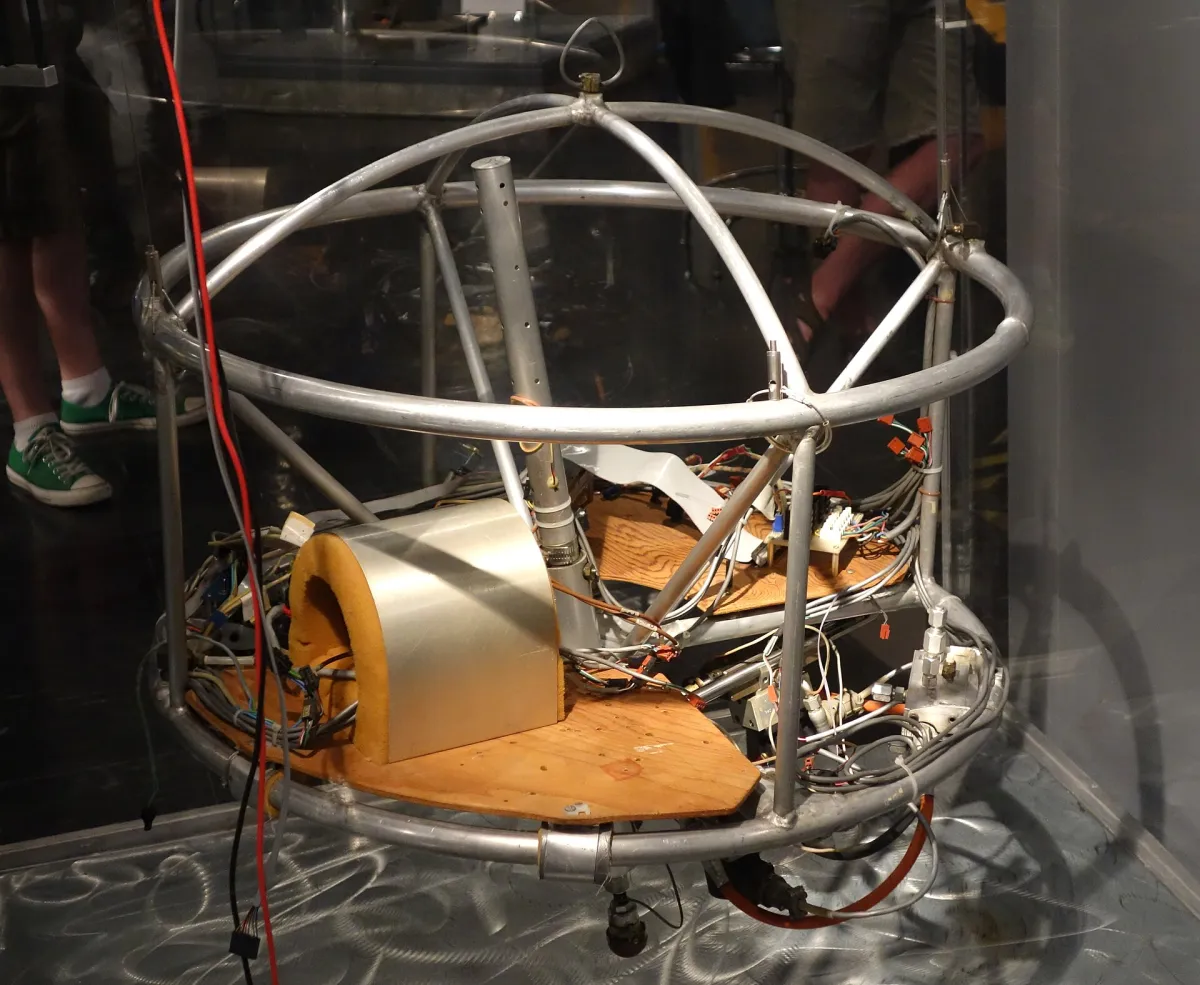
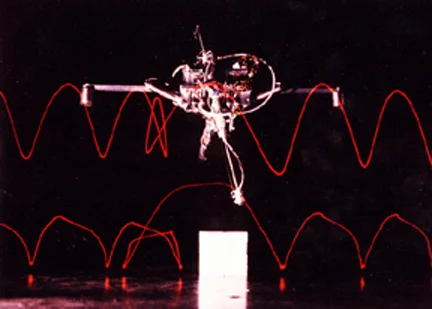
Not for saleDARPA-funded research machines (planar hopper 1980–1982, 3D hopper 1983–1984). The 3D hopper is now displayed at the MIT Museum.
Not for sale (research)Not programmableResearchDynamic balancePneumatic legHistoric
Not for saleShipping: Not for sale. Not available. Historic research machines, with the 3D hopper on display at the MIT Museum.
Remote control: Not possible. Historic laboratory machines.
Overview
Marc Raibert's pogo-stick robots showed that dynamic balance could come from a surprisingly simple controller split into three parts, one for hopping height, one for forward speed through foot placement and one for body attitude. The planar hopper ran around a 2.5 m tether boom in 1980–1982, and the 3D hopper then balanced and ran freely on the lab floor at up to 2.2 m/s in 1983–1984. The same approach carried over to the Leg Lab's bipeds and quadrupeds after Raibert moved the lab to MIT, and later to Boston Dynamics machines such as BigDog. Modern hoppers such as Disney's LEAP and SALTO still use Raibert-style control.
Specifications
| Category | Jumpers & hoppers · Jumping & hopping robots |
|---|---|
| Released | 1980 |
| Country | USA |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Mixed |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Remote control | Not programmable |
| Size | Planar hopper about 8.5 kg. 3D hopper 1.10 m tall, 17.3 kg |
| Locomotion | One telescoping pneumatic leg that acts as spring and thrust actuator. The planar hopper's hip was pneumatic, the 3D hopper uses a hydraulic 2-axis gimbal hip |
| Compute | Off-board minicomputer in a nearby room, linked by an umbilical cable |
| Camera | None |
| Sensors | Leg length and hip angle potentiometers, foot contact and body attitude sensing. The planar hopper also used sensors on its tether-boom pivot |
| Runtime | Continuous while on the umbilical (compressed air, hydraulic and electrical power supplied off-board) |
| Speed | Planar hopper up to 1.2 m/s, 3D hopper up to 2.2 m/s |
| SDK | None |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 Parrot Jumping Sumo (and Jumping Race / Night)Parrot (France)Was $159.99 (2014)
 SALTO / SALTO-1PUC Berkeley Biomimetic Millisystems Lab (USA)Not for sale
 Sand FleaBoston Dynamics (USA)Not for sale
 BionicKangarooFesto Bionic Learning Network (Germany)Not for sale
 UCSB 30-Meter JumperUC Santa Barbara Hawkes Lab with Disney Research and Caltech (USA)Not for sale
 SpaceHopperETH Zurich Robotic Systems Lab student focus project (Switzerland)Not for sale