Overview
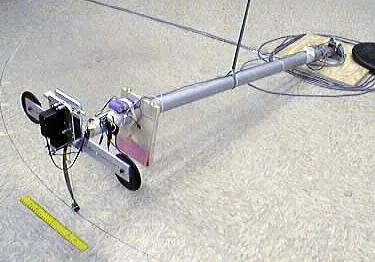
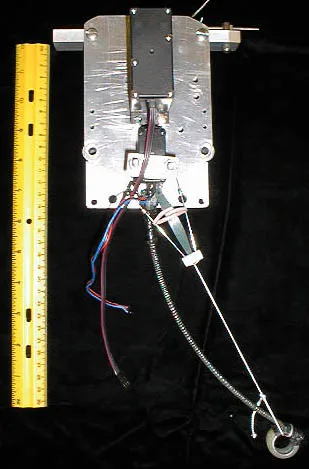
A pogo-stick robot whose whole leg is a single curved strip of archery-bow fiberglass. During flight a hobby servo pulls the bow string to bend the leg and store energy. At touchdown the string goes slack and the spring releases that energy, so no motor carries load while the robot is on the ground. Since the energy is stored slowly during the long flight phase, small low-power servos are enough. The hip pivots freely and sits just above the body's center of mass, so the body hangs like a pendulum and stays upright with no active attitude control. This removes the stance-phase hip torque that Raibert's hoppers relied on, and the leg returns about 70–80% of its energy each bounce. The planar prototype circled a 1.5 m radius boom, with an elastic cord to the ceiling cutting effective gravity to about 0.35 G. It crossed patio-brick stepping stones and shallow stairs using a real-time graph-search planner. A later 3D version without a boom, refined with help from Jean-Christophe Zufferey of EPFL, used a two-axis gimbal hip and a flywheel-driven thrust mechanism. It managed short hops under remote control (CLAWAR 2002). The authors noted that RHex later used similar curved spring legs, though without a bow string for energy storage. Spring-powered jumpers such as SALTO continue the same theme of storing energy in an elastic leg.
- Type
- Jumping robot · Jumping & hopping robots
- Maker
- Carnegie Mellon University Robotics Institute, Garth Zeglin and H. Benjamin Brown (USA)
- Released
- 1997
- Price
- Not for sale
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- No programmability
Price and shipping
University research machine, the subject of two ICRA 1998 papers and Garth Zeglin's 1999 PhD thesis. The Bow Leg design is covered by US Patent 7,270,589.
Shipping: Not for sale. Not available. A historic research machine, and the planar prototype has since been disassembled.
Specifications
| Category | Jumpers & hoppers · Jumping & hopping robots |
|---|---|
| Released | 1997 |
| Country | USA |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no SDK to connect one. |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Hobby servos |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Remote control | Not programmable |
| Size | Leg 25 cm toe to hip, leg spring only 30 g. Planar machine about 2.5 kg on its boom, of which the hopper mechanism is 730 g, batteries 200 g and ballast plus boom weight about 1.6 kg |
| Locomotion | One curved fiberglass leaf-spring leg on a freely pivoting hip bearing. A 'bow string' from the foot lets a hobby-servo thrust mechanism bend the leg during flight, and a second hobby servo sets the leg angle through control strings |
| Compute | Off-board 133 MHz Pentium PC running QNX, with a quadrature decoder card and multifunction I/O card, linked by an umbilical along the boom. The 200 Hz control loop sends PWM commands to the servos |
| Camera | None |
| Sensors | Two 512-line optical encoders at the boom base for position, a potentiometer at the boom end for body pitch, and a string tension switch |
| Runtime | About 30–45 minutes on four on-board NiCd sub-C cells (about 5 Wh) |
| Speed | Hops up to 50 cm high and runs a little over 1 m/s, both in about 0.35 G simulated gravity |
| SDK | None |
Common questions
How much does CMU Bow Leg Hopper cost?
Not for sale. University research machine, the subject of two ICRA 1998 papers and Garth Zeglin's 1999 PhD thesis. The Bow Leg design is covered by US Patent 7,270,589.
Can CMU Bow Leg Hopper be bought today?
No. It was never sold to the public.
Who makes CMU Bow Leg Hopper?
CMU Bow Leg Hopper is made by Carnegie Mellon University Robotics Institute, Garth Zeglin and H. Benjamin Brown (USA). It came out in 1997.
Can CMU Bow Leg Hopper be programmed?
No programmability.
Does CMU Bow Leg Hopper have AI chat or LLM support?
None. No built-in LLM and no SDK to connect one.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Jumping Robots · the top 10 ranked by jump height
Similar robots
 Parrot Jumping Sumo (and Jumping Race / Night)Parrot (France)Was $159.99 (2014)
 SALTO / SALTO-1PUC Berkeley Biomimetic Millisystems Lab (USA)Not for sale
 Sand FleaBoston Dynamics (USA)Not for sale
 BionicKangarooFesto Bionic Learning Network (Germany)Not for sale
 UCSB 30-Meter JumperUC Santa Barbara Hawkes Lab with Disney Research and Caltech (USA)Not for sale
 SpaceHopperETH Zurich Robotic Systems Lab student focus project (Switzerland)Not for sale
Sources
The Bow Leg Hopping Robot (ICRA 1998) ↗ · Control of a Bow Leg Hopping Robot (ICRA 1998) ↗ · Zeglin PhD thesis (1999) ↗ · First Hops of the 3D Bow Leg (CLAWAR 2002) ↗ · CMU Robotics Institute publication page ↗