Overview
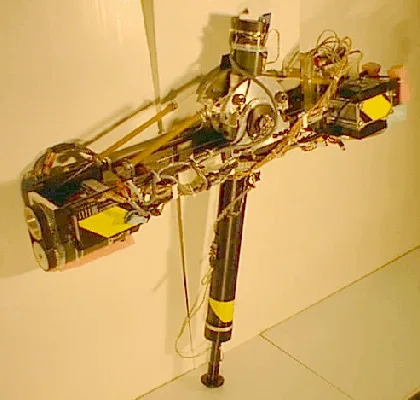
Martin Buehler had done a post-doc with Marc Raibert. His McGill lab built the ARL Monopod by adapting the design and control laws of Raibert's hydraulic and pneumatic hoppers to low-power electric motors. Monopod I ran at 1.2 m/s on a treadmill while attached to a low-friction planarizer that kept it in a vertical plane. It averaged 125 W of mechanical power for a specific resistance of 0.7, which its builders called the fastest and most efficient electric legged robot of its day. Its tests showed that 40–50% of that energy went into simply swinging the leg, so Monopod II added rubber springs at the hip. Running as two synchronized passive oscillations, it hopped on its leg spring while the leg and body swung about the hip spring. At 1.25 m/s it used about 48 W at the motor shafts (20.7 J per step), a specific resistance of 0.22. The 1999 paper reports this as the best efficiency of any actively controlled legged robot. These figures leave out motor losses, so electrical input was higher. The same lab went on to build Scout quadrupeds and to work on RHex.
- Type
- Jumping robot · Jumping & hopping robots
- Maker
- Ambulatory Robotics Lab (ARL), Centre for Intelligent Machines, McGill University (Canada)
- Released
- 1992
- Price
- Not for sale
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- No programmability
Price and shipping
University research robots built in Martin Buehler's lab (Monopod I 1992–1994, Monopod II 1993–1997, per the lab's robot list).
Shipping: Not for sale. Not available. Historic university research machines.
Specifications
| Category | Jumpers & hoppers · Jumping & hopping robots |
|---|---|
| Released | 1992 |
| Country | Canada |
| Availability | Not for sale (research) |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no SDK to connect one. |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | DC / gear motors |
| Audio | No audio |
| Compute type | Proprietary / undisclosed |
| Remote control | Not programmable |
| Size | Monopod II about 0.7 m tall and 18 kg including 1.9 kg of moving planarizer parts (body 11.5 kg, leg 4.6 kg). Monopod I 15 kg |
| Locomotion | One prismatic leg, an 80 W brushed Maxon DC motor turns a ball screw in series with a helical compression leg spring. The hip is driven by a second 80 W motor through a timing belt, ball screw and cables over a pulley (30:1, 55 Nm). Monopod II adds natural-rubber surgical-tubing hip springs spliced into the hip cables |
| Compute | Transputer-based real-time control board issuing motor torque commands at 1 kHz (Monopod I). Monopod II carried an on-board controller, model not published |
| Camera | None |
| Sensors | Optical encoders on the leg actuator and body height, a linear potentiometer for leg length in stance (1993 leg design), plus body height, forward travel and pitch measured through the planarizer |
| Runtime | Monopod I was not power-autonomous. Monopod II carried on-board batteries and controller, but run time was not published (two-minute treadmill runs are reported) |
| Speed | Monopod I up to 1.2 m/s (4.3 km/h), Monopod II up to 1.25 m/s (4.5 km/h) on a treadmill |
| SDK | None |
Common questions
How much does ARL Monopod I and II cost?
Not for sale. University research robots built in Martin Buehler's lab (Monopod I 1992–1994, Monopod II 1993–1997, per the lab's robot list).
Can ARL Monopod I and II be bought today?
No. It was never sold to the public.
Who makes ARL Monopod I and II?
ARL Monopod I and II is made by Ambulatory Robotics Lab (ARL), Centre for Intelligent Machines, McGill University (Canada). It came out in 1992.
Can ARL Monopod I and II be programmed?
No programmability.
Does ARL Monopod I and II have AI chat or LLM support?
None. No built-in LLM and no SDK to connect one.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Jumping Robots · the top 10 ranked by jump height
Similar robots
 Parrot Jumping Sumo (and Jumping Race / Night)Parrot (France)Was $159.99 (2014)
 SALTO / SALTO-1PUC Berkeley Biomimetic Millisystems Lab (USA)Not for sale
 Sand FleaBoston Dynamics (USA)Not for sale
 BionicKangarooFesto Bionic Learning Network (Germany)Not for sale
 UCSB 30-Meter JumperUC Santa Barbara Hawkes Lab with Disney Research and Caltech (USA)Not for sale
 SpaceHopperETH Zurich Robotic Systems Lab student focus project (Switzerland)Not for sale
Sources
McGill ARL Monopod I page (archived) ↗ · ARL robot list (archived) ↗ · Ahmadi & Buehler, ARL Monopod II paper (ICRA 1999) ↗ · Gregorio, Ahmadi & Buehler (IEEE SMC 1997) ↗ · Ahmadi & Buehler, hip spring experiments (ISER 1997) ↗ · Rad, Gregorio & Buehler, leg design (IROS 1993) ↗ · McGill Reporter (2000) ↗
Image credits
- Image 1: source (ARL Monopod II lab photo, rights with the McGill Ambulatory Robotics Laboratory)