Was $1,599 (2012)Clearpath's complete pre-assembled package at launch; price varied by reseller and laptop/3D-camera bundle.
Discontinued · used/leftover onlyVia SSH / web / bridgeKobuki baseKinect eraROS 1Discontinued
Weeks+Shipping: Used only. Out of production; university surplus and eBay are the realistic sources.
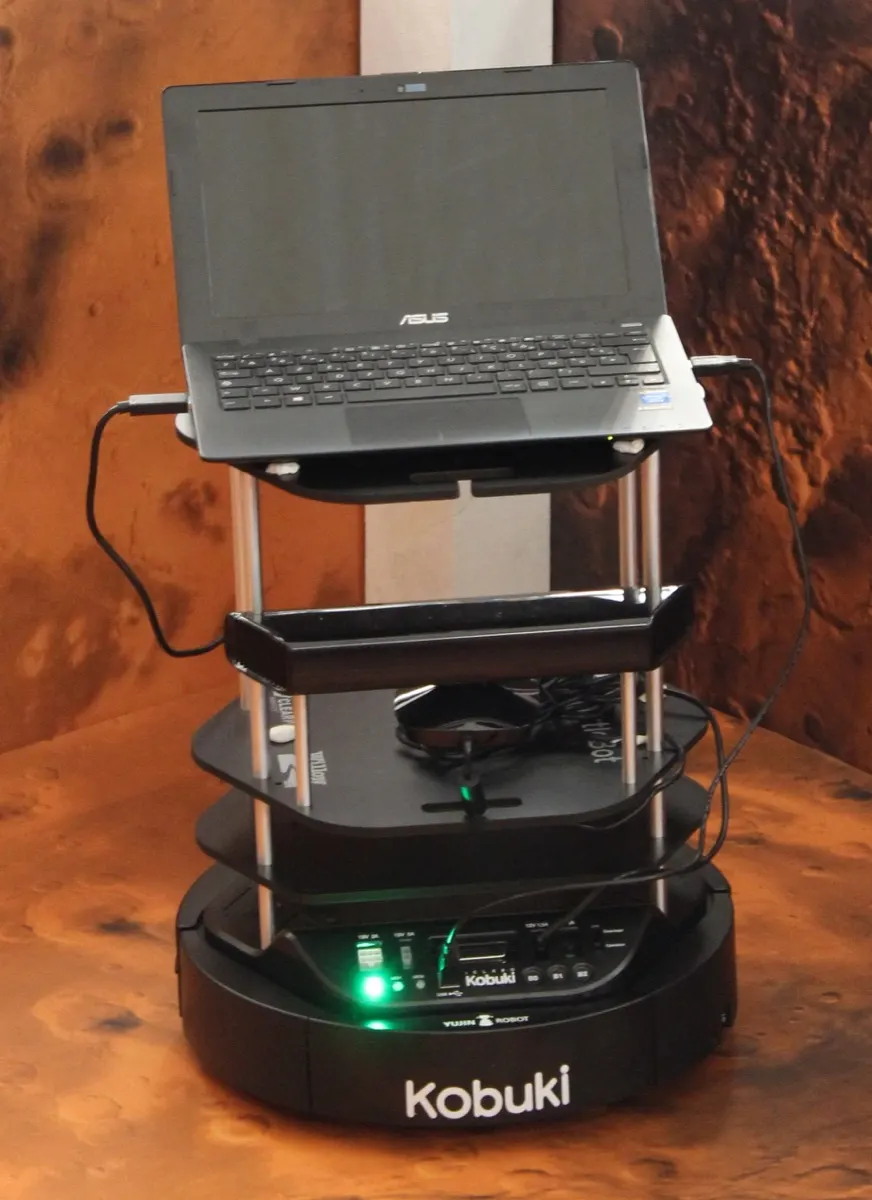
Remote control: The laptop riding on the robot is the brain; ROS 1 on Linux runs everything, and remote machines connect over the ROS network.
Overview
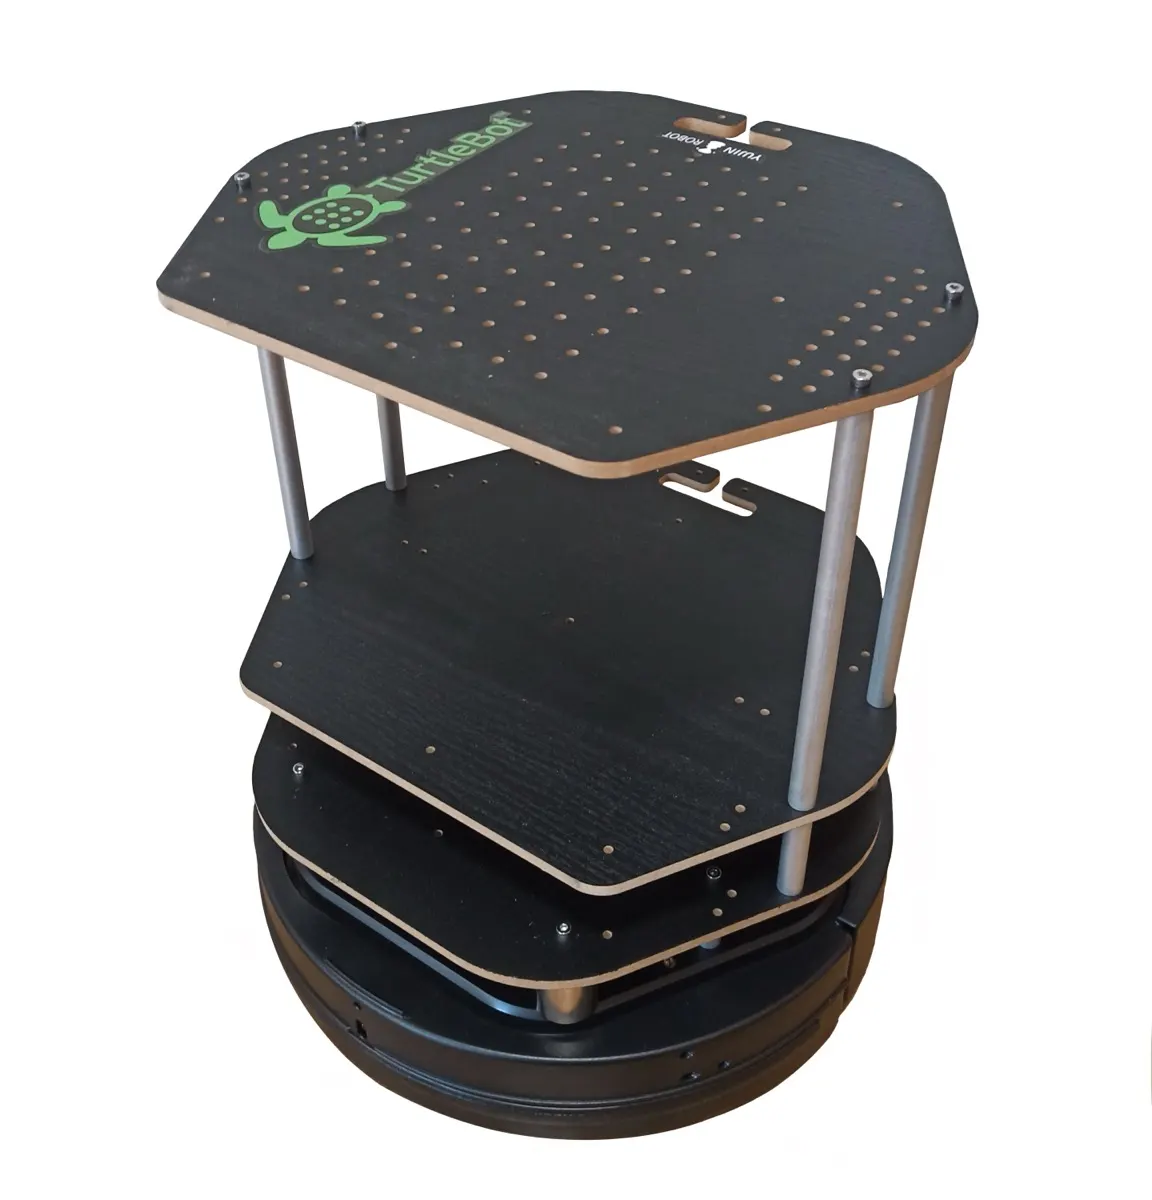
The robot that taught a generation ROS: a Kobuki vacuum-style base, a Kinect-class depth camera and a laptop on stacked plates. It followed the iRobot Create-based TurtleBot 1 (2010–2011) and was succeeded by TurtleBot 3 and 4. Kobuki bases are still found in labs and on the used market, but ROS 1 is end-of-life.
Specifications
| Category | Wheeled rovers · Ready-made dev rovers |
|---|---|
| Released | 2012 |
| Availability | Discontinued · used/leftover only |
| Programmability | Open source (hardware + software) |
| Best for | Ages 16+ (estimated) |
| Vision sensors | Depth camera, Camera |
| Actuators | DC / gear motors |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Remote control | Via SSH / web / bridge |
| Size | 35.4 × 35.4 × 42 cm, 6.3 kg; 5 kg payload, 0.65 m/s max |
| Drive | 2-wheel differential (Kobuki base) |
| Compute | Laptop or netbook carried on the robot |
| Vision | Microsoft Kinect or ASUS Xtion (later Orbbec Astra) RGB-D camera |
| Lidar | None standard |
| Sensors | Bumpers, cliff and wheel-drop sensors, gyro, encoders |
| Runtime | 3–7 h (Kobuki, battery dependent) |
| Speed | 0.7 m/s max (Kobuki) |
| SDK | ROS 1 (Kobuki and TurtleBot stacks) |
Ratings & reviews
Ratings and reviews load on the live site.
 MARS (Builders Edition)
 UGV Rover (PT / ROS 2 kit)
 UGV Beast (tracked)
 TurtleBot 4 / 4 Lite
 MentorPi M1
 ROSMASTER X3