Overview
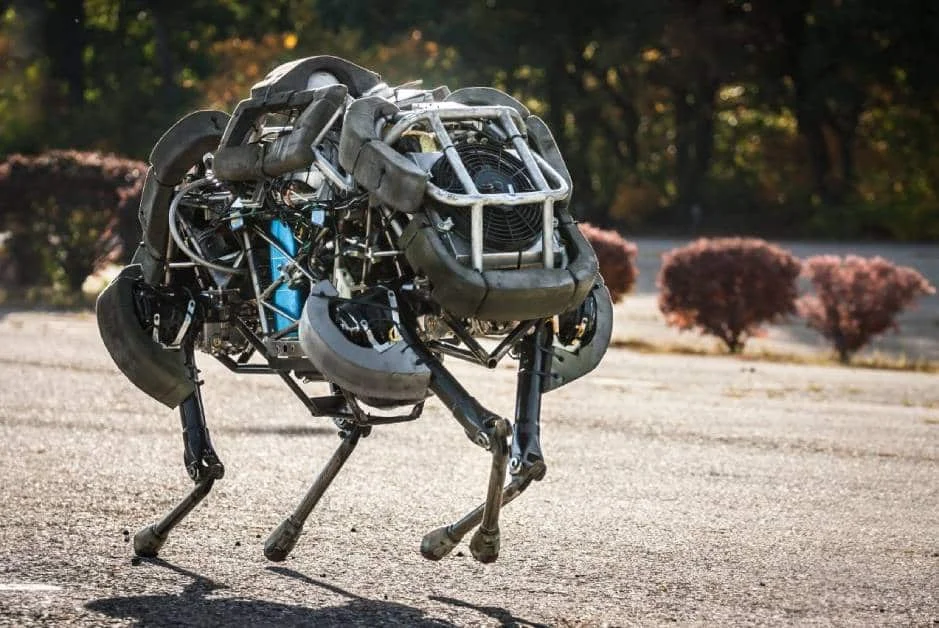
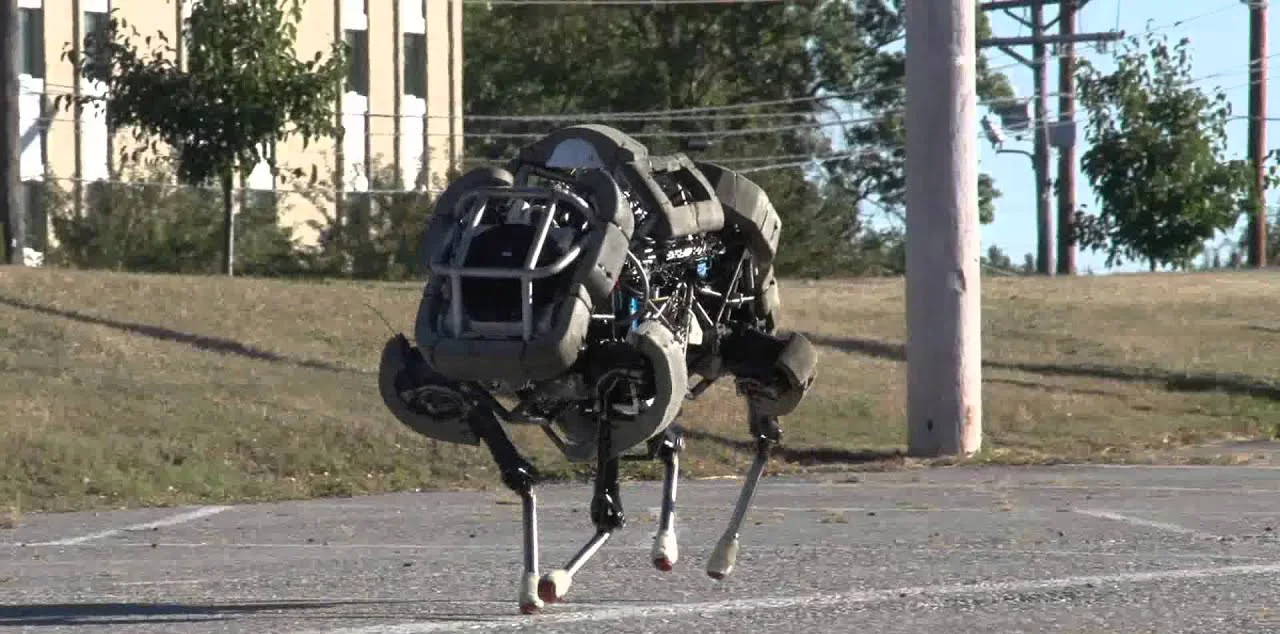
The untethered, outdoor successor to Boston Dynamics' treadmill-bound Cheetah, shown in an October 2013 video funded by DARPA's M3 program. Instead of an off-board pump, it carried a two-stroke go-kart engine coupled directly to a hydraulic pump. A small fuel tank kept weight down and gave about five minutes of running. In a parking lot it bounded and galloped at about 16 mph. DARPA's stated goal was a quadruped that could run up to 50 mph on all kinds of outdoor terrain.
WildCat was slower than Cheetah's tethered 28.3 mph but ran free, which made it the fastest untethered quadruped of its time (unconfirmed). It shared the loud gas-engine hydraulics of BigDog, which traded speed for long walks carrying loads over rough ground. Boston Dynamics' own legacy page lists WildCat at 19 mph and dates it to 2011, which differs from the 2013 coverage (unconfirmed). It suits readers of legged-robot history rather than buyers.
- Type
- Quadruped robot · Research & legacy platforms
- Maker
- Boston Dynamics (US)
- Released
- 2013
- Price
- Not for sale
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- No programmability
Price and shipping
DARPA-funded research prototype built under the Maximum Mobility and Manipulation (M3) program. It was never sold.
Shipping: N/A. Never sold. It stayed a DARPA research prototype.
Specifications
| Category | Quadrupeds · Research & legacy platforms |
|---|---|
| Released | 2013 |
| Country | US |
| Availability | Not for sale (research) |
| Fastest Robot Dogs | Ranked #3 by top speed |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no public SDK. It was a remote-controlled research prototype. |
| MuJoCo simulation | None found · Nothing found. No public model or robot description exists. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · Nothing found. No public model or robot description exists. |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Hydraulic / pneumatic |
| Audio | No audio |
| Compute type | Proprietary / undisclosed |
| Compute | Not published |
| Weight | Not published. A small fuel tank kept weight down and allowed about 5 minutes of running |
| Speed | About 7.2 m/s (16 mph) outdoors, untethered, bounding and galloping on flat ground (2013). Boston Dynamics' legacy page later lists 19 mph (unconfirmed) |
| DOF | Not published. Hydraulically actuated legs |
| Sensors | Not published |
| SDK | None |
Timeline
- AnnouncedBoston Dynamics released the Introducing WildCat video, showing it galloping untethered at about 16 mph. IEEE Spectrum (October 2013) ↗
Common questions
How much does WildCat cost?
Not for sale. DARPA-funded research prototype built under the Maximum Mobility and Manipulation (M3) program. It was never sold.
Can WildCat be bought today?
No. It was never sold to the public.
Who makes WildCat?
WildCat is made by Boston Dynamics (US). It came out in 2013.
Can WildCat be programmed?
No programmability.
Does WildCat have AI chat or LLM support?
None. No built-in LLM and no public SDK. It was a remote-controlled research prototype.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Fastest Robot Dogs · the top 20 ranked by speed
- Robot Dog Actuators · how to choose the leg motors
- 8 vs 12 DOF Robot Dogs · two or three motors per leg
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
Similar robots
 Stanford DoggoStanford Student Robotics (Extreme Mobility team)Not for sale
 Laikago / Laikago ProUnitree Robotics (China)Was quote-only
 Swiss-Mile / RIVR wheeled-legged robotSwiss-Mile, now RIVR (Switzerland)Not for sale
 BigDogBoston Dynamics (US) for DARPANot for sale
 LS3 (Legged Squad Support System)Boston Dynamics (US) for DARPA/USMCNot for sale
 LittleDogBoston Dynamics (US) for DARPANot for sale
Sources
Introducing WildCat (Boston Dynamics video) ↗ · IEEE Spectrum (October 2013) ↗ · Tech Briefs (DARPA video) ↗