Overview
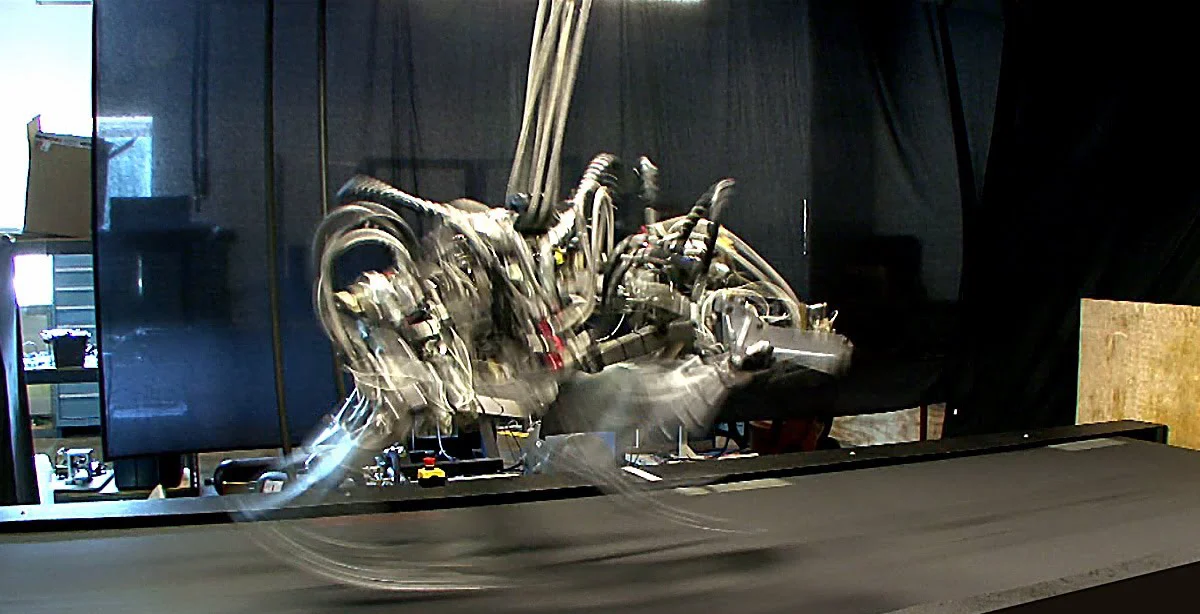
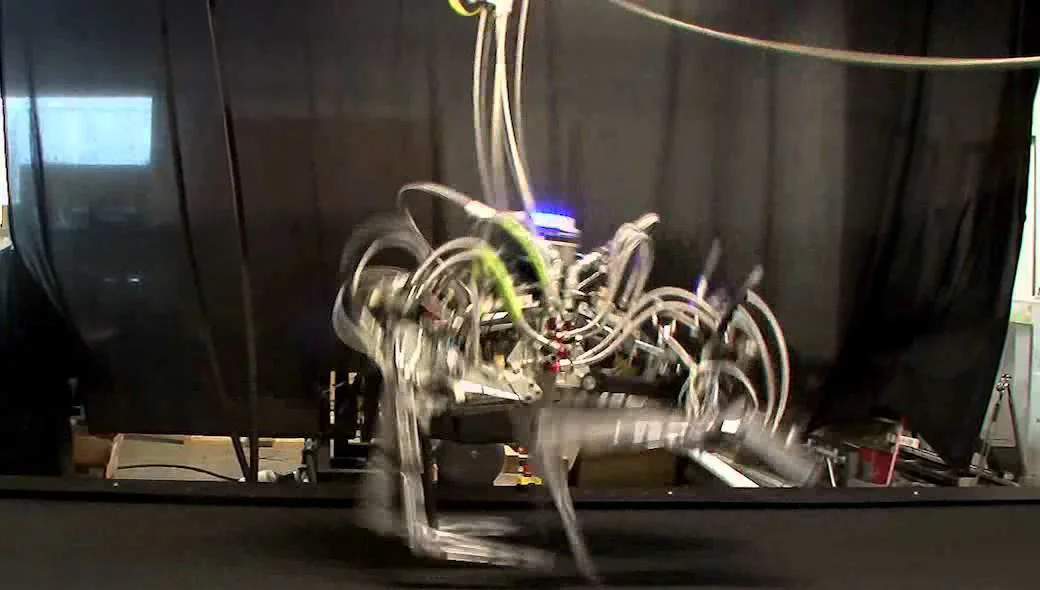
A hydraulic four-legged sprinter built by Boston Dynamics for DARPA's Maximum Mobility and Manipulation (M3) program. In March 2012 it galloped at 18 mph on a lab treadmill, beating the 13.1 mph legged-robot record set by an MIT robot in 1989. By September 2012 better control software and more installed power raised its fastest 20 m split to 28.3 mph. That edged past Usain Bolt's best 20 m split of 27.78 mph. It held the legged-robot speed record for over a decade. In 2026 the team behind Black Panther 2.0 reported 13.2 m/s on a treadmill. Like a real cheetah, it flexed its back with each stride to lengthen its gait.
The record came with large caveats. Cheetah ran on a treadmill, drew hydraulic power from an off-board pump through a tether, and was held centered by a boom arm, so it never ran free. Its untethered outdoor successor, WildCat, ran at about 16 mph in 2013. It is unrelated to the MIT Mini Cheetah and MIT Cheetah 3, which are electric lab robots from MIT's Biomimetic Robotics Lab that share only the name. It suits readers of legged-robot history rather than buyers.
- Type
- Quadruped robot · Research & legacy platforms
- Maker
- Boston Dynamics (US)
- Released
- 2012
- Price
- Not for sale
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- No programmability
Price and shipping
DARPA-funded research prototype built under the Maximum Mobility and Manipulation (M3) program. It was never sold.
Shipping: N/A. Never sold. It was a tethered treadmill prototype, followed by the untethered WildCat in 2013.
Specifications
| Category | Quadrupeds · Research & legacy platforms |
|---|---|
| Released | 2012 |
| Country | US |
| Availability | Not for sale (research) |
| Fastest Robot Dogs | Ranked #2 by top speed |
| Programmability | No programmability |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | None · No built-in LLM and no public SDK. It was a tethered lab prototype run by Boston Dynamics engineers. |
| MuJoCo simulation | None found · Nothing found. No public model or robot description exists. |
| NVIDIA Isaac simulation | None found · Nothing found. |
| Gazebo simulation | None found · Nothing found. No public model or robot description exists. |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Hydraulic / pneumatic |
| Audio | No audio |
| Compute type | Proprietary / undisclosed |
| Compute | Not published |
| Weight | Not published |
| Speed | 12.6 m/s (28.3 mph) on a treadmill, tethered (fastest 20 m split, September 2012). Earlier 8 m/s (18 mph) in March 2012 |
| DOF | Not published. Hydraulically actuated legs plus a flexing back that bends and unbends with each stride |
| Sensors | Not published |
| SDK | None |
Timeline
- UpdateRan at 18 mph on a lab treadmill, a new speed record for legged robots, beating the 13.1 mph set by an MIT robot in 1989. HuffPost (Reuters) ↗
- UpdateFastest 20 m split clocked at 28.3 mph on a treadmill with off-board hydraulic power, faster than Usain Bolt's best 20 m split. IEEE Spectrum (September 2012) ↗
- UpdateIts untethered outdoor successor, WildCat, was shown galloping at about 16 mph. IEEE Spectrum (October 2013) ↗
Common questions
How much does Cheetah cost?
Not for sale. DARPA-funded research prototype built under the Maximum Mobility and Manipulation (M3) program. It was never sold.
Can Cheetah be bought today?
No. It was never sold to the public.
Who makes Cheetah?
Cheetah is made by Boston Dynamics (US). It came out in 2012.
Can Cheetah be programmed?
No programmability.
Does Cheetah have AI chat or LLM support?
None. No built-in LLM and no public SDK. It was a tethered lab prototype run by Boston Dynamics engineers.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Fastest Robot Dogs · the top 20 ranked by speed
- Robot Dog Actuators · how to choose the leg motors
- 8 vs 12 DOF Robot Dogs · two or three motors per leg
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
Similar robots
 Stanford DoggoStanford Student Robotics (Extreme Mobility team)Not for sale
 Laikago / Laikago ProUnitree Robotics (China)Was quote-only
 Swiss-Mile / RIVR wheeled-legged robotSwiss-Mile, now RIVR (Switzerland)Not for sale
 BigDogBoston Dynamics (US) for DARPANot for sale
 LS3 (Legged Squad Support System)Boston Dynamics (US) for DARPA/USMCNot for sale
 LittleDogBoston Dynamics (US) for DARPANot for sale
Sources
DARPA video (March 2012) ↗ · IEEE Spectrum (September 2012) ↗ · IEEE Spectrum (March 2012) ↗