Overview
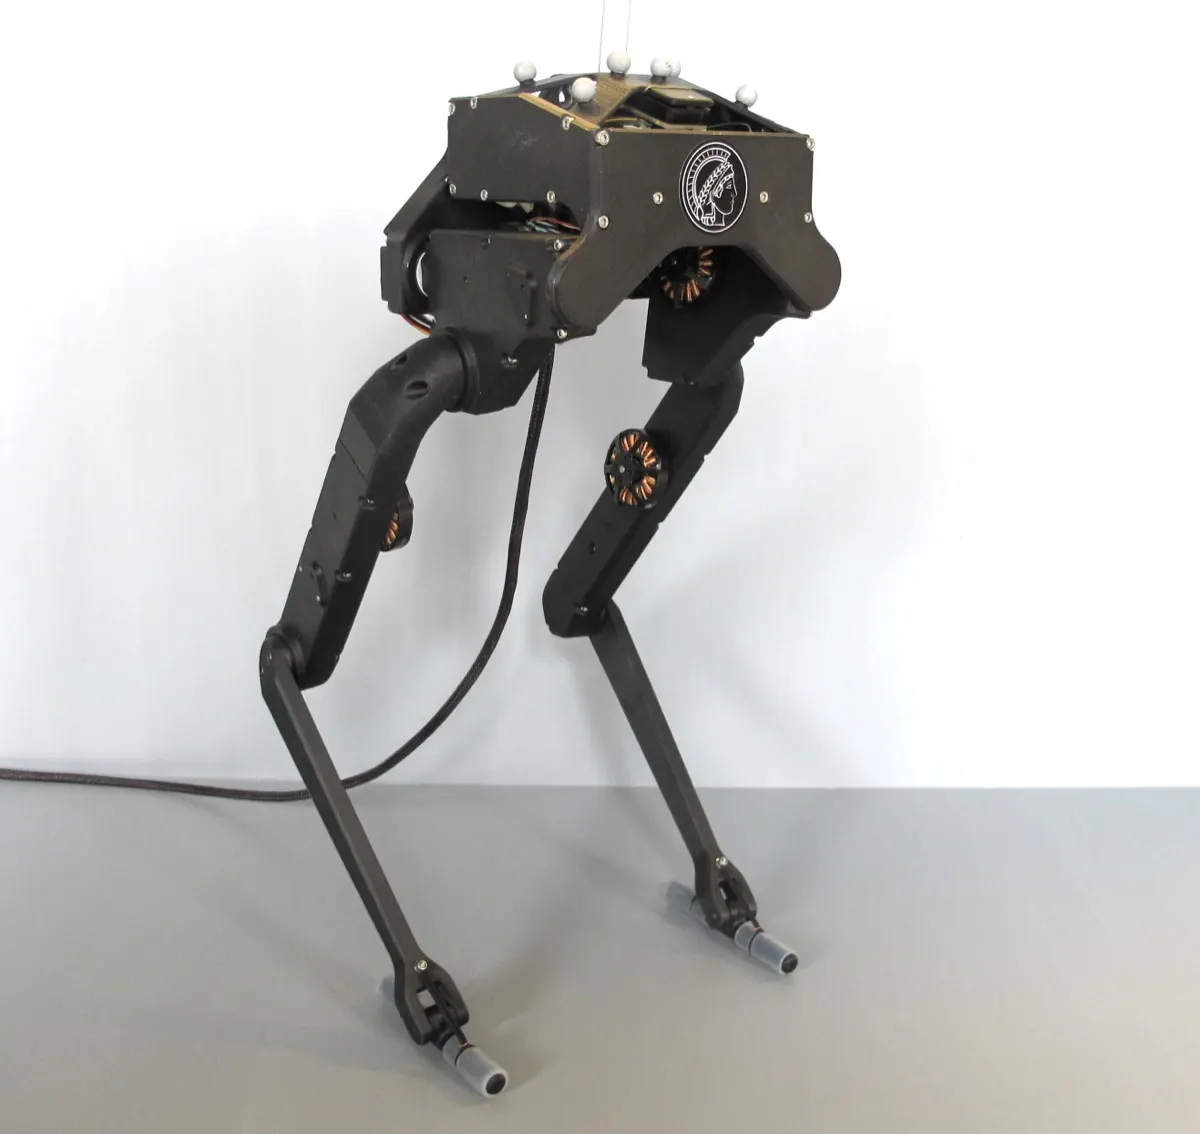
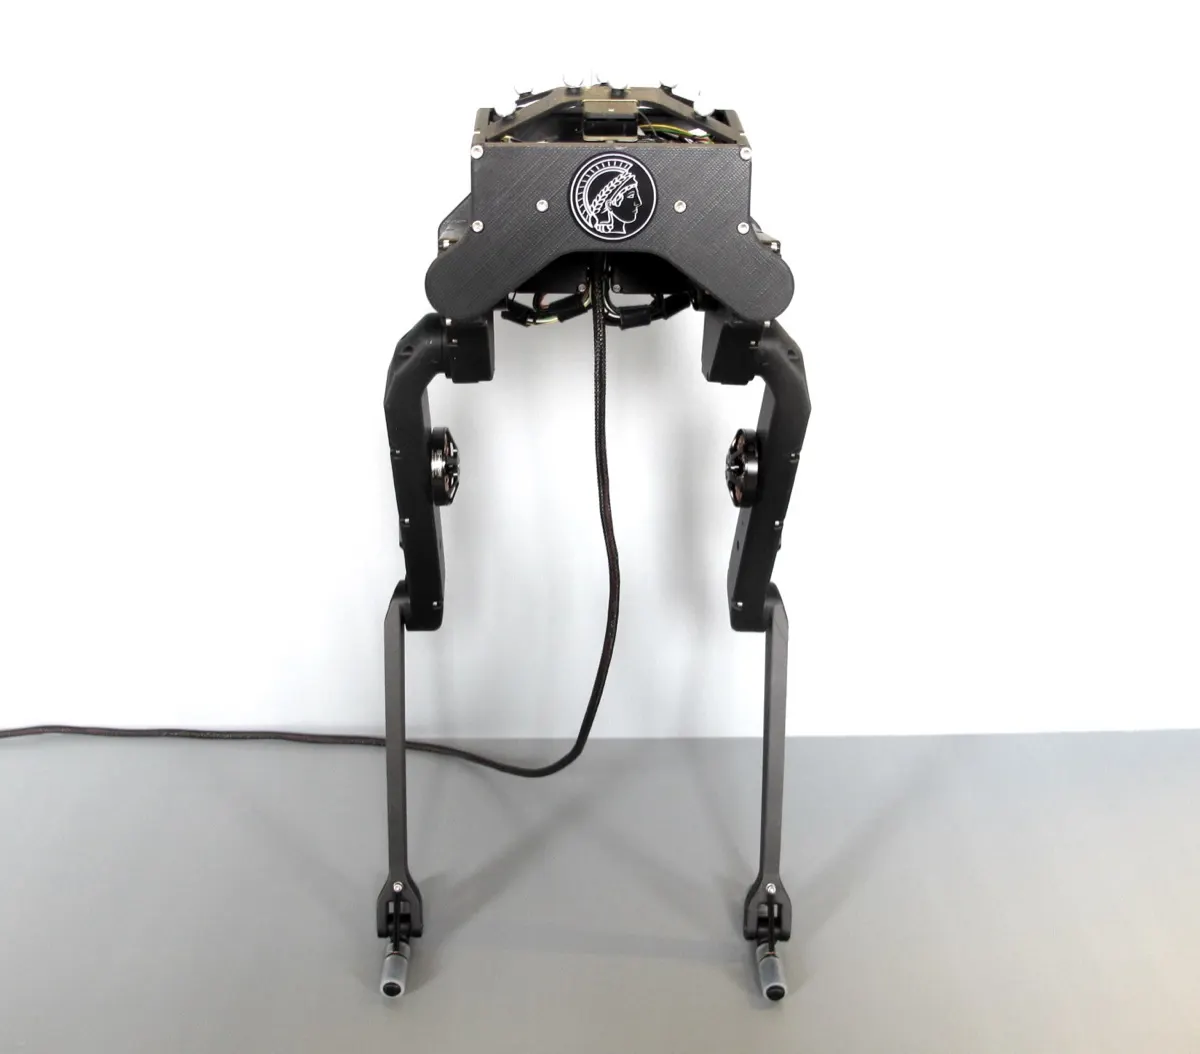
A tiny tethered biped from the Open Dynamic Robot Initiative, the group behind the Solo quadrupeds, built from the same open brushless actuator modules. With no ankle actuation it must constantly step to stay up, which makes it a clean testbed for dynamic balance and learned controllers. Everything, from CAD to electronics, is published.
- Type
- Biped robot · Research & legacy bipeds
- Maker
- Open Dynamic Robot Initiative (MPI-IS / NYU)
- Released
- 2021
- Price
- DIY (open hardware)
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- Open source (hardware + software)
Price and shipping
Built from the ODRI open actuator modules. No kit sold
Shipping: Build. Not for sale. It can be built from the ODRI files with machined and 3D-printed parts.
Specifications
| Category | Bipeds · Research & legacy bipeds |
|---|---|
| Released | 2021 |
| Country | Germany, USA |
| Availability | Not for sale (research) |
| DIY build plans | ODRI Bolt biped · parts $4,700 (2022) (estimate) · difficulty 5/5 |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No built-in LLM. Its SDK lets software on a computer control it. |
| MuJoCo simulation | Community model · Community MuJoCo simulation shared on the ODRI forum, built from the official URDF. ODRI forum ↗ |
| NVIDIA Isaac simulation | Community model · Third-party Isaac Gym RL environment for Bolt. rafacelente/bolt ↗ |
| Gazebo simulation | Maker URDF only · ODRI publishes a URDF (robot_properties_bolt), no Gazebo package found. robot_properties_bolt ↗ |
| Best for | Professionals & labs |
| Vision sensors | No vision sensors |
| Actuators | Brushless / direct-drive motors |
| Audio | No audio |
| Compute type | Laptop / PC as the brain |
| Balance type | RL walking |
| Height | Not published |
| Weight | 1.34 kg |
| Compute | Off-board PC via ODRI master board |
| Speed | Not published |
| DOF | 6 (3 per leg, passive ankles) |
| Sensors | IMU, joint encoders |
| Balance | Point-foot dynamic balancing with torque-controlled brushless actuators. Used for MPC and RL research. |
| SDK | Open-source ODRI software (C++/Python), BSD-licensed hardware |
Common questions
How much does Bolt cost?
DIY (open hardware). Built from the ODRI open actuator modules. No kit sold.
Can Bolt be bought today?
No. It was never sold to the public.
Who makes Bolt?
Bolt is made by Open Dynamic Robot Initiative (MPI-IS / NYU). It came out in 2021.
Can Bolt be programmed?
Open source (hardware + software). Open-source ODRI software (C++/Python), BSD-licensed hardware.
Does Bolt have AI chat or LLM support?
Possible via SDK. No built-in LLM. Its SDK lets software on a computer control it.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
- MuJoCo Guide · the simulator used to train walking robots
- ROS 2 Guide · the software framework many robots use
- Robot Vision and Depth Sensors · cameras, lidar and other distance sensors
Similar robots
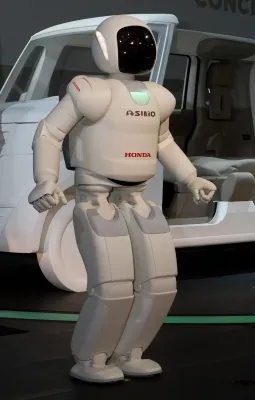 ASIMO (2011 "All-new ASIMO")Honda (Japan)Not for sale
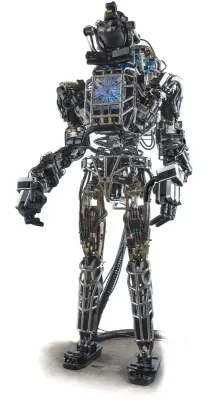 Atlas (hydraulic)Boston Dynamics (USA)Not for sale
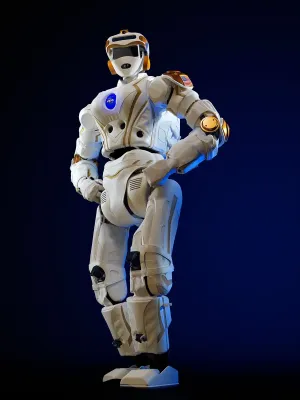 Valkyrie (R5)NASA Johnson Space Center (USA)Not for sale
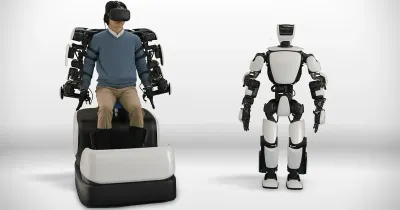 T-HR3Toyota (Japan)Not for sale
 CyberOneXiaomi (China)Not for sale
 Tiangong (Tien Kung)Beijing Humanoid Robot Innovation Center (China)Quote (China)