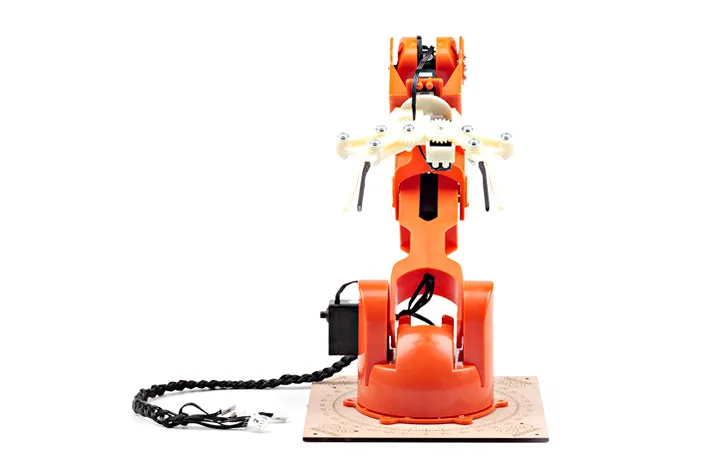
$275$275.00 on the Arduino US store (in stock, October 2026) without an Arduino board. The Braccio Bundle with an UNO was $305.00 and is sold out. Year 2016 (unconfirmed) is taken from the earliest dated coverage found (Open Electronics, March 2016), and Arduino's library repository dates from November 2016.
AvailableVia SSH / web / bridgeServo hobby armArduinoOpen hardwareEducation
Possibly ≤ 1 weekIn stock on the Arduino US store, which offers free shipping on orders over $50 within the contiguous US. Delivery times are not stated on the product page, and an Arduino board must be bought separately. Arduino store ↗
Remote control: Sketches are uploaded from a Mac or PC with the Arduino IDE, and laptop control needs a custom serial sketch or a community ROS bridge.
Overview
The Tinkerkit Braccio is Arduino's original desktop robot arm, an orange plastic kit with six hobby servos, a shield and a 5 V 4 A power supply. It suits makers and classrooms who want a simple Arduino-programmed arm, and its open CAD files and long-lived library have spawned many community ROS and kinematics projects. The catches are open-loop servos with no feedback, unpublished accuracy, a resettable fuse that cuts power on collisions, and no Arduino board in the $275 box. It is still in stock on Arduino's US store, while its successor the Braccio++ has been discontinued, and bus-servo arms with position feedback such as the Hiwonder xArm 1S start lower, at $199.99.
Specifications
| Category | Robot arms · Desktop & hobby arms |
|---|---|
| Released | 2016 |
| Country | Italy |
| Availability | Available |
| Programmability | Open source (hardware + software) |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No LLM features. It is driven by plain Arduino sketches with the open `Braccio` library, so an LLM can write the code or send joint angles over a serial bridge. |
| MuJoCo simulation | Community model · Only third-party ROS URDFs exist, which would need converting. grassjelly/ros_braccio_urdf ↗ |
| NVIDIA Isaac simulation | Community model · A small third-party project controls a Braccio model in Isaac Sim. ZachAtkins0n/Isaac_Braccio ↗ |
| Gazebo simulation | Community model · Student and hobby projects provide Gazebo and RViz configurations, last updated around 2020. chethan-bhat/project-braccio ↗ |
| Best for | Ages 14+ (estimated) |
| Vision sensors | No vision sensors |
| Actuators | Hobby servos |
| Audio | No audio |
| Compute type | Arduino / ESP32 / microcontroller |
| Remote control | Via SSH / web / bridge |
| DOF | 6 servos (5 DOF + gripper) for base, shoulder, elbow, wrist pitch, wrist roll and gripper |
| Reach | 80 cm maximum operating range (maker), likely the width of the whole working area, so about 40 cm from the base (unconfirmed), and 52 cm maximum height |
| Payload | 150 g at 32 cm, 400 g in its most compact pose (maker) |
| Repeatability | Not published |
| Weight | 792 g assembled |
| Controller | None included, an UNO, Mega or similar Arduino board plugs into the Braccio shield |
| Sensors | None (open-loop hobby servos, 2× SpringRC SR311 and 4× SR431, with no position feedback) |
| SDK | Arduino IDE with the official `Braccio` library (`Braccio.ServoMovement` sets all six joints); community ROS packages and inverse-kinematics libraries |
Ratings & reviews
Ratings and reviews load on the live site.
Similar robots
 SO-101 (SO-ARM101)TheRobotStudio × Hugging Face (open source)~$230 DIY parts (pair), kits $199 – $460
 Hiwonder NexArm (LeRobot 6-axis)Hiwonder (Shenzhen, China)$279.99 – $599.99
 SO-100 (SO-ARM100)TheRobotStudio × Hugging Face (open source)~$232 DIY parts (pair)
 Koch v1.1 Low-Cost Robot ArmAlexander Koch (original), v1.1 by Jess Moss (open source)~$477 DIY parts (pair)
 Annin Robotics AR4Annin Robotics (USA)$1,189 kit + motors/drivers
 PAROL6Source Robotics (Croatia)~$2,670 kit (€2,378.81) / ~$4,010 assembled (€3,570)
Image credits
- Image 1: source (official product image)