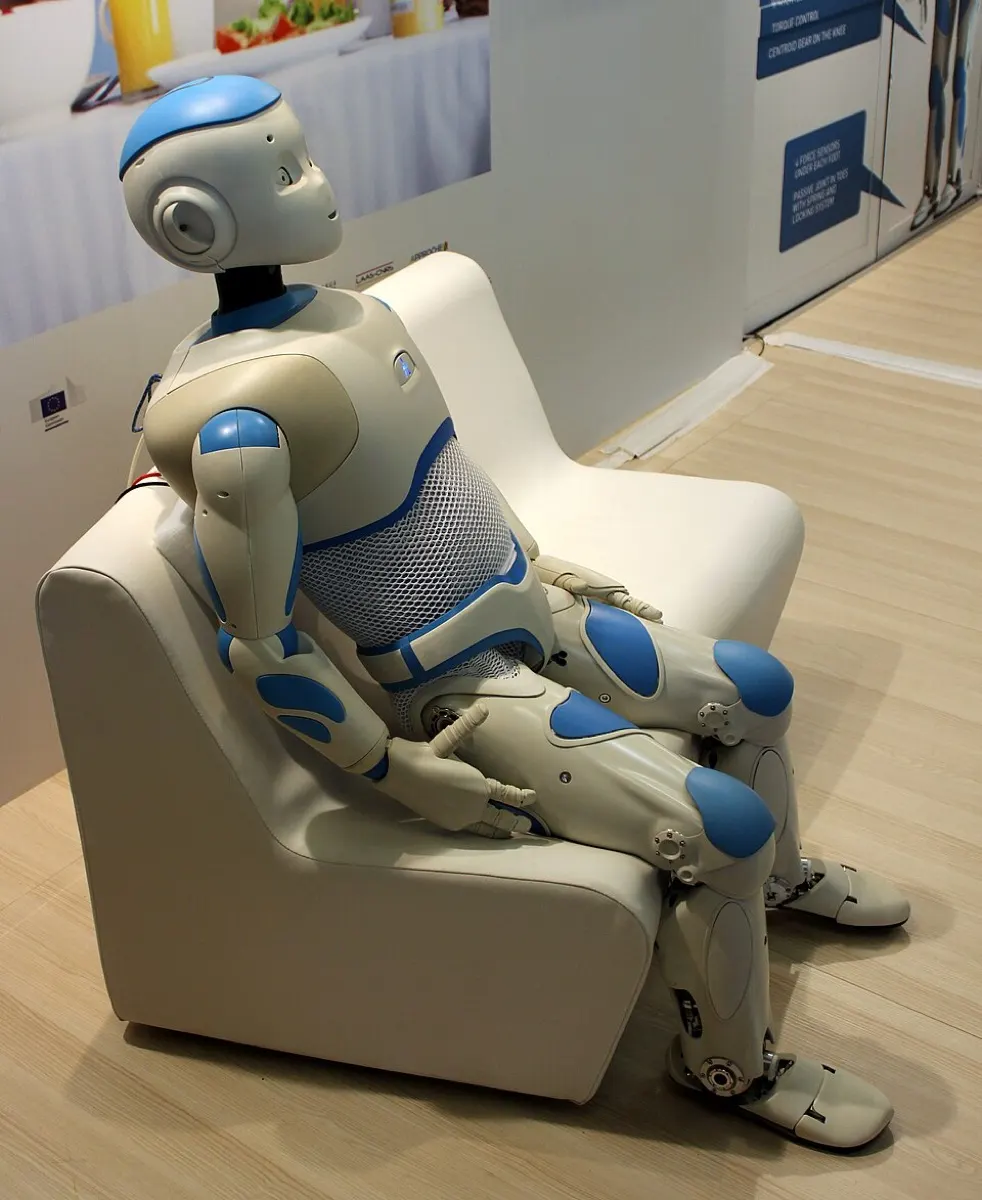
Overview
A tall research humanoid meant to help elderly people at home, started by Aldebaran in 2009 with French public funding. The first prototype was shown to project partners in February 2012. A handful of units went to partner labs. It never became a product, and development faded after SoftBank's acquisition shifted focus to Pepper.
- Type
- Biped robot · Research & legacy bipeds
- Maker
- Aldebaran / SoftBank Robotics (France)
- Released
- 2012
- Price
- Not for sale
- Status
- Not for sale (research)
- Best for
- Professionals & labs
- Programming
- Full SDK
Price and shipping
Research prototypes built for a French consortium
Shipping: Not for sale. Never sold. Only a few research units exist.
Specifications
| Category | Bipeds · Research & legacy bipeds |
|---|---|
| Released | 2012 |
| Country | France |
| Availability | Not for sale (research) |
| Sales | 7 built, 4 of them for European research labs, never sold maxon group ↗ |
| Programmability | Full SDK |
| Built-in autonomy | None / scripted · Moves only when controlled, or plays preset motions |
| LLM support | Possible via SDK · No built-in LLM. Its SDK lets software on a computer control it. |
| MuJoCo simulation | Maker URDF only · Aldebaran's romeo_robot ROS stack has the Romeo description, with nothing for MuJoCo. romeo_robot ↗ |
| NVIDIA Isaac simulation | Maker URDF only · Aldebaran's romeo_robot ROS stack has the Romeo description, with nothing for Isaac. romeo_robot ↗ |
| Gazebo simulation | Official model · Aldebaran's romeo_virtual provides a Gazebo plugin and controllers for Romeo. romeo_virtual ↗ |
| Best for | Professionals & labs |
| Vision sensors | Camera |
| Actuators | Unknown |
| Audio | Microphone |
| Compute type | Proprietary / undisclosed |
| Balance type | ZMP / IK gait |
| Height | ~1.4 m |
| Weight | ~40 kg (est.) |
| Compute | Not published |
| Speed | Not published |
| DOF | 37 (est.) |
| Sensors | Cameras, microphones, IMU |
| Balance | Model-based walking derived from NAO's approach. Research-grade only. |
| SDK | NAOqi |
Common questions
How much does Romeo cost?
Not for sale. Research prototypes built for a French consortium.
Can Romeo be bought today?
No. It was never sold to the public.
Who makes Romeo?
Romeo is made by Aldebaran / SoftBank Robotics (France). It came out in 2012.
Can Romeo be programmed?
Full SDK. NAOqi.
Does Romeo have AI chat or LLM support?
Possible via SDK. No built-in LLM. Its SDK lets software on a computer control it.
Ratings & reviews
Ratings and reviews load on the live site.
Related guides
- Robot Gaits and Gait Training · how legged robots walk, trot and gallop
- MuJoCo Guide · the simulator used to train walking robots
- ROS 2 Guide · the software framework many robots use
- Robot Vision and Depth Sensors · cameras, lidar and other distance sensors
Similar robots
 ASIMO (2011 "All-new ASIMO")Honda (Japan)Not for sale
 Atlas (hydraulic)Boston Dynamics (USA)Not for sale
 Valkyrie (R5)NASA Johnson Space Center (USA)Not for sale
 T-HR3Toyota (Japan)Not for sale
 CyberOneXiaomi (China)Not for sale
 Tiangong (Tien Kung)Beijing Humanoid Robot Innovation Center (China)Quote (China)
Image credits
- Image 1: source (CC BY-SA 3.0, Xavier Caré)